
UBTECH Walker X Commercial Humanoid Robot
In stock
- BRAND:
- UBTECH
- MODEL:
- WALKER X
- ORIGIN:
- China
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- UBTECH-X
UBTECH Walker X Commercial Humanoid Robot
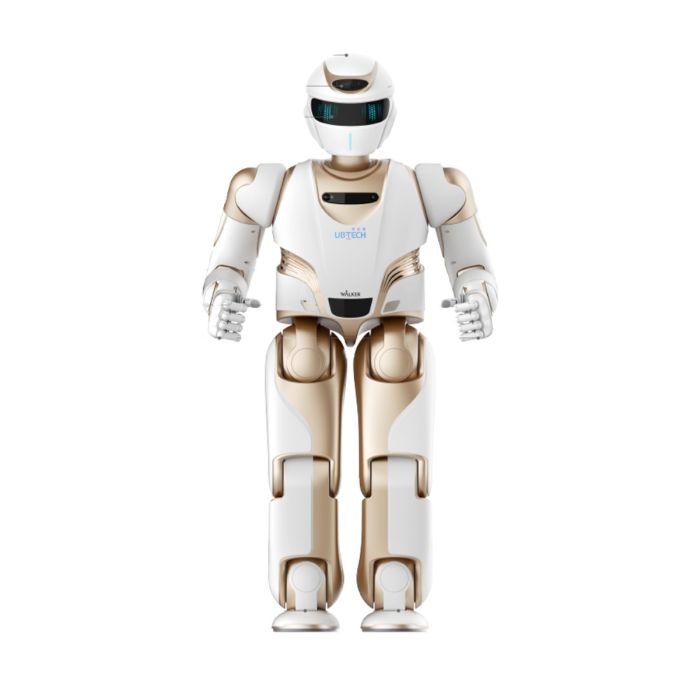
Two hours to charge, two hours to work: that is the rhythm of the UBTECH Walker X Commercial Humanoid Robot, and it tells you how to think about this machine. It is not a statue that stands in a lobby all day. It is a working colleague with a shift, a charging break and a long list of things it can do with its hands, its legs and its curved face display.
The product is available through this page, by quotation.
Background
UBTECH and the Walker line
UBTECH is a robotics company known for bipedal humanoids, and the Walker family is its life-sized line. Walker X sits in the commercial group of that family, which means it is meant for places where people meet a robot face to face rather than for a fenced production cell. Those places include offices, showrooms, visitor centers and demonstration floors.
The fact sheet describes Walker X as a highly advanced AI robot that incorporates six cutting-edge AI technologies. The sources do not name those six technologies, so this page does not guess at them. What the sources do give is the hardware, and the hardware tells a clear story.
Positioning and key technology
Walker X stands 130cm tall and weighs 63kg. It carries 41 high-performance servo joints, and the torque of those joints runs from 4.5Nm to 200Nm. That range matters in practice. The small, light joints handle fine movements, and the strong joints handle standing, stepping and carrying.
Behind the joints sits a computing package built on two Intel i7 8665U processors at 1.9Ghz, together with an NVIDIA GT1030 graphics card with 384 cores. The software framework is ROSA, the operating system combination is Ubuntu with Linux RT Preempt and Android, and the simulation platform is Webots. For a team that wants to develop and test behaviors before they reach the real robot, that is a practical combination.
The face is a 160° face-surrounding 4.6K HD dual flexible curved screen. A robot that meets visitors needs an expressive front, and this display gives it one.
Technical Specifications
| Specification | Value |
|---|---|
| Height | 130cm |
| Weight | 63kg |
| Servo joints | 41 high-performance servo joints |
| Degrees of freedom | 41 (legs: 6x2, arms: 7x2, hands: 6x2, neck: 3) |
| Servo joint torque | 4.5Nm-200Nm |
| Maximum walking speed | 3km/h |
| Maximum up and down step height | 15cm |
| Maximum up and down slope angle | 20° |
| Load, single arm (extended) | 1.5kg |
| Carrying capacity | Carry 10kg, or walk with 3kg on both hands |
| Arm span | Single arm 600mm |
| Battery | Lithium battery 54.6V/10Ah/3.6 kg |
| Charging time | 2h |
| Usage time (combined working conditions) | 2h |
| Processor | Intel i7 8665U, frequency 1.9Ghz x2 |
| Graphics | NVIDIA GT1030 graphics card, 384 cores |
| Software | Framework: ROSA; OS: Ubuntu + Linux RT Preempt + Android; simulation: Webots |
| Display | 160° face-surrounding 4.6K HD dual flexible curved screen |
Specifications as published by the manufacturer; confirmed against the datasheet at quotation.
The manufacturer has not published the IP rating, the package contents, the ambient operating temperature, the sensor resolution or the overall dimensions beyond the height; they are confirmed at quotation.
What does the joint layout of Walker X make possible?
Of the 41 degrees of freedom, twelve are in the legs, fourteen in the arms, twelve in the hands and three in the neck. The hands carry as many degrees of freedom as both legs together. That is a deliberate choice, and it points to a robot designed to handle objects rather than only to walk and wave.
The sources say Walker X can use household appliances such as refrigerators, coffee machines and vacuum cleaners. A hand with six degrees of freedom, on an arm with seven, can reach out, turn and press in ways a simple gripper cannot. The arm span of 600mm per arm sets the working reach, and each arm can hold 1.5kg in the extended state.
The walking figures are modest and clearly stated: a maximum of 3km/h, steps up and down of up to 15cm, and slopes up and down of up to 20°. This is a pace for indoor service work among people, not for racing. The robot can carry 10kg, or walk with 3kg held in both hands.
How long does Walker X work on one charge?
The 54.6V/10Ah lithium battery weighs 3.6 kg and charges in 2h. Usage time under combined working conditions is also 2h. A buyer should plan around that figure from the start. Deployments suit scheduled sessions, such as a reception period, a demonstration slot or a guided tour, with charging built into the daily plan.
The sources give no battery life under other conditions, so any plan that depends on longer runs should be raised when you request a quotation.
Who is Walker X for?
Walker X suits organizations that want a life-sized humanoid in front of people: hotels and resorts planning a visitor experience, corporate lobbies, exhibition and showroom operators, and technology centers. It also suits universities and research groups, because the ROSA framework and the Webots simulation platform give developers a place to start.
If your main need is a reception role, compare it with the UBTECH Walker C Commercial Reception Humanoid Robot. If your work is on a production line rather than in front of visitors, look at the UBTECH Walker S1 Industrial Humanoid Robot. You can also browse the wider Bipedal Humanoids category or the UBTECH Walker range to compare options.
What is Walker X used for?
- Welcoming visitors. The curved face display and the human-sized body give a lobby or showroom a memorable first contact.
- Demonstrations and events. A walking humanoid draws a crowd at trade shows, launches and open days.
- Handling light objects. Each arm can hold 1.5kg extended, and the robot can carry 10kg in total.
- Operating household appliances. The sources state it can use refrigerators, coffee machines and vacuum cleaners.
- Research and development. ROSA, Ubuntu with Linux RT Preempt and Webots support software work and simulation.
- Training and education. A 41-joint humanoid gives students and engineers a real platform to study.
Pricing and Availability
Pricing for Walker X is given by quotation, tailored to your project. Delivery, customs and support are arranged together with the quotation, so you receive one clear plan. Send your request and the details of your site, and the Walker X UBTECH humanoid is available on this page.
Frequently Asked Questions
How tall is the UBTECH Walker X and how much does it weigh?
It stands 130cm tall and weighs 63kg.
How many joints does Walker X have?
It has 41 high-performance servo joints. They are divided into 6x2 for the legs, 7x2 for the arms, 6x2 for the hands and 3 for the neck.
How fast and how steady does it walk?
The maximum walking speed is 3km/h. It can manage steps up and down of up to 15cm and slopes up and down of up to 20°.
What can it carry?
It can carry 10kg, or walk with 3kg held in both hands. A single extended arm holds 1.5kg.
How long does the battery last?
Usage time under combined working conditions is 2h, and charging takes 2h. The battery is a 54.6V/10Ah lithium unit weighing 3.6 kg.
What software does it run?
The software framework is ROSA, and the operating system is Ubuntu with Linux RT Preempt and Android. The simulation platform is Webots.
Where can I buy the UBTECH Walker X and what does it cost?
You can request it through this page, by quotation. The cost is confirmed in the quotation, together with delivery, customs and support.
Summary
The two-hour rhythm of charging and working describes Walker X well: it is a humanoid built for sessions of real, visible work. With 41 servo joints, hands that carry as many degrees of freedom as both legs, a 130cm body and a 160° curved display, it is made to meet people and handle objects. If that matches your project, this page is the starting point.


