
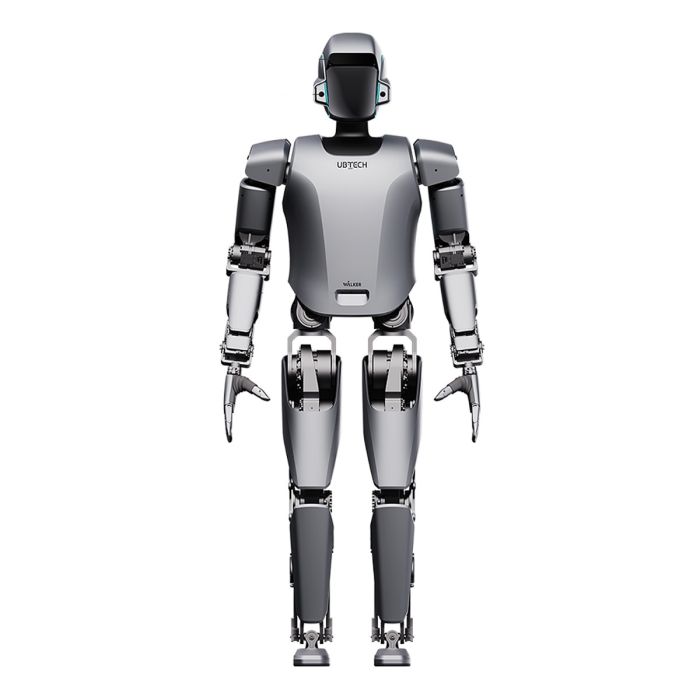
UBTECH Walker S1 Industrial Humanoid Robot
In stock
- BRAND:
- UBTECH
- MODEL:
- WALKER S1
- ORIGIN:
- China
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- UBTECH-Walker-S1
UBTECH Walker S1 Industrial Humanoid Robot
A humanoid that only has to look convincing can be built to impress a crowd. A humanoid that has to work a shift next to logistics vehicles and the plant's own management software has to be built to be useful. The UBTECH Walker S1 Industrial Humanoid Robot belongs to the second group. It is UBTECH's 2024 industrial humanoid in the Walker S series, purpose-built for multi-task work on automotive assembly lines and similar factory settings.
The product is available through this page, by quotation.
Background
UBTECH and the Walker S lineage
UBTECH builds humanoid robots, and the Walker family is its line of walking, two-legged machines. Within it, the Walker S series is the branch aimed at industry. Walker S1 is the 2024 member of that series, built for multi-task work in automotive assembly and comparable factory settings rather than for reception desks or showrooms.
The family has siblings with different jobs. Buyers who want to compare generations can look at the UBTECH Walker S2 Industrial Humanoid Robot and the UBTECH Walker S Industrial Humanoid Robot. The wider range is gathered in the UBTECH Walker category.
Positioning and key technology
Walker S1 is meant to be a worker that understands a task, finds its way through a plant and handles objects while staying upright. Three technologies carry that idea.
The first is task planning. A large language model is used for general task planning, which gives the robot intention understanding and task planning. In plain terms, the robot is not only replaying a fixed motion; it works from what it is asked to do.
The second is navigation. Walker S1 uses semantic VSLAM navigation, a two-stage semantic approach. It ties semantic perception information tightly to traditional VSLAM, so the robot reads the meaning of what it sees and not only the geometry of the space.
The third is motion control. An integrated perception and control framework drives learning-based, end-to-end whole-body motion control. This is what gives Walker S1 dexterous manipulation skills and stable walking.
The industrial setting brings hard problems, and this robot addresses three of them: visual positioning under varying lighting and environmental conditions, motion control under dynamic high-load conditions, and joint cooling during long-term high-load operation.
Technical Specifications
| Specification | Value |
|---|---|
| Model | Walker S1 |
| Series | Walker S, 2024 industrial humanoid |
| Degrees of freedom | 41 |
| Task planning | Large language model for general task planning; intention understanding and task planning |
| Navigation | Semantic VSLAM, two-stage semantic navigation |
| Motion control | Learning-based whole-body motion control for dexterous manipulation and stable walking |
| Works with | Autonomous logistics vehicles and AMRs/AGVs through smart manufacturing management systems |
| Application | Handling tasks in a BYD factory; vehicle manufacturing assembly lines |
Specifications as published by the manufacturer; confirmed against the datasheet at quotation.
The manufacturer has not published the height, the weight, the battery capacity, the battery runtime, the walking speed, the payload, the sensors and cameras, the connectivity, the IP rating, the power supply or the contents of the box; they are confirmed at quotation.
What makes Walker S1 different from a robot that only walks?
Many humanoids are shown walking, waving or balancing. Walker S1 is built around a different question: can the machine take part in a production process? The answer is concrete. Walker S1 has entered the BYD factory to perform handling tasks, and it has completed the world's first one-stop autonomous logistics application in which a humanoid robot coordinates with autonomous logistics vehicles, AMRs/AGVs and intelligent manufacturing management systems.
That coordination is the point. A plant already has vehicles that move material and software that decides what moves where. A humanoid that fits into that chain, rather than standing apart from it, can take the steps that fixed automation finds awkward, such as handling at stations built for human reach.
The three software layers support this. Planning with a language model lets the robot work from an intention. Semantic VSLAM lets it place itself in a changing space. Whole-body motion control keeps the manipulation and the walking working together, which matters when both happen in the same movement.
How does Walker S1 cope with factory conditions?
Factories are not tidy laboratories. Light changes across the day and from one area to the next, loads shift, and shifts run long. Three industrial challenges shape the design.
Visual positioning has to keep working under varying lighting and environmental conditions. Motion control has to stay stable under dynamic high-load conditions. Joint cooling has to hold up during long-term operation under high load. These are the points where a demonstration robot usually separates from a working one.
The 41 degrees of freedom give the body the range to reach, bend and turn, which suits workstations laid out for people.
Who is Walker S1 for?
Walker S1 fits manufacturers and integrators who are studying how humanoids can work in vehicle assembly and similar plants. Automotive and general manufacturing teams that already run autonomous logistics vehicles, AMRs/AGVs or a manufacturing management system have the clearest match, because the robot works with exactly those elements.
Research groups and technical institutes that want a humanoid platform with language-model planning, semantic navigation and learned whole-body control are a second group. Systems integrators preparing pilot programs for clients form a third.
Buyers who want to compare generations should open the UBTECH Walker S2 Industrial Humanoid Robot page, or the UBTECH Walker S Industrial Humanoid Robot page for the original model.
What is Walker S1 used for?
- Material handling. Handling tasks are the work the robot has performed in a BYD factory.
- Vehicle assembly support. It has been introduced into vehicle manufacturing assembly lines to assist in car production.
- Collaboration with logistics vehicles. It works together with autonomous logistics vehicles, so material and robot move as one flow.
- Coordination with AMRs and AGVs. The robot cooperates with these mobile platforms through smart manufacturing management systems.
- Multi-task factory work. The series is built for several tasks in one cell rather than a single repeated motion.
- Humanoid research and pilot programs. Planning, navigation and whole-body control make it a platform for testing embodied intelligence in industry.
Pricing and Availability
Pricing for Walker S1 is given by quotation and is not printed on this page. Send a request that describes your site, the tasks you have in mind and your timeline, and a quotation will be prepared for you. Delivery, customs and support are arranged together with the quotation. Walker S1 is available on this page.
Frequently Asked Questions
What is the UBTECH Walker S1?
It is UBTECH's 2024 industrial humanoid robot in the Walker S series. It is built for multi-task work on automotive assembly lines and similar factory settings.
How many degrees of freedom does it have?
Walker S1 has 41 degrees of freedom.
How does Walker S1 plan its tasks?
It uses a large language model for general task planning. This gives it intention understanding and task planning.
How does it navigate?
It uses semantic VSLAM navigation, a two-stage semantic method that ties semantic perception information to traditional VSLAM.
Can it work with other automation?
Yes. It has been used together with autonomous logistics vehicles, AMRs/AGVs and intelligent manufacturing management systems.
What should I include in a quotation request?
Describe your site, the tasks you want the robot to handle and your timeline. Include any questions about payload, battery or protection rating, and they will be answered in the quotation.
Where can I buy Walker S1 and what does it cost?
You can request it through this page. The cost is given in a quotation prepared for your project, and delivery, customs and support are arranged with it.
Summary
Walker S1 was not designed to impress on a stage; it was designed to be useful on a plant floor. It combines language-model task planning, semantic VSLAM navigation and learned whole-body motion control in a body with 41 degrees of freedom, and it has already done handling work in a BYD factory alongside logistics vehicles and management systems. For a team weighing a humanoid for assembly and logistics work, this page is the starting point.


