
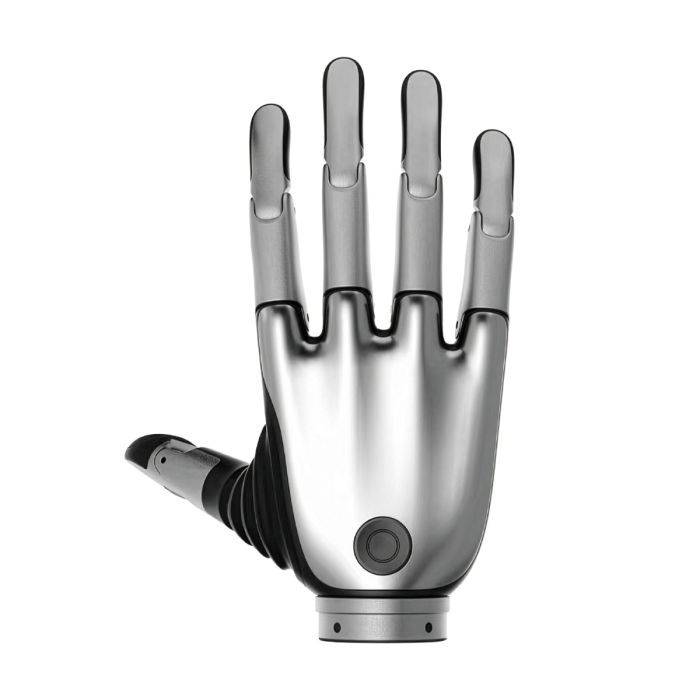
Brainco Revo 2 Touch Biomimetic Dexterous Left Hand (XTL)
In stock
- BRAND:
- BRAINCO
- MODEL:
- REVO 2 TOUCH (LEFT)
- PART #:
- XTL
- ORIGIN:
- China
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- BrainCo-Revo-2-Touch-Left
Brainco Revo 2 Touch Biomimetic Dexterous Left Hand (XTL)
A robot arm can reach almost anywhere, but it is the hand at the end that decides whether the work gets done. The Brainco Revo 2 Touch Biomimetic Dexterous Left Hand (XTL) is a bionic dexterous hand for robot integration and research, and it comes with the kind of numbers and interfaces an engineering team can plan around before the first bolt is turned.
The product is available through this page, by quotation.
Background
BrainCo and the Revo 2 family
BrainCo makes the Revo line of bionic hands, and the Revo 2 is the generation described here. It is sold in three versions: Basic (XRL/XRR), Pro (XEL/XER) and Touch (XTL/XTR). In every code the last letter marks the side. The XTL on this page is therefore the left-hand Touch version, and the XTR is its right-hand partner.
That structure makes shopping simpler. Teams can settle the version first and the side second, and they can order a matched pair when a humanoid platform needs two hands. The whole generation is gathered in the BrainCo Revo 2 category, and the Hands category shows how it sits beside other robot hands.
Where the Touch version fits
The Touch version carries the code XTL for the left hand and XTR for the right. It shares the family's core architecture: six active joints, eleven degrees of freedom, and three communication interfaces. What sets it apart in the lineup is its place as the Touch member of the generation, the one a research group would look at when it wants to study how a hand interacts with objects and not only how it moves.
The hand is biomimetic. In practice that means it is shaped around the human hand as a model, which suits a humanoid robot working in spaces and with objects designed for people. Closed-loop servo control, custom gesture definitions and a set of built-in protections complete the picture of a hand designed to be commanded closely and to survive being used hard.
Technical Specifications
| Specification | Value |
|---|---|
| Version code | XTL (left hand, Touch version); the right-hand partner is XTR |
| Product type | Bionic dexterous hand for robot integration and research |
| Active joints | 6 |
| Degrees of freedom | 11 in total |
| Pinch force | ≥15N |
| Control precision | 0.1° |
| Communication interfaces | RS485, CAN FD, EtherCAT |
| Control features | Closed-loop servo control, custom gesture definitions |
| Protections | Current, stall, high temperature and collision |
| SDK support | Linux, Windows and ROS workflows |
Specifications as published by the manufacturer; confirmed against the datasheet at quotation.
The manufacturer has not published the IP rating, the package contents, the tactile sensor resolution or the motor type; they are confirmed at quotation.
What do six active joints and eleven degrees of freedom mean for a robot hand?
The two numbers describe different things. The six active joints are the ones driven by actuators. The eleven degrees of freedom describe the total range of movement the hand can express. A hand with more freedom than actuated joints can still shape itself around an object in a natural way, without needing an actuator for every single motion. For a team, this is the balance between a hand that is rich enough for real manipulation and one that remains manageable to control.
Control precision is 0.1°, which tells an engineer how finely joint positions can be commanded. Combined with closed-loop servo control, it supports work where repeatability matters: grasp studies, teleoperation experiments and learning-based manipulation. The pinch force of ≥15N gives a clear reference point for the kind of precision grasping the hand is meant to do.
How does the Revo 2 Touch connect to a robot and a software stack?
Many projects slow down at integration rather than at the hand itself. The Revo 2 Touch offers three communication interfaces: RS485, CAN FD and EtherCAT. That range lets a team choose the bus that already exists in the robot, whether it is a simple serial link, a modern CAN network or an industrial real-time fieldbus.
On the software side, the SDK supports Linux, Windows and ROS workflows. Research groups that already work in ROS can bring the hand into their existing nodes and tools. Teams that develop on Windows, or that deploy on Linux controllers, are covered as well. Custom gesture definitions let you save the hand poses that your application needs, so that common grasps do not have to be rebuilt each time.
The protections matter just as much in a working lab. The hand guards against current, stall, high temperature and collision conditions. These are the situations that tend to appear when a prototype is tuned, a new grasp is tried or a trajectory goes slightly wrong. Having them built in lets a team experiment with more confidence.
Who is the Brainco Revo 2 Touch Left Hand for?
The first group is humanoid robot developers. A humanoid needs a left hand and a right hand, and the XTL is the left half of the Touch pair. For the matching side, see the Brainco Revo 2 Touch Biomimetic Dexterous Right Hand (XTR).
The second group is university and corporate research labs working on manipulation, grasping and human-robot interaction. They gain a hand with 0.1° control precision, three industrial interfaces and an SDK that fits the tools they already use.
The third group is integrators and industrial R&D teams who are evaluating a dexterous hand for a new application and need to learn what it can do before committing to a design.
Not every project needs the Touch version. Teams that want the same family at a more basic level can look at the BrainCo Revo 2 Basic Left Dexterous Bionic Hand (XRL), and those who want the middle version can look at the BrainCo Revo 2 Pro Dexterous Left Hand (XEL).
What is the Brainco Revo 2 Touch Left Hand used for?
- Humanoid robot integration: it serves as the left hand of a humanoid platform that needs human-like manipulation.
- Manipulation research: it lets labs study grasping, in-hand motion and object handling with a hand whose control precision is 0.1°.
- Teleoperation experiments: custom gesture definitions and closed-loop servo control support work in which an operator guides the hand.
- Industrial R&D: it gives development teams a dexterous end effector for testing new handling tasks before production decisions.
- ROS-based development: the SDK support for ROS workflows lets teams add the hand to the robotics software they already run.
- Teaching and demonstration: a biomimetic hand with built-in protections suits training environments where hardware is handled by many people.
Pricing and Availability
Prices are not listed here. A quotation is the way to proceed: tell us how many hands you need, which side and which version, and we will prepare it for you. Delivery, customs and support are arranged with the quotation, so that the details are clear before you commit. The Brainco Revo 2 Touch Biomimetic Dexterous Left Hand (XTL) is available on this page.
Frequently Asked Questions
Is this the left-hand or right-hand version?
This page covers the left-hand Touch version, code XTL. The right-hand partner carries the code XTR.
How many joints and degrees of freedom does it have?
The hand has 6 active joints and a total of 11 degrees of freedom.
Which communication interfaces does it support?
It supports RS485, CAN FD and EtherCAT, so it can be connected to a range of robot controllers and buses.
Which software environments are supported?
The SDK supports Linux, Windows and ROS workflows.
What protections are built in?
The hand has closed-loop servo control, custom gesture definitions, and protections for current, stall, high temperature and collision conditions.
Is the hand suited to humanoid robots?
Yes. It is a bionic dexterous hand for robot integration and research, and the XTL serves as the left hand of a humanoid platform.
Where can I buy the Brainco Revo 2 Touch Left Hand and what does it cost?
You can request it through this page, by quotation. The cost depends on your order, and the quotation sets out the details, including delivery, customs and support.
Summary
The hand at the end of the arm does the real work, and the Brainco Revo 2 Touch Biomimetic Dexterous Left Hand (XTL) is made for teams that take that seriously. It offers 6 active joints, 11 degrees of freedom, a pinch force of ≥15N and a control precision of 0.1°. Three industrial interfaces, SDK support for Linux, Windows and ROS, and built-in protections help it fit into a real lab or a real robot. For a quotation on this hand, this page is the starting point.
Specifications
General
Physical
Mobility
Performance
Connectivity
Software
Hand
What's included
Videos


