
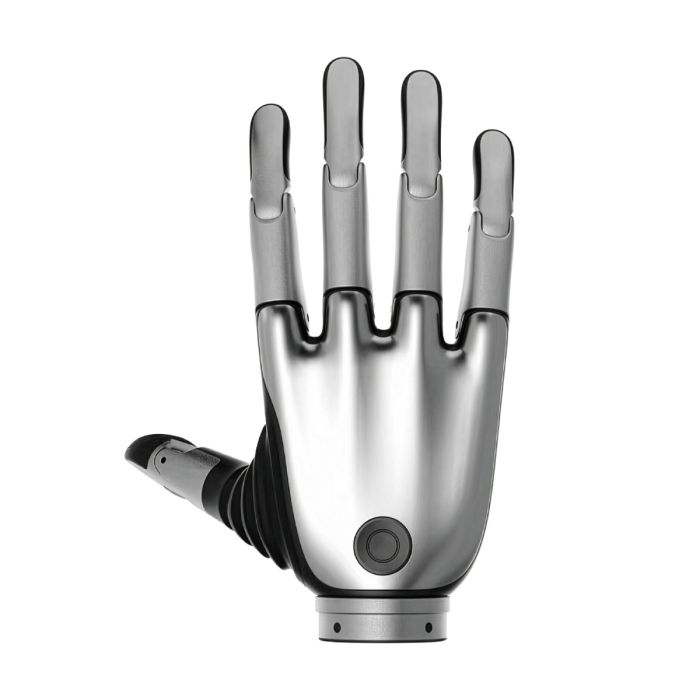
BrainCo Revo 2 Pro Dexterous Right Hand (XER)
In stock
- BRAND:
- BRAINCO
- MODEL:
- REVO 2 PRO
- PART #:
- XER
- ORIGIN:
- China
- Warranty:
- 12 MONTHS
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- BrainCo-Revo-2-Pro
BrainCo Revo 2 Pro Dexterous Right Hand (XER)
A good robot hand is not the one that moves in every direction. It is the one that knows which joints to drive and which to let give way. The BrainCo Revo 2 Pro Dexterous Right Hand (XER) is built on that bargain: a bionic dexterous hand for robot integration and research that pairs powered motion with passive motion, and wraps both in the communication options a lab or an integration team needs on day one.
The product is available through this page, by quotation.
Background
BrainCo and the Revo 2 series
BrainCo makes the Revo line of bionic hands, and the Revo 2 is the second generation of that line. The series comes in three versions: Basic (XRL/XRR), Pro (XEL/XER) and Touch (XTL/XTR). In each pair of codes, the first letter group stands for the left hand and the second for the right hand, so the XER described here is the right-hand model of the Pro version. Its left-hand counterpart is the BrainCo Revo 2 Pro Dexterous Left Hand (XEL).
The whole series is a bionic dexterous hand for robot integration and research. That wording is worth taking at face value. It is a component meant to be fitted to a robot or mounted on a research bench, and the documentation around it speaks to integrators. You can browse the wider family in the BrainCo Revo 2 category, or compare other end effectors in the Hands category.
What the Pro version is built around
Within the series, the Pro version is the one defined by its connectivity. It supports three interfaces for communication and control: 485, CAN FD and EtherCAT. The interface is located below the wrist, which matters to anyone planning how a cable leaves the forearm and where a controller will sit.
The motion layout is shared by the whole series. The hand has 6 active joints and 11 degrees of freedom. The thumb has two active degrees of freedom for abduction and adduction, plus one passive degree of freedom for flexion and extension. Each of the other four fingers has one active and one passive degree of freedom for flexion and extension. In plain terms, the hand does not try to motor every joint; it drives the ones that decide the grasp and lets the rest follow.
On the control side, the hand uses closed-loop servo control and lets you define your own gestures. It also carries protections for current, stall, high temperature and collision conditions. Software support covers Linux, Windows and ROS workflows through the SDK, so the hand fits the environments in which research and humanoid teams usually already work.
Technical Specifications
| Specification | Value |
|---|---|
| Product type | Bionic dexterous hand for robot integration and research |
| Version and handedness | Pro, right hand (XER) |
| Active joints | 6 |
| Degrees of freedom | 11 |
| Thumb | Two active degrees of freedom (abduction and adduction); one passive degree of freedom (flexion and extension) |
| Each of the four fingers | One active and one passive degree of freedom (flexion and extension) |
| Communication interfaces | 485, CAN FD, EtherCAT |
| Interface location | Below the wrist |
| SDK support | Linux, Windows, ROS workflows |
| Control | Closed-loop servo control; custom gesture definitions |
| Protections | Current, stall, high temperature, collision |
Specifications as published by the manufacturer; confirmed against the datasheet at quotation.
The manufacturer has not published the dimensions, the wrist mounting dimensions, the material, the IP rating or the service life; they are confirmed at quotation.
What makes the Pro version different from the Basic version?
The motion layout, the control features, the protections and the SDK support belong to the whole Revo 2 series, so the choice between versions does not come down to how many joints the hand has. What sets the Pro apart is communication: the advanced version supports 485, CAN FD and EtherCAT, with the interface below the wrist.
That is a practical difference for a team. A robot that already speaks EtherCAT, or a test rig built around CAN FD, can take the hand without a protocol bridge in the middle. A team that prefers a simple serial link can use 485. Having all three means the hand is not the component that forces a redesign of the control architecture.
If your project is simpler, the right-hand Basic version, the BrainCo Revo 2 Basic Right Dexterous Bionic Hand (XRR), deserves a look as well. Compare its interface options against your controller before you commit.
Why does a right-hand model matter in a robot build?
A hand is not symmetrical in use. On a humanoid or a dual-arm station, the left and right hands are mirrored parts with their own codes, and the thumb sits on a different side. Ordering the XER gives you the right-hand configuration of the Pro version; if your build needs both sides, the XEL covers the left. Specifying the handedness at the start avoids a mismatch discovered at assembly.
The thumb deserves a word of its own. With two active degrees of freedom for abduction and adduction, it can be positioned against the fingers rather than simply closing beside them. That is the part of the design that makes opposition possible, and it is where a research group will probably spend most of its tuning time through the SDK and custom gestures.
Who is the BrainCo Revo 2 Pro Dexterous Right Hand (XER) for?
Humanoid robot programs are the obvious audience. They need a right-hand end effector that can be integrated with the rest of the body over a bus the main controller already uses, and that can be driven from Linux or ROS software.
University laboratories and corporate research groups are the second segment. The hand is a research tool, with custom gesture definitions and SDK support for Linux, Windows and ROS, so it suits experiments in grasping, teleoperation and manipulation where the researcher wants to define the behaviors.
Integrators building demonstration cells or prototype manipulators are the third. The protections for current, stall, high temperature and collision help a hand survive the first weeks of a new setup, when software is still being debugged.
If you need the mirrored part, choose the Pro left hand (XEL). If touch sensing is the center of your project, the right-hand Touch version, the Brainco Revo 2 Touch Biomimetic Dexterous Right Hand (XTR), is the one to examine, since the Touch line is the series' tactile version.
What is the BrainCo Revo 2 Pro Dexterous Right Hand (XER) used for?
- Humanoid robot end effector. It gives a humanoid platform a right hand with a movable thumb and four fingers.
- Manipulation research. Labs can study grasping and in-hand behavior using the SDK on Linux, Windows or ROS.
- Teleoperation experiments. A hand with custom gestures can be mapped to an operator's commands for remote handling trials.
- Controller and protocol testing. With 485, CAN FD and EtherCAT available, teams can test which bus suits their architecture.
- Prototype manipulators. Integrators can fit the hand to an arm to demonstrate a task before a larger build.
- Teaching and demonstration. The mix of active and passive joints is a clear example for courses in robot hand design.
Pricing and Availability
We do not print prices on this page. Please request a quotation, and tell us your controller, your communication bus and the handedness you need so that the offer matches your build. Delivery, customs and support are arranged together with the quotation. The BrainCo Revo 2 Pro Dexterous Right Hand (XER) is available on this page.
Frequently Asked Questions
What does XER mean?
XER is the code of the right-hand model of the Pro version of the Revo 2. The left-hand model of the Pro version is coded XEL.
How many joints and degrees of freedom does the hand have?
The hand has 6 active joints and 11 degrees of freedom. The thumb has two active and one passive degree of freedom, and each of the other four fingers has one active and one passive degree of freedom.
Which communication interfaces does the Pro version support?
It supports 485, CAN FD and EtherCAT for communication and control. The interface is located below the wrist.
Which software environments are supported?
The SDK supports Linux, Windows and ROS workflows. The hand also allows custom gesture definitions.
What protections does the hand include?
It has closed-loop servo control and protections for current, stall, high temperature and collision conditions.
Is this hand meant for consumers?
No. It is a component for robot integration and research, to be fitted to a robot or used on a research bench.
Where can I buy the BrainCo Revo 2 Pro Dexterous Right Hand (XER) and what does it cost?
You can buy it through this page, by quotation. The cost is given in the quotation itself, together with delivery, customs and support arrangements.
Summary
The idea behind this hand is a sensible division of labor: drive the joints that decide the grasp, let the others follow, and protect the whole against overload. The BrainCo Revo 2 Pro Dexterous Right Hand (XER) adds three communication options, SDK support for Linux, Windows and ROS, and a right-hand layout with a thumb that can be positioned against the fingers. For humanoid programs, research labs and integrators who want that combination, this page is the starting point.
Specifications
General
Physical
Mobility
Performance
Connectivity
Software
Hand
Feature
1. High quality and stability – five years of product iteration and professional production lines.
2. Lightweight (383 grams), with 5 kg active grip force, 20 kg single-hand load capacity, and a grip-to-weight ratio of 53.
3. Ergonomic Bionic Design – supports curved surface grasping with anti- collision finger design.
4. Multi-dimensional tactile perception – pressure, friction, direction, proximity, and surface texture.
5. High Sensitivity Tactile Perception – max resolution of 0.01N.
6. Wide voltage support – 64V.
7. Universal Interfaces – RS485 & CAN-FD, and EtherCAT.
8. Standard Protocols and SDKs – Modbus & Protobuf protocols, SDKs for Python / C / ROS.


