
BrainCo Revo 2 Pro Dexterous Left Hand (XEL)
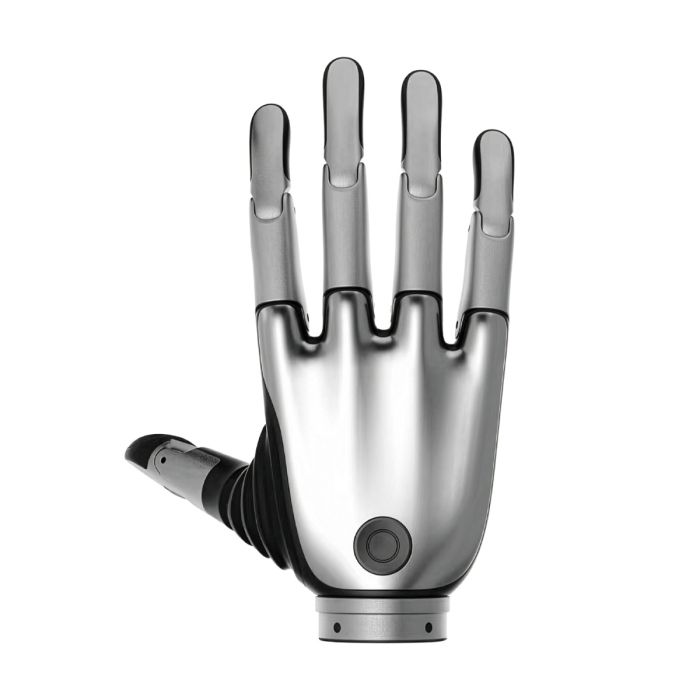
In stock
- BRAND:
- BRAINCO
- MODEL:
- REVO 2 PRO
- PART #:
- XEL
- ORIGIN:
- China
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- BrainCo-Revo-2-Pro-Left
BrainCo Revo 2 Pro Dexterous Left Hand (XEL)
Counting a robot hand's joints and counting its degrees of freedom give two different numbers, and the gap between them says a lot about how the hand was designed. The BrainCo Revo 2 Pro Dexterous Left Hand (XEL) has 6 active joints, yet it offers 11 degrees of freedom. That is the kind of arithmetic a robotics team cares about when a left hand has to do real work on a bench, in a lab or on a humanoid platform.
The product is available through this page, by quotation.
Background
BrainCo and the Revo 2 series
BrainCo describes the Revo 2 as a bionic dexterous hand for robot integration and research. The series comes in three versions: Basic (XRL/XRR), Pro (XEL/XER) and Touch (XTL/XTR). In each pair the first code is the left hand and the second is the right hand, so the codes tell you which side you are ordering.
This page covers the Pro left hand, version code XEL. Its right-hand partner is the BrainCo Revo 2 Pro Dexterous Right Hand (XER). The wider family sits in the BrainCo Revo 2 category, and hands from other lines are grouped under Hands.
Positioning and key technology
The Pro version is the middle step of the series. What defines it is a mechanism that moves more than its joint count suggests: 6 active joints combine to give a total of 11 degrees of freedom. A designer who plans grasps for a humanoid or a research arm gets room to shape the fingers around an object without needing a separate actuator for every motion.
Control is closed-loop servo control, and the hand supports custom gesture definitions. Control precision is 0.1°. The hand also watches itself: it includes current protection, stall protection, high-temperature protection and anti-collision protection. These matter most in the early life of a project, when code is new, targets are approximate and fingers sometimes meet things they were not meant to meet.
On the connection side, the hand supports RS485, CAN FD and EtherCAT communication interfaces. For software, SDK support covers Linux, Windows and ROS workflows. Teams can therefore bring the hand into the setup they already use rather than rebuild their tooling around it.
Technical Specifications
| Specification | Value |
|---|---|
| Version code | XEL (left hand); the right-hand partner is XER |
| Product type | Bionic dexterous hand for robot integration and research |
| Active joints | 6 |
| Degrees of freedom | 11 in total |
| Pinch force | ≥15N |
| Control precision | 0.1° |
| Control | Closed-loop servo control, custom gesture definitions |
| Protections | Current, stall, high-temperature and anti-collision protection |
| Communication interfaces | RS485, CAN FD, EtherCAT |
| SDK support | Linux, Windows, ROS workflows |
| Standard colors | Space Gray, Silver (bulk color customization supported) |
Specifications as published by the manufacturer; confirmed against the datasheet at quotation.
The manufacturer has not published the Pro-specific weight, the IP rating, the box contents, the cable length or the certifications; they are confirmed at quotation.
What makes the Pro different from the Basic and Touch versions?
The three versions share a platform, and the version code is the quickest way to tell them apart: XRL/XRR for Basic, XEL/XER for Pro and XTL/XTR for Touch. This page carries the full set of figures for the Pro only, so we do not put a Basic or Touch number next to this hand. What can be said is how the Pro presents itself: 6 active joints, 11 degrees of freedom, closed-loop servo control, custom gestures and four named protections.
If your work calls for a simpler hand, the BrainCo Revo 2 Basic Left Dexterous Bionic Hand (XRL) is the Basic left-hand unit. If you are interested in the Touch line, the Brainco Revo 2 Touch Biomimetic Dexterous Left Hand (XTL) is its left-hand counterpart. Request both datasheets with your quotation and compare them side by side before you decide.
Why do the built-in protections matter?
A hand under development is exposed to mistakes that a finished product never sees: a gesture sent at the wrong speed, a target placed a little too close, a finger that stalls against a fixture. The four protections in this hand answer exactly those situations. Current protection and stall protection deal with a finger that is pushing against something it cannot move. High-temperature protection deals with long cycles of repeated motion. Anti-collision protection deals with unexpected contact.
None of this replaces careful programming, but it lets a team iterate with more confidence. It is also a practical argument for choosing a research-oriented hand over a bare mechanism when several people share the same hardware.
Who is the BrainCo Revo 2 Pro Dexterous Left Hand (XEL) for?
Humanoid robot builders come first. A two-handed robot needs a left unit that matches the right, and the Pro line gives them a pair with the same specification. Order this hand together with the XER and both sides behave alike.
University labs and research groups are the second segment. The ROS support, the Linux and Windows SDK and the three communication interfaces suit teams that already run mixed software and fieldbus setups. Custom gesture definitions help researchers who study grasp types and want to define their own.
Integrators and prototype teams form the third segment. They need a hand that tolerates the trial-and-error phase, which is where the protections earn their place. Buyers whose task is simpler can look at the Basic version, and those who want the Touch line can see the Touch hands linked above. The Pro suits the buyer in between.
What is the BrainCo Revo 2 Pro Dexterous Left Hand (XEL) used for?
- Humanoid robot integration. It serves as the left hand of a two-handed platform, matched with the XER on the right.
- Academic research. It supports studies of grasping, manipulation and hand control on a platform with 0.1° control precision.
- Gesture programming. Custom gesture definitions allow teams to build their own set of hand poses for demonstrations or tasks.
- Prototype development. Current, stall, high-temperature and anti-collision protection make early testing less risky for the hardware.
- Fieldbus-based systems. RS485, CAN FD and EtherCAT interfaces let the hand join existing industrial-style control networks.
- Cross-platform software work. The SDK for Linux, Windows and ROS fits into different development environments within one team.
Pricing and Availability
We do not publish prices on this page. A quotation is how you buy: tell us the quantity, the side you need and any color customization, and we will respond with a quotation. Delivery, customs and support are arranged together with the quotation, so the Caribbean destination is handled from the start. The BrainCo Revo 2 Pro Dexterous Left Hand (XEL) is available on this page.
Frequently Asked Questions
Is this the left or the right hand?
This is the left hand, version code XEL. The right-hand partner is the XER, which has its own page.
How many degrees of freedom does it have?
The hand has 6 active joints and a total of 11 degrees of freedom.
Which communication interfaces and software does it support?
It supports RS450, CAN FD and EtherCAT interfaces. The SDK covers Linux, Windows and ROS workflows.
What protections are built in?
It includes current protection, stall protection, high-temperature protection and anti-collision protection, along with closed-loop servo control.
What colors are available?
The standard colors are Space Gray and Silver. Bulk color customization is supported.
What are the weight, IP rating and cable length?
Those figures are not listed on this page. Ask for them when you request your quotation.
Where can I buy the BrainCo Revo 2 Pro Dexterous Left Hand (XEL) and what does it cost?
You can buy it through this page by requesting a quotation. We do not list a price here; the quotation gives the cost for your quantity and destination.
Summary
The interesting number on this hand is the gap between 6 active joints and 11 degrees of freedom: a mechanism that gives more motion than it has actuated joints, backed by closed-loop control, 0.1° precision, a pinch force of ≥15N and four built-in protections. With RS485, CAN FD and EtherCAT interfaces and SDK support for Linux, Windows and ROS, it fits the setups that humanoid builders and research labs already run. If you need a left hand that matches the right, this page is the starting point.
Specifications
General
Physical
Mobility
Performance
Connectivity
Software
Hand
Feature
1. High quality and stability – five years of product iteration and professional production lines.
2. Lightweight (383 grams), with 5 kg active grip force, 20 kg single-hand load capacity, and a grip-to-weight ratio of 53.
3. Ergonomic Bionic Design – supports curved surface grasping with anti- collision finger design.
4. Multi-dimensional tactile perception – pressure, friction, direction, proximity, and surface texture.
5. High Sensitivity Tactile Perception – max resolution of 0.01N.
6. Wide voltage support – 64V.
7. Universal Interfaces – RS485 & CAN-FD, and EtherCAT.
8. Standard Protocols and SDKs – Modbus & Protobuf protocols, SDKs for Python / C / ROS.


