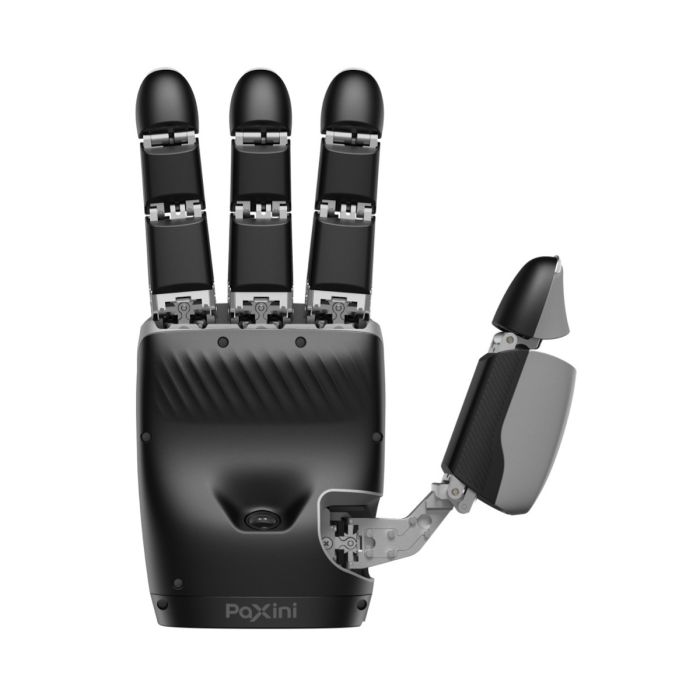
Paxini DexH13 Dexterous Robot Hand (DexH13)
In stock
- BRAND:
- PAXINI
- MODEL:
- DEXH13
- PART #:
- DexH13
- ORIGIN:
- China
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- Paxini-DexH13
Paxini DexH13 Dexterous Robot Hand (DexH13)
A camera can tell a robot where an object is, but only touch can tell it what the object is doing once the fingers close. The Paxini DexH13 Dexterous Robot Hand (DexH13) is built around that idea. It pairs a dense field of tactile sensing units with an eye-in-hand camera, so the hand sees what it is about to hold and feels what it is holding.
The product is available through this page, by quotation.
Background
PaXini and the DexH family
PaXini is a robotics company that builds around tactile perception. Its range, which you can browse in the PaXini category, includes dexterous hands and humanoid robot platforms. The DexH13 is the second generation (Gen2) of the company's dexterous hand line. The first generation is the DexH5, which has its own page at Paxini Dexh5 (DexH5).
Other PaXini products show where the hand fits in the wider range. Among them are the Paxini GMH18 Robot Hand and the Paxini TORA ONE Multi-Dimensional Tactile Wheeled Humanoid Robot. Buyers who plan a larger robotics project often look at the hand and the platform together.
A dual-modal end-effector
The manufacturer describes the DexH13 as the world's first dual-modal robotic end-effector that integrates multi-dimensional tactile sensing with AI vision. In plain terms, the hand has two ways of sensing the world. One is touch, spread across the hand. The other is sight, from a camera mounted on the hand itself.
The hand carries 1140 ITPU multi-dimensional tactile sensing units in a single hand, with up to 15 dimensions of human-like perception. It also carries an 8MP RGB HD eye-in-hand camera. The mechanical design is a four-finger, 16-DOF bionic structure, made up of 13 active and 3 passive degrees of freedom. The thumb has four independent active DOF.
Technical Specifications
| Specification | Value |
|---|---|
| Product type | Dual-modal robotic end-effector: multi-dimensional tactile sensing and AI vision |
| Generation | Second generation (Gen2) |
| Tactile sensing units | 1140 ITPU multi-dimensional tactile sensing units in a single hand |
| Perception | Up to 15 dimensions of human-like perception |
| Structure | Four-finger bionic structure |
| Degrees of freedom | 16 DOF (13 active + 3 passive) |
| Thumb | Four independent active DOF |
| Camera | 8MP RGB HD eye-in-hand camera |
| Actions | Grasping, gripping, pinching, pressing, opening and closing fingers |
| Control | Flexible and compliant motion control, high-precision force control |
Specifications as published by the manufacturer; confirmed against the datasheet at quotation.
The manufacturer has not published the weight, the dimensions, the power supply voltage, the IP rating, the mounting interface, the contents of the box, the SDK and software support or the operating temperature; they are confirmed at quotation.
What makes the DexH13 different from a vision-only gripper?
A gripper that relies on a camera alone works well until the moment of contact. Once the fingers close around an object, the hand and the object often block the view. From that point the controller has very little to go on.
The DexH13 addresses this with touch. With 1140 tactile sensing units and up to 15 dimensions of perception, the hand can register how contact develops across its surface. The sensing is multi-dimensional, which means it describes more than simple pressure on or off. That information supports the compliant motion control and high-precision force control the manufacturer describes for this hand.
The camera still matters. Because it sits on the hand, it looks at the object from the same point of view as the fingers. Sight guides the approach and touch takes over for the grip. This combination is the reason the manufacturer calls the hand dual-modal.
How does the four-finger design help with dexterity?
The DexH13 uses four fingers rather than five. Its 16 degrees of freedom are split into 13 active and 3 passive. The thumb alone has four independent active DOF, which gives it the freedom to oppose the other fingers in several ways.
This matters for the actions the manufacturer lists: grasping, gripping, pinching, pressing, and opening and closing the fingers. Each of these asks the thumb and fingers to work together in a different pattern. A pinch uses fingertip contact. A press needs controlled force. A power grasp needs the whole hand to wrap around an object. A hand with many independent joints and tactile feedback is better placed to cover that range than a simple two-jaw gripper.
Who is the Paxini DexH13 for?
The DexH13 suits teams that need touch-aware manipulation and cannot get it from a simple gripper. Typical buyers include:
- Research laboratories that study manipulation, tactile learning and hand-eye coordination.
- Education programs that teach robotics with real dexterous hardware.
- Industrial integrators that handle parts where contact has to be controlled.
- Logistics and warehousing teams that pick varied items.
- Medical and healthcare developers that need careful, compliant handling.
Buyers who want to see the earlier generation can read about the first-generation Paxini Dexh5 (DexH5) on its own page. If your project needs a whole robot rather than a hand, the PaXini TORA DOUBLE ONE Lightweight Humanoid Robot is another page to consult. Our team can help you compare the options when you request a quotation.
What is the Paxini DexH13 used for?
- Industrial manufacturing: handling parts and components where contact has to be felt and controlled.
- Logistics and warehousing: picking and placing items of different shapes with touch feedback.
- Medical and healthcare: careful, compliant handling in settings that call for gentle contact.
- Education and research: studying dexterous manipulation with a hand that senses touch and sight together.
- Precision grasping and pinching: holding objects firmly and picking up small items with fingertip control.
- Pressing and finger actions: pressing, opening and closing fingers under force control for contact-rich tasks.
Pricing and Availability
We do not print prices on this page. Every DexH13 is quoted to the project, so the quotation is the next step. Please send us your application and your integration needs. Delivery, customs and support are arranged together with the quotation. The Paxini DexH13 Dexterous Robot Hand (DexH13) is available on this page.
Frequently Asked Questions
What is the Paxini DexH13?
It is a dexterous robot hand that combines multi-dimensional tactile sensing with AI vision. The manufacturer describes it as the world's first dual-modal end-effector of this kind.
How many tactile sensing units does it have?
The hand integrates 1140 ITPU multi-dimensional tactile sensing units. They provide up to 15 dimensions of human-like perception.
How many degrees of freedom does the hand have?
It has a four-finger, 16-DOF structure, made up of 13 active and 3 passive degrees of freedom. The thumb has four independent active DOF.
Does the hand include a camera?
Yes. It is equipped with an 8MP RGB HD eye-in-hand camera.
Which actions can the hand perform?
With its compliant motion control and high-precision force control, it performs grasping, gripping, pinching, pressing, and opening and closing of the fingers.
Is the DexH13 the same as the DexH5?
No. The DexH13 is the second generation (Gen2) and the DexH5 is the first generation. Each has its own page, and the figures on this page belong to the DexH13 only.
Where can I buy the Paxini DexH13 and what does it cost?
You can buy it through this page by requesting a quotation. The price depends on your project, so we quote it individually and do not list an amount here.
Summary
A robot hand that only sees is guessing at the moment of contact. The DexH13 reduces that guesswork by adding touch to sight. It offers 1140 tactile sensing units, a 16-DOF four-finger structure with an independent four-DOF thumb, and an 8MP eye-in-hand camera. It is aimed at industrial manufacturing, logistics and warehousing, medical and healthcare, and education and research. If you want to evaluate it for your own application, this page is the starting point.