
Xynova PR64-110-500 Rotary Actuator
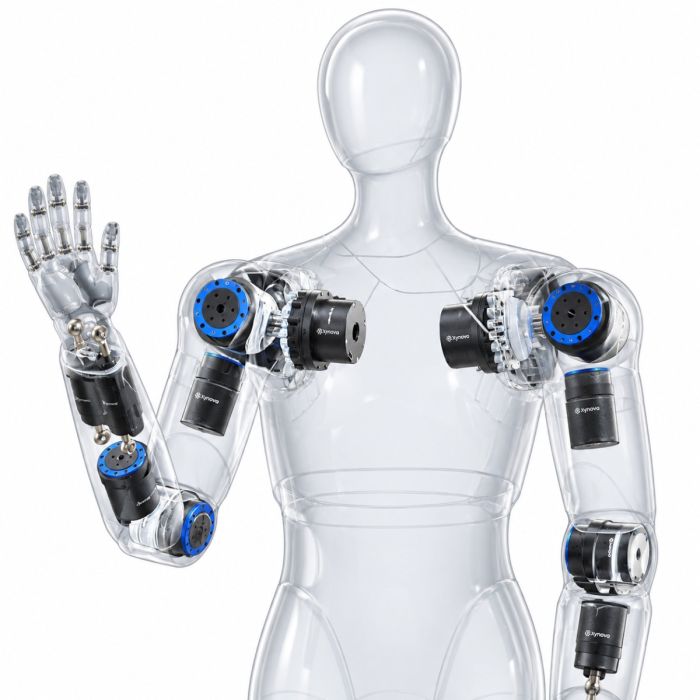
In stock
- BRAND:
- XYNOVA
- MODEL:
- PR64-110-500
- ORIGIN:
- China
- Warranty:
- 12 MONTHS
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- Xynova-PR64-110-500
Xynova PR64-110-500 Rotary Actuator
A humanoid robot has to carry its own muscles, and every gram in a shoulder or hip is a gram the rest of the body must support. The Xynova PR64-110-500 Rotary Actuator is built around that problem: a compact joint module that packs its torque into a small, light housing, so the machine around it can be smaller too.
The product is available through this page, by quotation.
Background
Xynova and its place in humanoid robotics
Xynova Technology Co., Ltd. is a core component supplier in the field of humanoid robots. That tells you where the company puts its effort. It does not build general-purpose motors for every industry. It concentrates on the joints that let a walking, reaching and lifting robot move. The catalog includes rotary actuators, which are the subject of this page, and linear actuators, and the series is organized so that different joints of one robot can draw on the same family of parts.
The series covers a torque range of 6.7-500Nm, which meets the needs of all joints. For a design team, that matters in practice. Hip, knee, shoulder, elbow and wrist all ask for different amounts of torque, and a single supplier that covers the whole range simplifies the bill of materials, the control software and the spare-parts plan.
What sets the PR64-110-500 apart technically
The PR64-110-500 is custom-designed for humanoid robots. Its gearbox is an in-house developed planetary gearbox, optimized for high-burst movements. Humanoid joints rarely work at a steady load. They push hard for a moment during a step, a jump or a catch, and then ease off. A gearbox tuned for those bursts suits that duty better than one tuned only for steady running.
At the same peak torque, the module size is reduced by more than 45% and the weight by more than 35%. The module itself measures Φ110×64.3mm and reaches a torque density of 323Nm/kg. The no-load speed is 45r/min.
The actuator is controlled through in-house developed upper-level software with a rich set of API interfaces. This makes it easy to coordinate and control multiple actuators together, which is the everyday reality of a humanoid with dozens of joints.
Technical Specifications
| Specification | Value |
|---|---|
| Model | PR64-110-500 |
| No-load speed | 45 r/min |
| Torque density | 323 Nm/kg |
| Size | Φ110×64.3 mm |
| Gearbox | In-house developed planetary gearbox, optimized for high-burst movements |
| Application | Custom-designed for humanoid robots |
| Size and weight reduction at the same peak torque | Module size reduced by more than 45%, weight reduced by more than 35% |
| Software | In-house developed upper-level software with a rich set of API interfaces |
| Torque range of the series | 6.7-500 Nm |
Specifications as published by the manufacturer; confirmed against the datasheet at quotation.
The manufacturer has not published the continuous torque, the communication interface, the IP rating, the operating temperature range, the rated current, the motor type, the package contents or the mounting dimensions; they are confirmed at quotation.
What makes the PR64-110-500 different from a conventional joint motor?
A conventional arrangement pairs a general-purpose motor with a separate gearbox and then adds the housing, the sensing and the wiring. The result works, but it is often heavy and tall, and the integration falls to the robot builder. The PR64-110-500 takes the opposite route. It is a joint module designed for one purpose, humanoid robots, with the gearing developed by the same company that wrote the control software.
The most telling figure is the torque density of 323Nm/kg. It shows how much torque the module delivers for each kilogram of its own mass, and for a limb that must be lifted by the joint above it, that ratio decides how much the robot can carry and how long its reach can be. At the same peak torque, module size is reduced by more than 45% and weight by more than 35%. Smaller joints leave more room for wiring, covers and sensors, and lighter joints put less demand on the joints above them.
The planetary gearbox is the other half of the answer. It is optimized for high-burst movements, which describes how a legged robot actually moves: short, strong efforts rather than a constant load. At 45r/min no-load speed, the module is clearly a joint drive rather than a wheel or fan drive, and the figure suits the speed range of limb movements.
How does this actuator fit into a multi-joint robot?
A humanoid is not one actuator but many, and the difficulty lies in making them work together. Xynova supplies in-house developed upper-level software with a rich set of API interfaces, built for easy coordination and control of multiple actuators. For an engineering team this can shorten the path from a bench test of one joint to a moving limb, because the same software layer addresses several modules.
Because the series spans 6.7-500Nm, a team can also stay with one supplier across the body instead of mixing suppliers joint by joint. Tell us which joint you are designing and we will work through the details with you.
Who is the Xynova PR64-110-500 for?
The first group is humanoid robot developers, whether a startup building its first full-size prototype or an established team refining the next generation. They need joints that are compact, light and strong, and this module was designed for exactly that case.
The second group is university and corporate research laboratories working on legged locomotion, manipulation and whole-body control. A module with a rich software interface and a high torque density gives them a sound starting point for experiments.
The third group is system integrators building custom robotic platforms who want an actuator made for humanoid duty rather than adapted from another field.
If your joint needs differ from this model, the series offers other versions. You can look at the Xynova PR43-120-600-HB Rotary Actuator, the Xynova PR20-102-130-HS Rotary Actuator, the Xynova PRH19-57-25-HS Rotary Actuator or the Xynova PR21-100-140-HS Rotary Actuator. The wider selection is listed under Robot Actuators.
What is the Xynova PR64-110-500 used for?
- Humanoid robot joints. The module is custom-designed for the moving joints of humanoid robots.
- Burst-motion tasks. The planetary gearbox is optimized for the short, strong movements of stepping, lifting and catching.
- Weight-sensitive limbs. High torque density helps keep arms and legs light for the joints that carry them.
- Multi-actuator coordination. The API-rich software layer supports control of several actuators together.
- Research prototypes. Laboratories can use it to test locomotion and manipulation concepts on real hardware.
- Custom robotic platforms. Integrators can build it into bespoke machines that need a compact rotary joint.
Pricing and Availability
We do not print prices on this page. Each actuator is quoted for your project, because the quantity, the version and the application all matter. Send us your request and we will reply with a quotation. Delivery, customs and support are arranged with the quotation, so you see the whole picture before you order. The Xynova PR64-110-500 Rotary Actuator is available on this page.
Frequently Asked Questions
What is the Xynova PR64-110-500?
It is a rotary actuator from Xynova Technology Co., Ltd., custom-designed for humanoid robots. It combines an in-house developed planetary gearbox with in-house control software.
What are its main figures?
The no-load speed is 45r/min, the torque density is 323Nm/kg and the size is Φ110×64.3mm. At the same peak torque, size is reduced by more than 45% and weight by more than 35%.
What kind of gearbox does it use?
It uses an in-house developed planetary gearbox. It is optimized for high-burst movements.
How do I control several actuators at once?
Xynova supplies in-house developed upper-level software with a rich set of API interfaces. It makes coordination and control of multiple actuators easy.
Are the IP rating and continuous torque listed?
They are not listed in the table above. Ask for them when you request your quotation.
Are other versions available?
Yes, the series includes other rotary actuators, such as the PR43-120-600-HB and the PR20-102-130-HS. The series torque range is 6.7-500Nm, and we can help you choose by joint.
Where can I buy the Xynova PR64-110-500 and what does it cost?
You can request it through this page. The cost depends on your quantity and project, so we provide it in a quotation rather than as a listed price.
Summary
The Xynova PR64-110-500 answers a simple question: how do you give a humanoid strong joints without making the body heavy? It does so with a compact Φ110×64.3mm module, a torque density of 323Nm/kg, a planetary gearbox tuned for bursts of movement and software built to coordinate many actuators. If you are designing a humanoid joint and want a quotation, this page is the starting point.


