
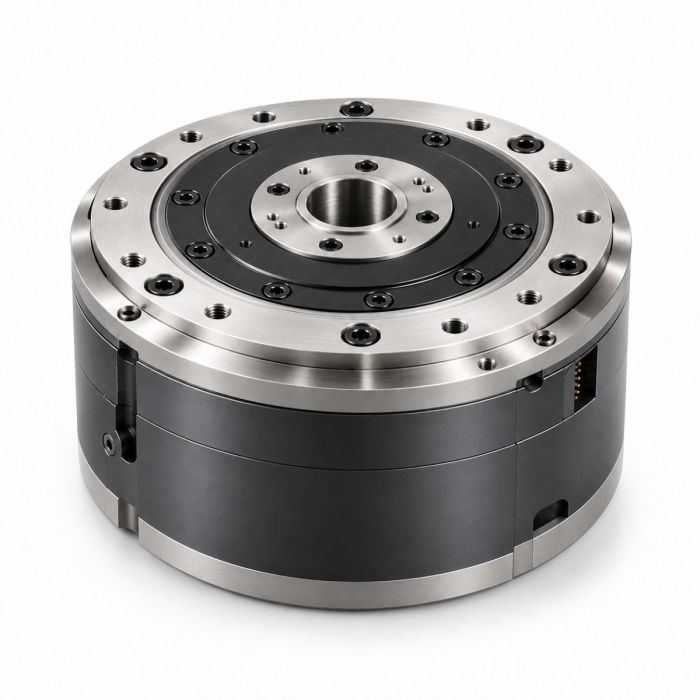
Xynova PR21-100-140-HS Rotary Actuator
In stock
- BRAND:
- XYNOVA
- MODEL:
- PR21-100-140-HS
- ORIGIN:
- China
- Warranty:
- 12 MONTHS
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- Xynova-PR21-100-140-HS
Xynova PR21-100-140-HS Rotary Actuator
A humanoid robot's elbow has to be strong and light at once, and every gram the joint adds is a gram the rest of the machine must carry. The Xynova PR21-100-140-HS Rotary Actuator is built around that tension: a 48V joint module that reaches 140Nm of peak torque while weighing 1.2kg, in a body of Φ100×61.7mm.
The product is available through this page, by quotation.
Background
Who is Xynova?
Xynova (曦诺未来) is a brand of 杭州曦诺未来科技有限公司. The company concentrates on core components for humanoid robots: dexterous hands with many degrees of freedom, and electric drive systems. It was founded in December 2024 in Hangzhou, Zhejiang, which makes it a young manufacturer. Its focus is narrow. It builds the parts that make a humanoid robot move and grip, rather than the whole machine.
For a buyer in robotics, that focus matters. A company that makes both the hand and the joint drive understands how the pieces must work together. The rotary actuators are the electric drive side of that work, and the PR21-100-140-HS is one member of the range.
Where does the PR21-100-140-HS sit in the range?
The Xynova rotary actuator range covers 6.7 to 500Nm of torque, enough for the waist, hip, knee and elbow joints of a humanoid robot. The PR21-100-140-HS is a mid-sized module in that spread, with a peak torque of 140Nm and a torque density of 117Nm/kg. It suits joints that need real strength without a heavy actuator hanging off the limb.
Two other traits belong to the range as a whole. The structure is compact and has a built-in high-speed heat dissipation channel, so that the module can keep working efficiently without overheating. Xynova also develops its own host-computer software, with rich API interfaces that make it straightforward to coordinate several modules at once. Other rotary actuators in the family, such as the Xynova PR20-102-130-HS Rotary Actuator and the Xynova PR43-120-600-HB Rotary Actuator, are listed separately.
Technical Specifications
| Specification | Value |
|---|---|
| Rated voltage | 48V |
| No-load speed | 130r/min |
| Peak torque | 140Nm |
| Torque density | 117Nm/kg |
| Module weight | 1.2kg |
| Dimensions | Φ100×61.7mm |
| Encoder resolution | 16bit |
| Repeat positioning accuracy | ≤0.1° |
Specifications as published by the manufacturer; confirmed against the datasheet at quotation.
The manufacturer has not published the rated torque, the continuous torque, the communication interface, the rated current, the IP rating, the operating temperature, the mounting dimensions, the backlash, the motor type or the contents of the box; they are confirmed at quotation.
What makes the PR21-100-140-HS different from the other Xynova rotary actuators?
The first difference is the size class. Xynova's rotary actuators run across a wide torque range, from 6.7Nm up to 500Nm, and each model designation marks a different point on that scale. The PR21-100-140-HS is the module whose peak torque is 140Nm. If your joint needs noticeably more or less than that, one of the neighboring designations may fit better, and you can compare them on their own pages, for example the Xynova PR64-110-500 Rotary Actuator or the Xynova PRH19-57-25-HS Rotary Actuator.
The second difference is how the figures balance. A torque density of 117Nm/kg tells you how much peak torque the module delivers for each kilogram of its own weight. At 1.2kg, this actuator keeps the mass at the joint low, which matters most at the end of a limb. Weight at the elbow or knee must be moved by the shoulder or hip, so a lighter module helps the whole chain.
The third is positioning. A 16bit encoder resolution and a repeat positioning accuracy of ≤0.1° give a developer a joint that returns to the same angle reliably. For work that repeats a motion many times, such as a manipulation test or a gait trial, this is the figure to watch.
How does the module handle heat and multi-joint control?
Compact actuators concentrate heat. Xynova addresses this with a built-in high-speed heat dissipation channel inside the compact structure, a design shared across the range. The aim is efficient running without the module overheating.
On the control side, a humanoid robot rarely moves one joint at a time. Xynova provides its own host-computer software and a rich set of API interfaces, designed so that many modules can be controlled in coordination. For a team building a whole arm or leg out of several actuators, that shortens the step between hardware on the bench and a coordinated movement. Ask us about the communication interface of this model when you request a quotation.
Who is the Xynova PR21-100-140-HS for?
Humanoid robot developers are the clearest match. A module with this torque and weight fits the joints that carry meaningful load but cannot afford bulk, such as the elbow, and, depending on the design, other limb joints. Teams that are still sizing their joints will want to compare it with the neighboring models in the Robot Actuators category.
Research laboratories and universities are another group. A compact module with a 16bit encoder and an API suits experiments in manipulation and control, where repeatability counts and where several joints must be driven together from one software environment.
Builders of custom robotic arms and prototype automation cells can also use it, especially where a 48V supply is already planned. Buyers who need a much stronger joint, for the waist or hip of a full-size humanoid, should look at the higher-torque siblings already mentioned above. Buyers who need a straight-line motion instead of a turning one may prefer a linear actuator from the same brand.
What is the Xynova PR21-100-140-HS used for?
- Humanoid robot joints. A compact, high-torque module for limb joints where weight at the joint must stay low.
- Robotic arm development. A turning axis for custom manipulators and research arms that need repeatable positioning.
- Multi-joint coordination. Several modules driven together through the manufacturer's software and API interfaces.
- Research platforms. A well-specified actuator for laboratory work on control, gait and manipulation.
- Education and training rigs. A real joint module for teaching mechatronics and robot motion on a bench.
- Prototype automation. A rotary axis for test cells and early-stage machines before a design is frozen.
Pricing and Availability
This actuator is sold by quotation, and no prices are shown on the page. Send us your quantity and project details, and we will prepare a quotation for you. Delivery, customs and support are arranged together with the quotation, so that you know the whole picture before you commit. The Xynova PR21-100-140-HS Rotary Actuator is available on this page.
Frequently Asked Questions
What voltage does the PR21-100-140-HS run on?
Its rated voltage is 48V. Plan your power supply and wiring around that figure.
How much torque can it deliver?
The peak torque is 140Nm. For the rated and continuous torque, ask us when you request a quotation.
How large and how heavy is it?
The module measures Φ100×61.7mm and weighs 1.2kg. Its torque density is 117Nm/kg.
How precise is the positioning?
The encoder resolution is 16bit and the repeat positioning accuracy is ≤0.1°.
What is its IP rating and operating temperature?
Ask us about both when you request a quotation, and tell us the environment the joint will work in.
Can I control several modules together?
Yes. Xynova develops its own host-computer software with rich API interfaces for coordinated control of multiple modules. Details of this model's communication interface come with the quotation.
Where can I buy the Xynova PR21-100-140-HS and what does it cost?
You can buy it through this page by requesting a quotation. The cost depends on quantity and project needs, and it is given in the quotation itself.
Summary
The Xynova PR21-100-140-HS Rotary Actuator answers the tension that every humanoid joint faces: strength against weight. With 140Nm of peak torque, 117Nm/kg of torque density, a 1.2kg body, a 16bit encoder and ≤0.1° repeat positioning accuracy, it gives developers a compact joint they can plan around. Its heat dissipation design and the manufacturer's software and API support make it practical to build into a multi-joint machine. For a quotation, or to settle the remaining details of the joint, this page is the starting point.


