
Xynova PR43-120-600-HB Rotary Actuator
In stock
- BRAND:
- XYNOVA
- MODEL:
- PR43-120-600-HB
- ORIGIN:
- China
- Warranty:
- 12 MONTHS
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- Xynova-PR43-120-600-HB
Xynova PR43-120-600-HB Rotary Actuator
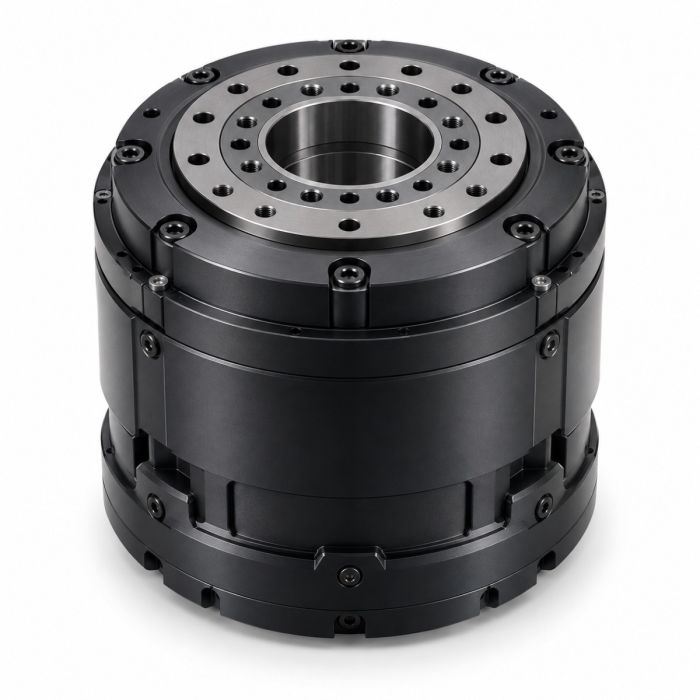
A humanoid robot is only as capable as its weakest joint, and every joint has to be strong, compact and light at the same time. The Xynova PR43-120-600-HB Rotary Actuator is built around that tension, packing a planetary gearbox and a torque density of 140Nm/kg into a body measuring Φ120×126mm.
The product is available through this page, by quotation.
Background
Xynova and its place in humanoid robotics
Xynova Technology Co., Ltd. is a core component supplier in the field of humanoid robots. Its business is not whole robots but the parts that make them move: the joints, the drive modules and the software that coordinates them. A supplier of that kind sits between research laboratories and the teams building walking, lifting and reaching machines, and it succeeds when its components can be dropped into many different designs.
Xynova develops two of the most important layers of its actuators itself. The gearbox is an in-house planetary design, and the upper-level control software is also written in-house. Keeping both under one roof means the mechanics and the control layer are designed to work with each other, rather than being assembled from unrelated parts. Other rotary models from the same maker include the PR64-110-500, the PR20-102-130-HS, the PR21-100-140-HS and the PRH19-57-25-HS, each suited to its own kind of joint.
Positioning and key technology of the PR43-120-600-HB
The PR43-120-600-HB is custom-designed for humanoid robots. That intended use shapes the design priorities: a humanoid has to carry its own actuators on its own limbs, so every gram and every millimeter counts. The figure that captures this best is torque density, which stands at 140Nm/kg.
The gearbox is a planetary design developed in-house and optimized for high-burst movements. Humanoid motion is rarely smooth and steady. A step, a jump, a catch or a sudden shift of balance asks a joint for a short, intense effort, and a gearbox tuned for that kind of duty suits the work better than one tuned only for slow, continuous rotation.
On the software side, the actuator works with Xynova's in-house upper-level software, which offers a rich set of API interfaces. Its purpose is to make it easy to coordinate and control multiple actuators, which matters because a humanoid has dozens of joints that must move together rather than one at a time.
Technical Specifications
| Specification | Value |
|---|---|
| Model | PR43-120-600-HB |
| No-load speed | 32r/min |
| Torque density | 140Nm/kg |
| Size | Φ120×126mm |
Specifications as published by the manufacturer; confirmed against the datasheet at quotation.
The manufacturer has not published the IP rating, the rated torque, the communication interface, the operating temperature, the rated current, the contents of the box or the backlash; they are confirmed at quotation.
What makes the PR43-120-600-HB different from a general-purpose actuator?
A general-purpose rotary actuator is designed to suit many jobs: conveyors, turntables, camera mounts, small machines. Such a unit is usually judged on steady output and price. The PR43-120-600-HB is judged on a different yardstick. It was custom-designed for humanoid robots, and its headline figure is not a raw output number but a ratio, torque per kilogram of actuator, at 140Nm/kg.
That ratio is what a humanoid designer asks about first. Every actuator in a leg or an arm has to be lifted by the actuators closer to the body, so a heavy joint costs more than its own weight. A compact body of Φ120×126mm, together with a high torque density, helps keep a limb manageable.
The second difference is the gearbox. The in-house planetary gearbox is optimized for high-burst movements, which describes the duty of a walking or jumping machine far better than continuous rotation. The third difference is the software. Instead of leaving the buyer to build a control layer from scratch, Xynova provides upper-level software with a rich set of API interfaces for coordinating several actuators together.
How does the no-load speed of 32r/min fit a humanoid joint?
A no-load speed of 32r/min is a deliberately modest figure. Humanoid joints are normally geared down to trade speed for torque, since a hip, knee or shoulder has to move a heavy limb rather than spin freely. The speed figure tells a designer how quickly the output shaft can turn when it carries nothing, which is the upper limit for the joint's motion.
Readers should treat this number as one input among several. A full motion-performance assessment of a joint needs more data than these three figures, and the quotation stage is the place to ask for it. The speed, the torque density and the size are, however, enough to begin a first fit check against a limb design.
Who is the Xynova PR43-120-600-HB Rotary Actuator for?
The first group is the teams building humanoid robots, whether in a company, a university or a start-up. For them, an actuator designed specifically for humanoid use saves the work of adapting a general part to a demanding job.
The second group is research laboratories studying legged locomotion, balance and manipulation. Rich API interfaces and software built for multi-actuator coordination are valuable when experiments call for many joints working together and for frequent changes of control strategy.
The third group is integrators and engineering teams who need a compact, high-density joint for a custom robotic project that is not strictly a humanoid. The intended use is humanoid robots, so describe your application when you ask for a quotation.
Buyers who need a different size or a different performance profile can look at the other rotary models in the family, such as the Xynova PR64-110-500 Rotary Actuator, the Xynova PR20-102-130-HS Rotary Actuator or the Xynova PRH19-57-25-HS Rotary Actuator, or browse the wider Robot Actuators category. Teams that need linear motion rather than rotation may consider the Xynova PRM10-20-18-200-F Linear Actuator.
What is the Xynova PR43-120-600-HB Rotary Actuator used for?
- Humanoid robot joints. The actuator was custom-designed for the joints of humanoid robots, where weight and size are limited.
- Dynamic movement. The planetary gearbox is optimized for high-burst movements, the kind of short, intense effort found in stepping and balance recovery.
- Multi-actuator coordination. The in-house software and its API interfaces make it easier to control several actuators as one system.
- Robotics research. Laboratories can use the actuator as a building block for experiments in locomotion and manipulation.
- Prototype development. Engineering teams can fit it into early limb designs to test how a compact, dense joint behaves in a real structure.
- Custom integration projects. Integrators can design it into bespoke robotic systems, with the remaining details settled at quotation.
Pricing and Availability
The Xynova PR43-120-600-HB Rotary Actuator is sold by quotation only. Send us your project details and quantity, and we will respond with a quotation. Delivery, customs and support are arranged together with the quotation, so you know how the order will reach you before you commit. The Xynova PR43-120-600-HB Rotary Actuator is available on this page.
Frequently Asked Questions
What is the Xynova PR43-120-600-HB Rotary Actuator?
It is a rotary actuator from Xynova, custom-designed for humanoid robots. It combines an in-house planetary gearbox with in-house control software.
What is its torque density?
The torque density is 140Nm/kg. This is the figure that shows how much torque the actuator delivers for its weight.
How large is the actuator?
The size is Φ120×126mm. Check this against the space available in your joint design before ordering.
What is the no-load speed?
The no-load speed is 32r/min. It describes how fast the output turns when it carries no load.
How is the actuator controlled?
Xynova provides in-house upper-level software with a rich set of API interfaces. It is designed to make coordination and control of multiple actuators easy.
Can the actuator be used outside humanoid robots?
It is custom-designed for humanoid robots. For any other application, send us your project details with your quotation request.
Where can I buy the Xynova PR43-120-600-HB Rotary Actuator and what does it cost?
You can request it through this page, and it is supplied by quotation. The cost is given in the quotation for your project, not listed here.
Summary
A humanoid joint has to be strong, light and small all at once, and the Xynova PR43-120-600-HB Rotary Actuator is designed around that balance. Its torque density of 140Nm/kg, its Φ120×126mm body, its in-house planetary gearbox for high-burst movements and its coordinating software make it a purposeful choice for humanoid builders and researchers. If you are planning a humanoid or advanced robotics project, this page is the starting point.


