
Xynova PRM10-20-18-200-F Linear Actuator
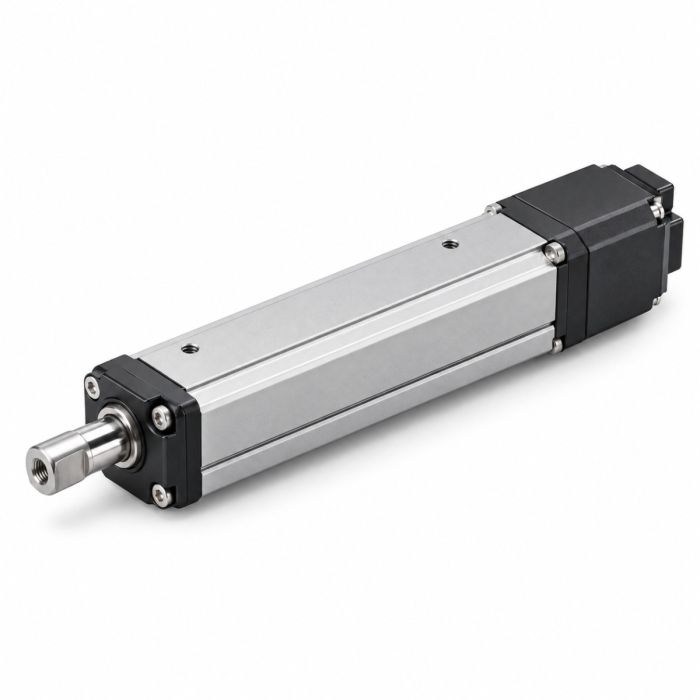
In stock
- BRAND:
- XYNOVA
- MODEL:
- PRM10-20-18-200-F
- ORIGIN:
- China
- Warranty:
- 12 MONTHS
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- Xynova-PRM10-20-18-200-F
Xynova PRM10-20-18-200-F Linear Actuator
A humanoid hand has very little room to hide a muscle. The Xynova PRM10-20-18-200-F Linear Actuator is built for that problem: a micro electric cylinder that fits into a space the size of a finger and still pushes with real force. For a design team, the question is rarely how strong an actuator is on paper. It is how much strength can be placed where the joint actually needs it.
The product is available through this page, by quotation.
Background
Xynova and its place in humanoid robotics
Xynova Technology Co., Ltd. is a core component supplier in the field of humanoid robots. That is a narrow and demanding niche. Humanoid platforms put actuators in the hands, wrists, arms and legs, and every one of those places has its own limits on size, weight and power draw. A supplier that focuses on this field designs its parts around those limits instead of adapting general industrial parts.
The PRM10 series is the micro cylinder family within the Xynova range. This version, PRM10-20-18-200-F, is one of several in the series, alongside PRM10-20-34-150-F, PRM10-20-47-100-F, PRM10-25-47-100-F, PRM10-20-64-75-F and PRM10-25-64-75-F. Each version carries its own figures, so the numbers on this page belong to PRM10-20-18-200-F only. Teams that also work with rotary joints can look at the wider Robot Actuators category.
Key technology: roller screw and hollow cup motor
Two in-house developments define this actuator. The first is a 7mm micro planetary roller screw. It greatly improves transmission efficiency and suits both industrial and everyday applications. Compared with a plain lead screw, a planetary roller screw spreads the load over many contact points. That is why it is chosen when a small cylinder has to carry a meaningful thrust.
The second is an in-house hollow cup motor. A hollow cup design uses a lightweight rotor without an iron core, which is a common route to a compact and responsive drive. Together, screw and motor give a cylinder that measures 10*13.5*84mm and weighs no more than 38g.
The actuator also offers easy joint self-locking for enhanced safety during operation, with no risk of power failure. For a robot limb, that matters: a joint that holds its position when the supply is lost is easier to design around and safer to handle.
Technical Specifications
| Specification | Value |
|---|---|
| Max thrust | ≥200N |
| Effective stroke | 19+1%mm |
| Size (L×W×H) | 10*13.5*84mm |
| No-load max speed | ≥18mm/s |
| Full-load speed | ≥4mm/s |
| Weight | ≤38g |
| Operating voltage | DC12±10%V |
| Repeatability | ±0.04mm |
| Operating temperature | -15~60℃ |
| Static current | 0.05A |
| No-load current | 0.4A |
| Screw type | In-house developed 7mm micro planetary roller screw |
| Motor | In-house developed hollow cup motor |
Specifications as published by the manufacturer; confirmed against the datasheet at quotation.
The manufacturer has not published the IP rating, the position feedback type, the communication interface, the connector type, the rated load, the lifespan, the package contents or the motor power; they are confirmed at quotation.
What makes the PRM10-20-18-200-F different from other PRM10 versions?
Within the PRM10 family, the part number tells a story about trade-offs. This version pairs a max thrust of at least 200N with an effective stroke of 19+1%mm and a no-load max speed of at least 18mm/s. In other words, it is the short, forceful kind of cylinder. A longer-stroke version gives a joint more travel, but travel and force compete for the same small body, and a designer has to pick which matters more.
If your joint needs a longer reach, the Xynova PRM10-20-34-150-F Linear Actuator is the sibling to ask about. Its figures are its own and are given on its page; we do not carry them over to this one. Asking about both lets you compare the two against your lever arm and your load.
The other difference is in how the force is delivered. The full-load speed is at least 4mm/s, against a no-load figure of at least 18mm/s. That gap is normal for a screw-driven cylinder: the actuator moves quickly when nothing resists it and slows when it works against a load. Planning a motion profile around the full-load figure is the safe approach, and it keeps the design honest.
How precise and how efficient is this actuator?
Repeatability is ±0.04mm. In a finger or a small gripper, that means the same command brings the joint back to the same place, cycle after cycle. This matters when a hand has to close on a part, or when several joints must act together to form a stable grip.
Electrical demand is also modest. The operating voltage is DC12±10%V, the static current is 0.05A and the no-load current is 0.4A. A low holding current is useful in a battery-powered humanoid, where every ampere is taken from a limited pack. The operating temperature range of -15~60℃ covers a laboratory bench and many working environments, but you should check it against the place where the robot will actually stand.
For a long-running program, do not assume motor power, rated load or lifespan from the thrust figure; plan your duty cycle with those open points in mind.
Who is the Xynova PRM10-20-18-200-F for?
The first buyer is the humanoid robot developer, whether a start-up building a full-body platform or a research group building a single hand. The cylinder was designed for humanoid robots, and its size and weight suit the tight spaces in fingers, wrists and forearms.
The second is the university or training laboratory. A small actuator with a known repeatability, a clear voltage and a self-locking joint makes a good basis for teaching mechatronics or testing a gripper concept before a full build.
The third is the integrator working on small automation prototypes, such as compact pushers, clamps or positioners where space is scarce. Here the short stroke is an advantage, not a limit. If your design needs more travel, consider the Xynova PRM10-20-34-150-F Linear Actuator instead. And if the joint should rotate rather than push, the rotary range, for example the Xynova PR20-102-130-HS Rotary Actuator, is the better fit.
What is the Xynova PRM10-20-18-200-F used for?
- Humanoid finger and hand joints. The compact body drives a finger link directly, without a long transmission.
- Wrist and forearm mechanisms. Low weight keeps the moving mass small, which helps the arm respond.
- Research on manipulation. A repeatability of ±0.04mm gives experiments a stable base for grasping studies.
- Small gripper and clamp prototypes. Self-locking helps hold a part when the supply drops.
- Education and laboratory platforms. A 12V class supply is simple to provide on a bench.
- Custom mechatronic integration. Any design that needs a small, precise push in a tight envelope can use it.
Pricing and Availability
We do not print prices on this page. Quotation is the way to buy: tell us the quantity, the application and the delivery location, and we reply with an offer. Delivery, customs and support are arranged together with the quotation, so you see the whole picture before you commit. The Xynova PRM10-20-18-200-F Linear Actuator is available on this page.
Frequently Asked Questions
What is the stroke of the PRM10-20-18-200-F?
The effective stroke is 19+1%mm.
How much thrust does it deliver?
The max thrust is at least 200N. The full-load speed is at least 4mm/s.
What supply voltage does it need?
The operating voltage is DC12±10%V. The static current is 0.05A and the no-load current is 0.4A.
Does the joint hold its position without power?
Yes. The actuator offers easy joint self-locking for enhanced safety during operation, with no risk of power failure.
How big and how heavy is it?
The size is 10*13.5*84mm and the weight is no more than 38g.
Is the IP rating or the communication interface known?
Not on this page. Add them to your quotation request, together with the connector type and the position feedback type.
Where can I buy the Xynova PRM10-20-18-200-F and what does it cost?
You can buy it through this page by requesting a quotation. We do not list a price here; the offer is prepared once we know your quantity and delivery location.
Summary
Strength in a humanoid is only useful when it fits inside the limb. The Xynova PRM10-20-18-200-F Linear Actuator answers that with a 7mm micro planetary roller screw, a hollow cup motor, a body of 10*13.5*84mm, a weight of no more than 38g, a max thrust of at least 200N and a repeatability of ±0.04mm. When you are ready to size this actuator into your design, this page is the starting point.


