
Linkerbot Linker Hand 06
In stock
- BRAND:
- LINKERBOT
- MODEL:
- LINKER HAND 06
- ORIGIN:
- China
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- Linkerbot-Linker-Hand-06
Linkerbot Linker Hand 06
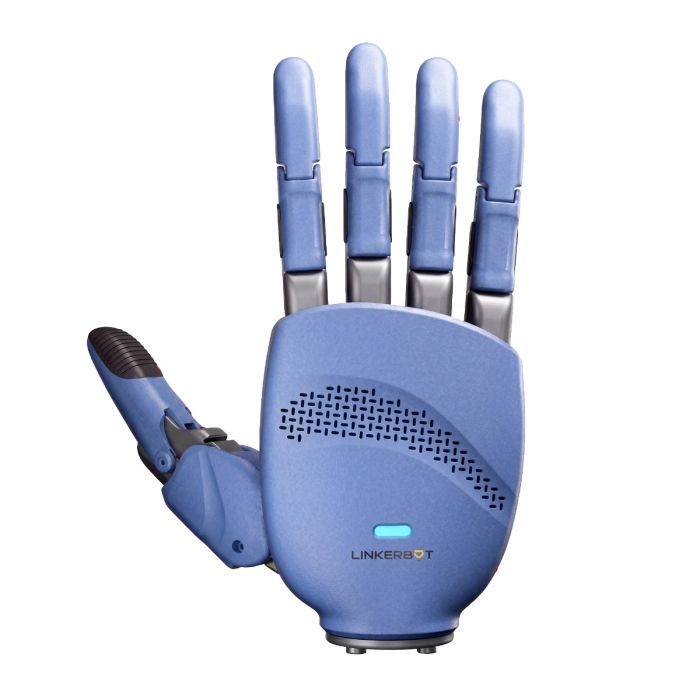
Most robot arms can reach almost anywhere, yet many of them still pinch at the end of the reach with two stiff jaws. The Linkerbot Linker Hand 06 addresses that last few centimeters with a five-finger hand that closes around an object the way a human hand does, while staying light enough to ride on the end of an arm or a mobile platform.
The Linkerbot Linker Hand 06 is available through this page, by quotation.
Background
The company and its lineage
Linkerbot, written LinkerBot in its own materials, describes itself as a global leader in dexterous hands. Its stated mission is to "create everything", and its work centers on embodied-intelligence solutions for dexterous manipulation. In other words, the company builds hands for machines that are meant to act in the physical world, not only to move through it.
The Linker Hand 06 sits in a wider family of Linkerbot hands. You can browse the maker's full range on the Linkerbot brand page, or compare it with other products in the Robot Hands category. The product is also written Linker Hand O6 in some literature, and both names point to the same hand.
Positioning and key technology
The Linker Hand 06 is built around six active degrees of freedom plus five passive degrees of freedom. Six motors drive the main motions, and the passive joints let the fingers follow the shape of whatever they close on. This is a practical middle path: more capable than a simple gripper, yet simpler to control than a hand with a motor for every joint.
Motion is carried by linkage transmission. Rigid links connect the drive to the finger segments, which gives the hand a direct, mechanical feel. The hand is offered in left and right versions, and with a choice of CAN or RS-485 interface, so a cell with two arms can be fitted with a matched pair.
Technical Specifications
| Specification | Value |
|---|---|
| Degrees of freedom | 6 active + 5 passive |
| Transmission | Linkage transmission |
| Control interface | CAN / CAN FD / RS485 / ECAT |
| Weight | 360g |
| Maximum load | 50kg |
| Operating voltage | 24V-48V |
| Repeat positioning accuracy | <±0.20mm |
| Tactile sensor | Optional |
| Maximum thumb fingertip force | 20N |
| Maximum four-finger fingertip force | 25N |
| Maximum five-finger grip force | 70N |
| Four-finger bending angle | 1.61rad (92.59°) |
| Thumb side-swing speed | 1.36rad/s (78.10°/s) |
| Four-finger bending speed | 1.30rad/s (74.75°/s) |
| Thumb bending speed | 0.66rad/s (38°/s) |
Specifications as published by the manufacturer; confirmed against the datasheet at quotation.
The manufacturer has not published the static current, the IP rating, the operating temperature, the tactile sensor resolution or the dimensions with wrist flange; they are confirmed at quotation.
What makes the Linker Hand 06 different from a simple gripper?
A parallel-jaw gripper is excellent when every part is the same shape and arrives in the same place. It struggles when the next item is round, the one after is irregular, and a third needs to be held by its handle. A five-finger hand spreads the contact over several fingers and a thumb, so the grasp adapts to the object instead of the object being fixtured for the gripper.
The figures show how the Linker Hand 06 does this. The thumb has its own side-swing, at 1.36rad/s (78.10°/s), and its own bending motion, at 0.66rad/s (38°/s). That separate thumb is what allows opposition, the pinch between thumb and fingers that makes a hand useful. The four fingers bend through 1.61rad (92.59°) at 1.30rad/s (74.75°/s), which is quick enough for cycle-conscious work.
Force is stated clearly. The thumb fingertip reaches a maximum of 20N, the four-finger fingertip 25N, and the five-finger grip 70N. The maximum load is 50kg. At 360g the hand adds little weight to the wrist, which matters for collaborative arms and mobile platforms, where every gram at the end of the arm counts.
How does the Linker Hand 06 connect and get its power?
The control interface list covers CAN, CAN FD, RS485 and ECAT, the usual buses of industrial and embedded robotics. An integrator can usually reuse the bus already running in the cell instead of adding another one. The hand is offered with a CAN or an RS-485 interface.
The operating voltage is 24V-48V, which suits common robot power supplies. Repeat positioning accuracy is below ±0.20mm, so the same grasp can be repeated from cycle to cycle. A tactile sensor is optional; when your task needs touch feedback, ask for it in your quotation request.
Who is the Linker Hand 06 for?
Research labs are the clearest fit. A hand with six active degrees of freedom gives students and researchers a real platform for studying grasping, teleoperation and manipulation learning, without the demands of a hand that has a motor for every joint.
Integrators building automation cells for assembly, packing or picking can use it where parts vary too much for a simple gripper. Developers of humanoid and mobile manipulation robots will value the 360g weight and the choice of left or right version.
If your task calls for a different finger count or drive principle, the family includes other models, such as the Linker Hand L10 Standard Version, the Linker Hand L20 Pro Version and the Linker Hand 07. Our team can help you compare them against your application.
What is the Linker Hand 06 used for?
- Research and teaching. A dexterous platform for grasping studies, teleoperation and learning-based manipulation.
- Assembly assistance. Picking up and placing mixed parts where one fixed gripper cannot cope.
- Logistics picking. Handling items of different shapes from bins and shelves.
- Humanoid robots. A light hand for the end of a humanoid arm, in left or right form.
- Mobile manipulation. Opening, lifting and carrying with a hand mounted on a moving base.
- Tactile experiments. Work with the optional tactile sensor, where touch feedback is part of the task.
Pricing and Availability
Pricing for the Linker Hand 06 depends on the version, the interface and whether the optional tactile sensor is included, so we quote each request individually. Send us your application, your arm or platform and your preferred interface, and we will reply with a quotation. Delivery, customs and support are arranged together with the quotation. The Linkerbot Linker Hand 06 is available on this page.
Frequently Asked Questions
How many degrees of freedom does the hand have?
It has 6 active degrees of freedom and 5 passive degrees of freedom. The six active ones are motor driven, while the passive ones let the fingers adapt to the object.
Which control interfaces are supported?
The listed control interfaces are CAN, CAN FD, RS485 and ECAT. Versions with a CAN interface and with an RS-485 interface are offered.
What power supply does it need?
The operating voltage is 24V-48V, which suits common robot power supplies.
How much can it grip and carry?
The maximum five-finger grip force is 70N, and the maximum load is 50kg. The maximum fingertip force is 20N for the thumb and 25N for the four fingers.
Is there a left and a right hand?
Yes. The Linker Hand O6 comes in Left and Right versions, so a two-arm setup can be fitted with a matched pair.
Does it have tactile sensing?
A tactile sensor is optional and can be requested together with your quotation.
Where can I buy the Linkerbot Linker Hand 06 and what does it cost?
You can request it through this page, and we answer with a quotation. The cost depends on the version, the interface and the options you choose.
Summary
The Linker Hand 06 takes a robot arm past the stiff pinch of a two-jaw gripper. It has a separate thumb, four bending fingers, linkage transmission, a choice of CAN or RS-485 interface and a weight of 360g. For labs, integrators and humanoid builders who want a capable hand without unnecessary complexity, this page is the starting point.


