
Dobot Atom Max Full-Size Embodied Al Humanoid Robot
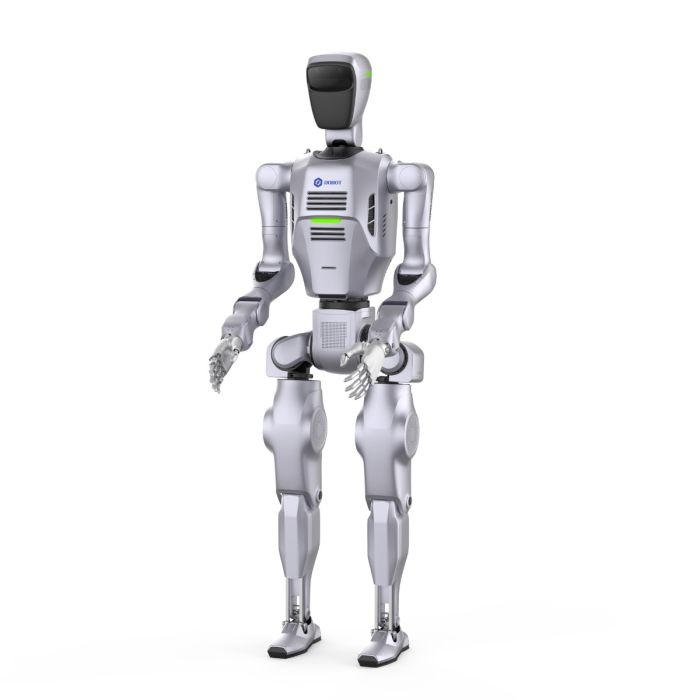
In stock
- BRAND:
- DOBOT
- MODEL:
- ATOM MAX
- ORIGIN:
- China
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- Dobot-Atom-Max
Dobot Atom Max Full-Size Embodied Al Humanoid Robot
Most humanoid robots walk like someone wading through water, knees bent and batteries draining. The Dobot Atom Max Full-Size Embodied Al Humanoid Robot takes a different route: it walks with straight knees and pairs that gait with hands built for fine work. It is a machine made for the bench, the assembly cell and the research lab, not for the stage.
This product is available through this page, by quotation.
Background
Dobot and the Atom line
DOBOT is a robotics company known for desktop and collaborative robot arms, and the Atom series carries that experience into humanoid form. The Atom is the world's first full-sized humanoid robot that combines dexterous manipulation with straight-knee walking. Two ideas sit behind that sentence: hands that can do real work, and legs that do not waste energy.
The series has more than one member. The Atom Max described here is one version, and the Atom D, a data-collection version, is the other. Each has its own figures, and this page keeps the Atom Max figures with the Atom Max.
Positioning and key technology
The Atom Max is a 41-DoF humanoid robot designed for advanced robotics research and industrial applications. Three systems define it. The first is the Neuro-Driven Dexterity System (NDS), which controls 28 upper-body degrees of freedom through a Transformer-based architecture and binocular RGB vision. The second is the Anthropomorphic Walking System (AWS), which governs the straight-knee gait. The third is a 1500 TOPS AI module that provides real-time edge computing.
On top of these, the Atom Max adds VR/MR teleoperation with markerless tracking. An operator can drive the robot in two control modes, full-body or segmented. That makes the robot useful both as an autonomous platform and as a tool for gathering demonstration data.
Technical Specifications
| Specification | Value (ATOM Max) |
|---|---|
| Height | ≈1650mm |
| Weight (without dexterous hands/jaws) | ≈62kg |
| Overall degrees of freedom | 41 |
| Full-body degrees of freedom (without dexterous hands/jaws) | 29 |
| Upper-body degrees of freedom controlled by NDS | 28 |
| Dexterous hands | 6-DoF |
| Single arm load (without dexterous hand/gripper) | 3.5kg |
| Single arm repeatability | ± 0.05mm |
| Maximum walking speed | 1.5m/s |
| Battery life | ≈2h |
| Control frequency | 200Hz |
| AI module | 1500 TOPS |
| Head sensors | RGB-D Camera x1 + Full HD Binocular Camera x1 |
| Vision system | 60FPS Full HD |
| Depth sensing | Intel RealSense D455 |
| Workstation heights handled | 700-1000mm |
Specifications as published by the manufacturer; confirmed against the datasheet at quotation.
The manufacturer has not published the IP rating, the operating temperature range, the operating system, the maximum payload of the hands, the charging input voltage or the connectivity options; they are confirmed at quotation.
What makes the straight-knee gait different from ordinary humanoid walking?
Traditional humanoids keep their knees bent while they walk. That posture is stable, but the leg muscles, or in a robot the leg motors, work against gravity at every step. The Anthropomorphic Walking System reduces energy consumption by 42% compared with traditional bent-knee walking. That adds stability and endurance for continuous operation in industrial environments.
The practical effect shows in places where a robot must work, not just move. The system is built for narrow spaces and for workstation heights from 700 to 1000mm. A humanoid that stands and walks more like a person can fit into layouts built for people. With a battery life of about 2 hours and a top walking speed of 1.5m/s, the energy savings of the gait matter to anyone planning a shift of work.
How does the Atom Max handle fine manipulation?
A humanoid is only as useful as its hands. The Atom Max carries dexterous 6-DoF hands, and the Neuro-Driven Dexterity System coordinates 28 upper-body degrees of freedom. The control loop runs at 200Hz, with servo-level vibration suppression. The intended result is smooth, human-like fine motor skills for tool use, assembly and multi-specification handling.
Vision supports the hands. The head carries an RGB-D camera and a Full HD binocular camera, and the vision system runs at 60FPS Full HD with Intel RealSense D455 depth sensing. Each arm repeats its positioning to ± 0.05mm and carries a 3.5kg load without a hand or gripper fitted. Teams planning a grasping task should keep that last figure in mind.
Who is the Dobot Atom Max Full-Size Embodied Al Humanoid Robot for?
University and corporate research labs are the first group. They need a full-size body with open development paths, and the optional Embodied AI Set supplies high-precision URDF models, an open-source training framework and multi-modal data tools. Industrial innovation teams are the second group. They want to test a humanoid at real workstation heights before committing to a larger program.
Integrators and system developers form the third segment. The edge computing system supports multi-robot collaboration and delivers 7.7x industry-standard computational power, so a small fleet is a realistic goal. Teams that mainly want to collect manipulation data from the upper body, and do not need walking, may prefer the Dobot Atom D Upper Body Humanoid Robot. Those who prefer a rolling base can look at the Dobot ATOM-W Wheeled Humanoid Robot. Broader options are collected in our Humanoid Robots category.
What is the Dobot Atom Max used for?
- Embodied AI research. Train and test models on a full-size body, using the optional URDF models and open-source training framework.
- Teleoperated data collection. Record human demonstrations through VR/MR teleoperation with markerless tracking, in full-body or segmented mode.
- Assembly and tool use. Apply the dexterous hands and 200Hz control to tasks that need fine motor skill.
- Multi-specification handling. Work with differently sized items at stations between 700 and 1000mm high.
- Industrial pilot projects. Evaluate straight-knee walking in narrow spaces and continuous-operation settings.
- Multi-robot collaboration trials. Link several robots through the edge computing system to study shared tasks.
Pricing and Availability
We do not publish prices on this page. A quotation is the way to proceed, and it is where configuration choices such as the optional Embodied AI Set are settled. Delivery, customs and support are arranged together with the quotation. Requests for the Dobot Atom Max Full-Size Embodied Al Humanoid Robot are handled through the quotation process, and the robot is available on this page.
Frequently Asked Questions
How many degrees of freedom does the Atom Max have?
The Atom Max is a 41-DoF humanoid robot. Without the dexterous hands or jaws, the full-body count is 29, and the hands are 6-DoF each.
How tall is the robot and how much does it weigh?
The height is about 1650mm. The weight is about 62kg without the dexterous hands or jaws.
How long does the battery last?
Battery life is about 2 hours. The walking system is designed to cut energy use, which helps over a working session.
What AI computing power does it carry?
The Atom Max is powered by a 1500 TOPS AI module for real-time edge computing. The edge system also supports multi-robot collaboration.
Can it be teleoperated?
Yes. The Atom Max adds VR/MR teleoperation with markerless tracking and two control modes, full-body and segmented.
What is the Embodied AI Set?
It is an optional package with high-precision URDF models, an open-source training framework and multi-modal data tools. It is meant to speed up development work.
Where can I buy the Dobot Atom Max and what does it cost?
You can request it through this page, by quotation. The cost is given in the quotation, together with delivery, customs and support arrangements.
Summary
The Atom Max sets out to solve two problems that hold humanoids back: tiring legs and clumsy hands. Straight-knee walking cuts energy use by 42% against bent-knee walking, and a 200Hz dexterity system drives 6-DoF hands with 28 upper-body degrees of freedom coordinated. Add a 1500 TOPS AI module, teleoperation and an optional development kit, and the result is a serious platform for research and industrial trials. If that fits your project, this page is the starting point.


