
Dexforce W1 Pro General Purpose Embodied Intelligence Wheeled Humanoid Robot (W1 Pro)
In stock
- BRAND:
- DEXFORCE
- PART #:
- W1 Pro
- ORIGIN:
- China
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- DexForce-W1-Pro
Dexforce W1 Pro General Purpose Embodied Intelligence Wheeled Humanoid Robot (W1 Pro)
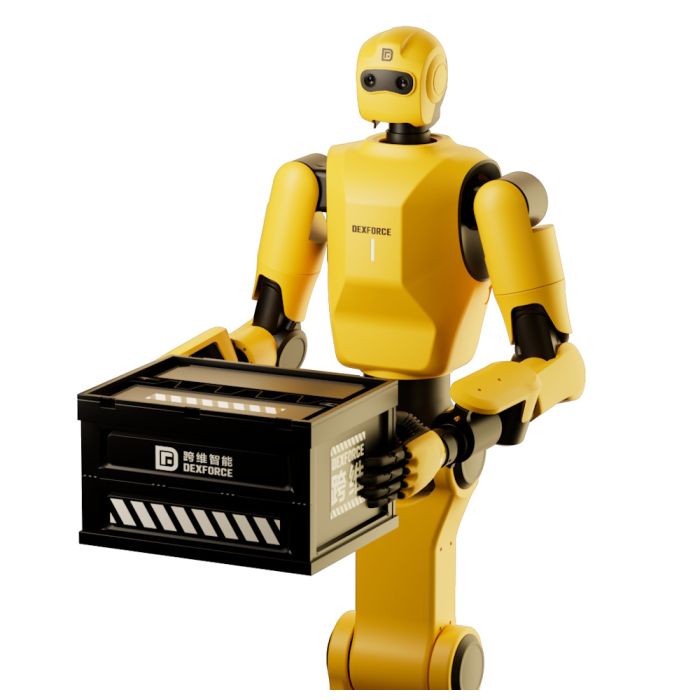
A wheeled humanoid makes a plain bargain: it gives up the legs and keeps everything else. The Dexforce W1 Pro General Purpose Embodied Intelligence Wheeled Humanoid Robot (W1 Pro) puts two seven-joint arms, a turning neck, a bending waist and a pair of stereo eyes on a rolling base. The engineering effort goes into reaching, seeing and handling objects rather than into balancing on two feet.
The product is available through this page, by quotation.
Background
The company and its lineage
DexForce builds robots around the idea that the body and the learning software should be designed together. The W1 Pro belongs to the company's W1 family of wheeled humanoids. Its sibling, the Dexforce W1 Core General Purpose Embodied Intelligence Wheeled Humanoid Robot, shares the family name, and both sit in the Wheeled Humanoids category.
The software side matters as much as the hardware. The W1 Pro is paired with a Sim2Real VLA pipeline, which generates and trains on massive amounts of data online through EmbodiChain. In practice, a team can teach skills in simulation and then carry them onto a physical machine. The robot is the real-world end of that pipeline.
Positioning and key technology
The W1 Pro is a general-purpose platform, not a single-task machine. It is meant for organizations that want one body to learn many jobs, and that want to adjust the hardware to the job. The optional components show this: a dexterous hand or a two-finger gripper, a humanoid or industrial-like robotic arm, a differential or omnidirectional mobile chassis, and a dual-PC configuration.
Several technologies carry the design. Head vision uses a 6cm baseline humanoid binocular setup with a large-model binocular algorithm. Navigation uses laser SLAM, with 2 pcs of LiDAR mounted diagonally on the chassis. Control runs at 1000Hz in real time across the full-body joints, and the joints are linked by an EtherCAT industrial ring network. Total system computing power is ≥ 300 TOPS. Together these give the robot room to run perception, planning and motion on the machine itself.
Technical Specifications
| Specification | Value |
|---|---|
| Dimensions (L×W×H) | 682mm*550mm*1636mm |
| Weight | 110kg |
| Full-body DOF, differential chassis | 34 DOF |
| Full-body DOF, omnidirectional chassis | 40 DOF |
| Single arm DOF | 7 DOF (Shoulder: 3; elbow: 1; wrist: 3) |
| Max payload (single arm) | 10kg |
| Arm repeatability (without hand) | ±0.5 mm |
| Torso DOF | Neck: 2 DOF, Waist: 2 DOF, Leg: 2 DOF |
| Chassis DOF | 8 DOF for omnidirectional chassis, 2 DOF for differential chassis |
| Straight-line speed | td>Max 1.5m/s, Rated 1.2m/s|
| Movement mode | Differential (Optional: Omnidirectional) |
| Navigation method | Laser SLAM |
| Navigation LiDAR | 2 pcs (Diagonally mounted on chassis) |
| Head vision | 6cm Baseline Humanoid Binocular Vision + Large-Model Binocular Algorithm |
| Battery life | ≥8H Continuous Power Supply (Wired) |
| Battery capacity | 40 Ah Optional: LiFePO4 Battery (40 Ah) |
| Computing power | Total system computing power ≥ 300 TOPS |
| Control frequency | 1000Hz real-time control of full-body joints |
| Force control precision | 0.1N |
| Industrial network | EtherCAT industrial ring network |
| Software engine | Sim2Real VLA Pipeline: Massive data online gen & training (via EmbodiChain) |
Specifications as published by the manufacturer; confirmed against the datasheet at quotation.
The manufacturer has not published the IP rating, the charging time, the operating temperature, the package contents, the Wi-Fi and Bluetooth support or the noise level; they are confirmed at quotation.
What makes the W1 Pro different from a legged humanoid?
The first difference is the base. A legged humanoid must spend much of its power, computing and design time on staying upright. The W1 Pro uses a wheeled chassis with a leg joint pair in the torso, so the base is steady and the work can go into the upper body. The straight-line speed is a max of 1.5m/s and a rated 1.2m/s, which suits indoor work that is measured in careful steps rather than sprints.
The second difference is how the machine is built to feel what it touches. The force control precision is 0.1N, and the joints are controlled at 1000Hz in real time. Each arm has 7 DOF, split into 3 at the shoulder, 1 at the elbow and 3 at the wrist, and repeatability without a hand is ±0.5 mm. Each arm can carry a max load of 10kg. For tasks such as picking, placing, handing over and operating equipment, these figures describe a body made for contact with the real world.
The third difference is vision first. The head carries a 6cm baseline binocular system, and the navigation chassis adds two LiDAR units mounted diagonally. The robot sees with its eyes for manipulation and uses laser SLAM for moving through a space.
What does the chassis choice change?
The W1 Pro comes with a differential chassis as standard, with an omnidirectional chassis as an option. The choice changes the degrees of freedom. With the differential chassis the full body has 34 DOF, of which the chassis contributes 2. With the omnidirectional chassis the full body has 40 DOF, of which the chassis contributes 8.
A differential base is the simpler choice and works well in aisles, corridors and open floors. An omnidirectional base suits tighter rooms where sideways motion and small corrections matter. Each figure belongs to its own chassis, so a project should settle the chassis early and then plan the application around it.
Who is the W1 Pro for?
Research labs and universities are the first group. The Sim2Real VLA pipeline, the computing power of ≥ 300 TOPS and the open choice of hand, arm and chassis let a lab shape the platform around its question. Integrators are the second group. The EtherCAT ring network and the dual-PC option are the kind of features they look for when building a cell or a service solution.
Commercial operators are the third group, particularly those exploring front-of-house or customer-facing tasks. Businesses in this field can also browse the Retail Robots category for related equipment. Teams that want a lighter entry into the same family can look at the Dexforce W1 Core and compare it with the W1 Pro when they request a quotation.
What is the W1 Pro used for?
- Embodied AI research. A physical body for testing policies trained in simulation through the Sim2Real VLA pipeline.
- Manipulation development. Two 7 DOF arms with a 10kg single-arm max load and a choice of dexterous hand or two-finger gripper.
- Service and reception tasks. A humanlike upper body with a moving neck and binocular vision for work among people.
- Indoor navigation tasks. Laser SLAM and two chassis-mounted LiDAR units for moving between work points.
- Industrial cell trials. EtherCAT ring networking and 1000Hz joint control for integration with automation systems.
- Teaching and demonstration. A full-size humanoid platform for training students and showing what embodied intelligence can do.
Pricing and Availability
The W1 Pro is offered by quotation, and the configuration decides the scope: chassis, hand or gripper, arm type and computing setup. Delivery, customs and support are arranged with the quotation. Send us your application and the options you want, and the Dexforce W1 Pro General Purpose Embodied Intelligence Wheeled Humanoid Robot (W1 Pro) is available on this page.
Frequently Asked Questions
How many degrees of freedom does the W1 Pro have?
The full body has 34 DOF with the differential chassis and 40 DOF with the omnidirectional chassis. Each arm has 7 DOF, and the neck, waist and leg have 2 DOF each.
How much can each arm carry?
The max load is 10kg per single arm. Arm repeatability without a hand is ±0.5 mm.
How does the robot navigate?
It uses laser SLAM, with 2 pcs of LiDAR mounted diagonally on the chassis. Head vision is a 6cm baseline binocular system with a large-model binocular algorithm.
How long does the battery last?
The battery life is ≥8H of continuous power supply (wired). The battery capacity is 40 Ah, with a LiFePO4 battery (40 Ah) as an option.
Can the hands and chassis be changed?
Yes. Options include a dexterous hand or a two-finger gripper, a humanoid or industrial-like robotic arm, a differential or omnidirectional chassis, and a dual-PC configuration.
How fast does the control loop run?
Full-body joints are controlled in real time at 1000Hz over an EtherCAT industrial ring network. Force control precision is 0.1N.
Where can I buy the W1 Pro and what does it cost?
You can request it through this page. The cost depends on the configuration you choose and is given in a quotation, which also covers delivery, customs and support.
Summary
The W1 Pro keeps the parts of a humanoid that do the work, the arms, neck, waist and eyes, and puts them on a stable wheeled base. The 10kg single-arm load, the 0.1N force control precision, the 1000Hz joint control and the ≥ 300 TOPS of computing power make it a serious platform for embodied AI, and the Sim2Real pipeline connects it to simulation. If that profile matches your project, this page is the starting point.


