
Dexrobot 021MP High-DOF,Multi-Modal,Perceptive Intelligent General-Purpose Dexterous Hand (021MP)
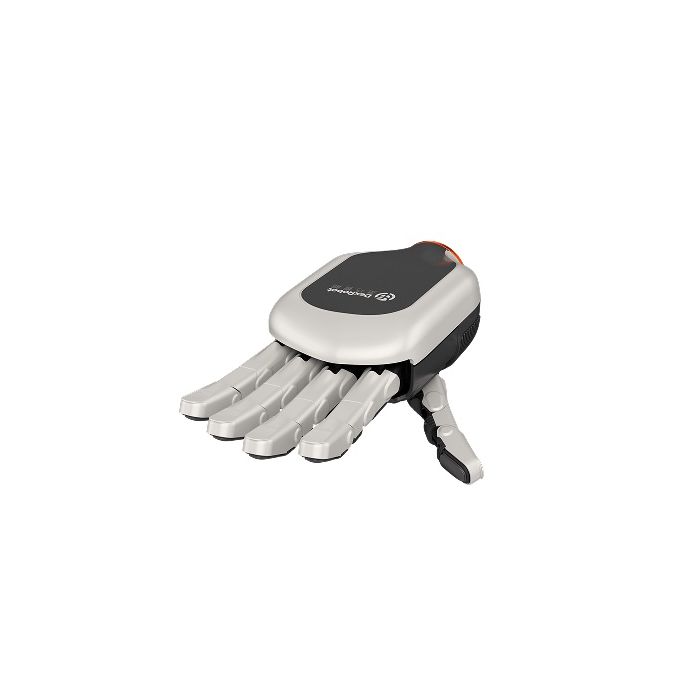
In stock
- BRAND:
- DEXROBOT
- PART #:
- 021MP
- ORIGIN:
- China
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- DexRobot-021MP
Dexrobot 021MP High-DOF,Multi-Modal,Perceptive Intelligent General-Purpose Dexterous Hand (021MP)
We rarely notice how much a human hand does until we try to build one. The Dexrobot 021MP High-DOF,Multi-Modal,Perceptive Intelligent General-Purpose Dexterous Hand (021MP) takes on that problem with a tendon-driven, five-finger design that senses what it touches as well as moving like a hand. For teams that have outgrown simple two-finger grippers, it is a practical way to start working on real manipulation.
The Dexrobot 021MP is available through this page, by quotation.
Background
The company and the DexHand021 family
DEXROBOT builds dexterous hands for research labs, humanoid robot developers and automation teams. Its DexHand021 line is sold in several versions: DexHand021 Mass Production (MP), DexHand021 S, DexHand021 Pro and DexHand021 Concept. The 021MP described on this page is the Mass Production version, which the manufacturer calls its flagship product.
Having several versions lets a buyer match the hand to the job. The Mass Production version is the one built around the full set of 19 degrees of freedom and five perception capabilities. It is also described as easy to maintain, highly compatible with other systems, and well suited to teaching and research. The other versions are covered on their own pages, and we link to them below where they fit a particular buyer better.
Positioning and key technology
The 021MP is a general-purpose hand. It is not tuned to one task such as pick-and-place of a single part. It is meant for the wide range of objects a person handles without thinking, and for teams exploring how a robot can do the same.
Three ideas define it. First, a rope-driven bionic design with tendon-driven transmission enables anthropomorphic dexterous manipulation across 19 degrees of freedom. Second, 23 integrated sensors give the hand multi-modal perception: position, temperature, multi-dimensional force and proximity. Third, the architecture is open. Low-level API access lets developers write their own tactile algorithms, and the manufacturer provides the DexTac simulation framework and the DexCanvas datasets to work with.
You can browse related hardware in our Robot Hands category, or see the full range from this maker under DexRobot.
Technical Specifications
| Specification | Value |
|---|---|
| Degrees of freedom | 19 DoF |
| Weight | 1 kg |
| Dimensions | 292.6mm * 113.2mm * 56.5mm |
| Transmission | Tendon-driven |
| Repeatability | ± 0.15 mm |
| Fingertip force | ≥ 12 N |
| Grasping force | ≥ 38 N |
| Total hand load | 5 kg |
| Voltage | DC 24 V |
| Max current | 7.4 A |
| Communication | CAN FD |
| Lifespan | > 1,000,000 cycles |
| Cooling | 2.38 cfm cooling capacity, active cooling design |
| Integrated sensors | 23 (position, temperature, multi-dimensional force, proximity) |
| Normal force sensing | Range 0 - 20 N, resolution 0.1 N, accuracy ± 2% F.S. |
| Minimum grasp diameter | ≥ 10 mm |
| Development frameworks | Python / C++ / ROS Integration |
Specifications as published by the manufacturer; confirmed against the datasheet at quotation.
The manufacturer has not published the ingress protection rating, the operating temperature range, the finger joint range of motion, the operating noise level or the power consumption in watts; they are confirmed at quotation.
What makes the 021MP different from a simple gripper?
A parallel gripper opens and closes. That is enough for boxes and bolts, but it cannot turn a pen between the fingers, adjust its hold on a slipping cup or pick up a small, awkward part. The 021MP has 19 degrees of freedom in a rope-driven bionic design, so its fingers can take up the many postures that humanlike manipulation needs.
The second difference is feedback. A hand that cannot feel is working blind, and its operator has to guess at contact. The 021MP carries 23 integrated sensors covering position, temperature, multi-dimensional force and proximity. Its normal force sensing covers a range of 0 - 20 N at a resolution of 0.1 N, with accuracy of ± 2% F.S. This gives control software real contact data to work from, whether it runs a simple grasp routine or a learned policy.
The third difference is how open the platform is. Low-level API access means you are not locked into the vendor's own grasp logic. If your group is developing tactile algorithms, you can build them on this hand directly. Python, C++ and ROS integration are supported, and the DexTac simulation framework and DexCanvas datasets give you material to start with before the hardware arrives.
How does the 021MP cope with continuous work?
Research hands often fail in the unglamorous ways: heat, wear and downtime. The 021MP addresses these directly. An active cooling design with 2.38 cfm of cooling capacity is specified for 7 x 24 h continuous and stable operation, and the lifespan is rated at more than 1,000,000 cycles. The manufacturer also describes the hand as easy to maintain, which matters when many students or engineers share one unit.
On the electrical side, the hand runs on DC 24 V with a maximum current of 7.4 A and communicates over CAN FD. Those are common values in robot cells, so integration with an existing power supply and controller is usually straightforward. Your integrator can confirm the details at quotation.
Who is the Dexrobot 021MP for?
University labs and teaching programs are the clearest fit. The hand is described as ideal for teaching and research, and the open API, simulation framework and datasets suit students who need to see inside the system rather than treat it as a black box.
Humanoid robot developers are the second group. A hand with 19 degrees of freedom, a total hand load of 5 kg and a weight of 1 kg gives a humanoid platform a capable end effector without overwhelming the wrist and arm.
Automation and prototyping teams form the third group. If you are testing whether a task can be done with humanlike grasping before committing to a fixed tool, the 021MP lets you try many objects with one piece of hardware. Its minimum grasp diameter of ≥ 10 mm covers small items.
Not every buyer needs this version. If your work centers on a wrist-and-hand combination, look at the Dexrobot 021PRO Wrist-Hand Integrated Dexterous Hand (021PRO). If a three-fingered layout is enough for your task, see the Dexrobot 021S High-Function Three-Fingered Dexterous Hand (021S). For an early look at the design direction, there is the Dexrobot 021 Concept Version Intelligent General-Purpose Dexterous Hand (021 Concept). Figures on this page belong to the Mass Production version only.
What is the Dexrobot 021MP used for?
- Teaching robotics. Students work with a real multi-sensor hand and its open API instead of a simulation alone.
- Dexterous manipulation research. Labs study in-hand manipulation with tendon-driven fingers and multi-dimensional force feedback.
- Tactile algorithm development. Low-level API access supports custom tactile algorithms tested on live sensor data.
- Humanoid robot end effectors. The hand gives humanoid platforms a five-finger tool for everyday objects.
- Prototype automation cells. Teams test humanlike grasping on varied parts before fixing a production design.
- Long-running experiments. Active cooling and the rated lifespan suit data collection and repeated trials around the clock.
Pricing and Availability
We do not list prices for the Dexrobot 021MP. Send us a request for quotation with your application, quantity and destination, and we will respond with a proposal. Delivery, customs and support are arranged with the quotation. The Dexrobot 021MP is available on this page.
Frequently Asked Questions
How many degrees of freedom does the Dexrobot 021MP have?
It has 19 DoF, in a rope-driven bionic design that enables anthropomorphic dexterous manipulation.
What sensors does it include?
It has 23 integrated sensors for multi-modal perception, including position, temperature, multi-dimensional force and proximity. Normal force sensing covers 0 - 20 N at a resolution of 0.1 N.
How does it connect and what power does it need?
It communicates over CAN FD and runs on DC 24 V, with a maximum current of 7.4 A.
Which software tools can I use?
Python, C++ and ROS integration are supported. Low-level API access is open, and the manufacturer provides the DexTac simulation framework and DexCanvas datasets.
How much can the hand hold and lift?
The grasping force is ≥ 38 N, the fingertip force is ≥ 12 N and the total hand load is 5 kg. The minimum grasp diameter is ≥ 10 mm.
Can it run continuously?
Yes. The active cooling design, with 2.38 cfm of cooling capacity, is specified for 7 x 24 h continuous and stable operation, and the lifespan is rated at more than 1,000,000 cycles.
Where can I buy the Dexrobot 021MP and what does it cost?
You can request it through this page, and the cost is given in a quotation prepared for your project. Delivery, customs and support are arranged at the same time.
Summary
The Dexrobot 021MP answers a simple question: what would a robot hand need to have in order to handle the objects people handle every day? The manufacturer's answer is 19 degrees of freedom, 23 sensors that tell the hand what it is touching, a tendon-driven build made for continuous running, and an open platform of software and data for developers. It suits labs, humanoid developers and prototype teams that want a hand that feels as well as moves. If that describes your project, this page is the starting point.


