
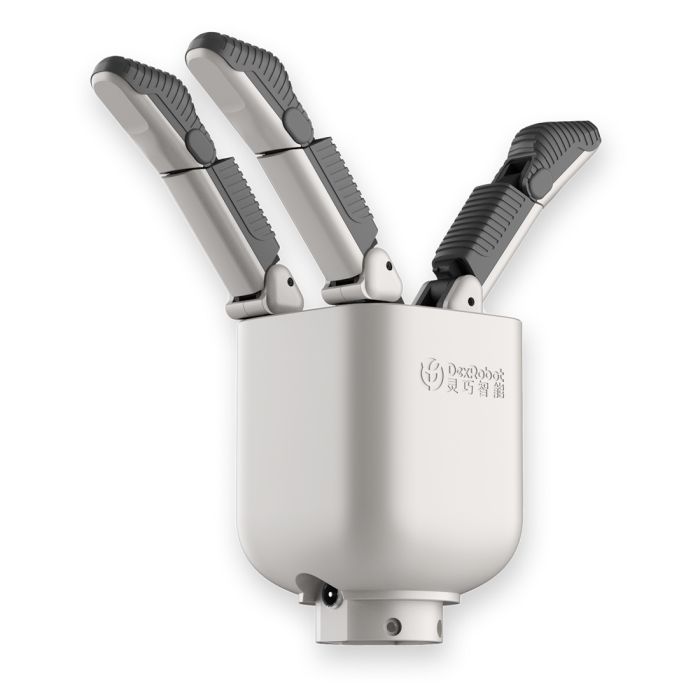
Dexrobot 021S High-Function Three-Fingered Dexterous Hand (021S)
In stock
- BRAND:
- DEXROBOT
- PART #:
- 021S
- ORIGIN:
- China
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- DexRobot-021S
Dexrobot 021S High-Function Three-Fingered Dexterous Hand (021S)
Most robot arms are asked to do delicate work with a hand that was never built for it. The Dexrobot 021S High-Function Three-Fingered Dexterous Hand (021S) takes the opposite approach: three fingers, carefully engineered, aimed at the grasps a work cell actually repeats all day.
The product is available through this page, by quotation.
Background
Dexrobot and the DexHand021 family
Dexrobot builds dexterous robot hands for research groups, integrators and industrial teams. Its DexHand021 line is sold in several versions: the DexHand021 S described here, the S-T, the MP, the Pro and the Concept. Each version addresses a different balance of reach, sensing and integration, and the figures of one are never those of another. This page covers the S version only.
The 021S is the entry point of that family. It is a highly functional three-finger dexterous hand that achieves 80% of core hand functions at a lower cost. That sentence is the whole design brief: not every motion a human hand can make, but the large share of motions that automation and laboratory work depend on.
Positioning and key technology
Five-finger humanoid hands chase anthropomorphic dexterity, and they carry the cost and complexity that come with it. The 021S gives up the extra fingers and keeps what matters for manipulation. It weighs 0.6kg, offers a 22N grip force and provides 8 DOFs for flexible industrial manipulation. Its transmission combines gears, tendon rope and linkages, a mix of mechanisms that keeps the hand compact.
Sensing is where the hand earns the word "high-function." Fingertip tactile sensitivity is 0.1 N, and 3D fingertip force sensing provides real-time contact force feedback. Torque is adjustable steplessly from 0 to 1 A with dynamic adaptation, so the hand can adjust its effort to the object. A standard palm-mounted 5 MP auto-focus RGB camera gives the hand its own view of the target.
On the software side, the hand ships with an open-source SDK and supports multiple protocols, and it adapts to mainstream robotic arms through multiple communication protocols. For a lab, that means less time writing drivers and more time running experiments.
Technical Specifications
| Specification | Value |
|---|---|
| Model | DexHand021 S (021S) |
| Fingers | Three |
| Degrees of freedom | 8 DOFs |
| Weight | 0.6kg |
| Grip force | 22N |
| Dimensions | 208mm * 80mm * 82.8mm |
| Repeatability | ± 0.5 mm |
| Minimum grasp diameter | ≤ 30 mm |
| Lifespan | 200,000 cycles |
| Tactile sensitivity | 0.1 N |
| Fingertip force sensing | 3D, real-time contact force feedback |
| Palm camera | 5 MP auto-focus RGB camera, palm-mounted |
| Torque control | 0 - 1 A stepless adjustment with dynamic adaptation |
| Transmission | Gear + tendon rope + linkage |
| Voltage | DC 24 V |
| Communication | CAN FD / RS485 |
| Software | Open-source SDK, multi-protocol |
Specifications as published by the manufacturer; confirmed against the datasheet at quotation.
The manufacturer has not published the IP rating, the operating temperature range, the supported operating systems or the detail of fingertip tactile coverage; they are confirmed at quotation.
What makes the 021S different from a standard gripper?
A parallel gripper opens and closes. It is excellent at one job and awkward at everything else. The 021S has 8 DOFs spread over three fingers, so it can wrap, pinch and hold objects of different shapes without a tool change. The minimum grasp diameter of ≤ 30 mm and the ± 0.5 mm repeatability support the precision picking of micro-objects, which is where a fixed-jaw gripper usually runs out of options.
The second difference is feedback. A plain gripper often has no idea how hard it is holding. Here, 3D fingertip force sensing reports contact force in real time, and the 0.1 N tactile sensitivity lets the hand register very light touches. Combined with the 0 - 1 A stepless torque adjustment, the hand can be asked to grip gently rather than simply firmly.
The third difference is sight. The palm-mounted 5 MP auto-focus RGB camera sits where the work happens, so the hand can look at an object as it approaches it. For teams developing vision-guided manipulation, that removes one external camera and one calibration step.
How does the 021S compare with the other DexHand021 versions?
The 021S is the entry point of the line, and the other versions go further in different directions. The Dexrobot 021MP is a high-DOF, multi-modal, perceptive hand. The Dexrobot 021PRO integrates the wrist with the hand. The Dexrobot 021 Concept is an intelligent general-purpose hand. The figures on this page belong to the 021S alone and should not be read across to those versions.
If the task is clear and the objects are modest in variety, the 021S is the practical start. If the work calls for a wider range of motion or an integrated wrist, the sibling versions deserve a look before you request a quotation.
Who is the Dexrobot 021S for?
Research laboratories are the obvious first group. The open-source SDK, the multi-protocol support and the sensing set make the hand a workable platform for studies in grasping, tactile feedback and learning-based manipulation. Universities across the Caribbean that are building robotics programs will find an approachable hand here, without the cost of a full humanoid unit.
Integrators and automation teams form the second group. The hand runs on DC 24 V, communicates over CAN FD or RS485, and adapts to mainstream robotic arms, so it fits into an existing cell without a redesign. Light assembly, small-part handling and pick-and-place with varied objects are natural tasks.
Developers of service and mobile robots are the third group. At 0.6kg, the hand adds little load to a mobile manipulator. Buyers who need a more elaborate hand, such as one with an integrated wrist, should look at the 021PRO instead. You can also browse the full Robot Hands category for alternatives.
What is the Dexrobot 021S used for?
- Precision picking. The ± 0.5 mm repeatability supports the picking of micro-objects.
- Grasping research. Eight DOFs and an open-source SDK give laboratories a flexible test platform.
- Tactile and force-feedback studies. 3D fingertip force sensing and 0.1 N tactile sensitivity provide contact data in real time.
- Vision-guided manipulation. The palm-mounted 5 MP camera lets the hand observe the target as it grasps.
- Light industrial handling. A 22N grip force and a lifespan of 200,000 cycles suit repeated manipulation tasks.
- Mobile manipulation. The 0.6kg weight keeps the hand practical on mobile bases and robot arms.
Pricing and Availability
No price is listed here, because each project differs in quantity, arm integration and support needs. Request a quotation and we will respond with the details. Delivery, customs and support are arranged together with the quotation. The Dexrobot 021S is available on this page.
Frequently Asked Questions
What is the weight and grip force of the 021S?
The hand weighs 0.6kg and offers a 22N grip force. It has 8 DOFs across its three fingers.
Which communication interfaces does it use?
The 021S communicates over CAN FD or RS485 and runs on DC 24 V.
Does the hand include sensing?
Yes. It has 3D fingertip force sensing with real-time contact force feedback, a 0.1 N tactile sensitivity and a palm-mounted 5 MP auto-focus RGB camera.
How small an object can it grasp?
The minimum grasp diameter is ≤ 30 mm, and the repeatability is ± 0.5 mm. That supports the precision picking of micro-objects.
Is software provided?
Yes. The hand comes with an open-source SDK and multi-protocol support.
Will it work with my robot arm?
It adapts to mainstream robotic arms via multiple communication protocols. Tell us which arm you use when you request a quotation.
Where can I buy the Dexrobot 021S and what does it cost?
You can buy it through this page by requesting a quotation. We do not list a price here; the quotation covers your quantity, delivery and support needs.
Summary
The Dexrobot 021S makes a simple argument: a hand does not need five fingers to be useful, it needs the right three and the right feedback. With 8 DOFs, a 22N grip force, 0.1 N tactile sensitivity, 3D fingertip force sensing and a 5 MP palm camera in a 0.6kg body, it covers a large share of everyday manipulation. For labs, integrators and mobile robot builders in the Caribbean, this page is the starting point.


