
Xynova PRM10-20-47-100-F Linear Actuator
In stock
- BRAND:
- XYNOVA
- MODEL:
- PRM10-20-47-100-F
- ORIGIN:
- China
- Warranty:
- 12 MONTHS
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- Xynova-PRM10-20-47-100-F
Xynova PRM10-20-47-100-F Linear Actuator
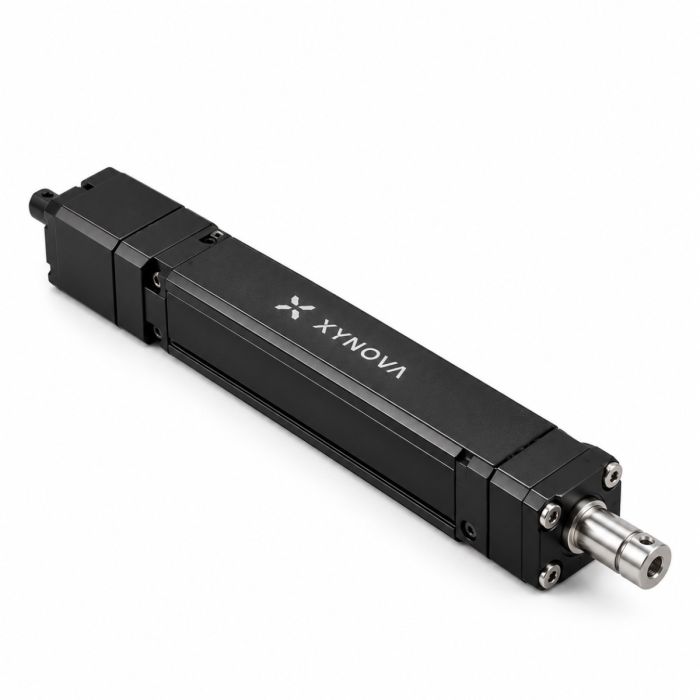
A humanoid hand has to move a finger, a wrist or an elbow inside a space not much wider than your thumb, and it has to do so without a motor that hums, overheats or lets go when the power drops. The Xynova PRM10-20-47-100-F Linear Actuator is built for exactly that squeeze: a micro electric cylinder whose body measures 10*13.5*81mm and whose drivetrain is developed in-house, from the screw to the motor to the control software.
The product is available through this page, by quotation.
Background
Xynova and its lineage
Xynova Technology Co., Ltd. is a core component supplier in the field of humanoid robots. The company specializes in the research, development, production and sales of three families of parts: high-dexterity dexterous hands, high-torque density integrated joint modules, and micro electric cylinders. That mix tells you a lot about how the company thinks. A humanoid robot is a collection of joints, and each joint needs a compact, strong and controllable source of motion. Xynova supplies several answers to that need, and the linear actuator on this page is one of them.
Because Xynova develops its own screw, motor and software, the parts are designed to work together instead of being assembled from unrelated catalogs. For an integrator in a robotics lab, a university workshop or a small manufacturing team, this matters. It means fewer interfaces to reconcile and a single supplier whose components share a design philosophy. Xynova also makes rotary actuators alongside its linear products; you can browse the wider range in our Robot Actuators category.
Positioning and key technology
The PRM10 family consists of micro electric cylinders designed for humanoid robots. Across the series, the linear drive solutions cover a thrust range from 60N to 8000N, meeting the needs of all major joints. This particular model, the PRM10-20-47-100-F, sits at the micro end of that spectrum, where size and weight on the arm or hand count as much as raw force.
Three pieces of technology define it. The first is the lead screw: an in-house developed 7mm micro planetary roller screw, which greatly improves transmission efficiency and suits various industrial and everyday applications. The second is the motor: an in-house developed frameless torque motor, a brushless hollow cup motor design that provides higher torque, longer lifespan and quieter operation. The third is the software: in-house developed upper-level software with a rich set of API interfaces, enabling easy coordination and control of multiple modules. Together they make a compact actuator that is meant to be driven from code and combined with other modules in the same machine.
Technical Specifications
| Specification | Value |
|---|---|
| Product type | Micro electric cylinder for humanoid robots |
| Size (L×W×H) | 10*13.5*81mm |
| Operating voltage | DC12±10%V |
| Lead screw | In-house developed 7mm micro planetary roller screw |
| Motor | In-house developed frameless torque motor / brushless hollow cup motor |
| Self-locking | Easy joint self-locking; no risk of power failure |
| Software | In-house developed upper-level software with a rich set of API interfaces |
| Series thrust range (PRM10 family) | 60N to 8000N |
Specifications as published by the manufacturer; confirmed against the datasheet at quotation.
The manufacturer has not published the package contents, the IP rating, the communication interface, the position sensor type, the rated thrust, the mounting dimensions, the noise level or the service life; they are confirmed at quotation.
What makes the PRM10-20-47-100-F different from a conventional linear actuator?
A conventional linear actuator is usually a motor, a gearbox and a screw in a housing, sized for a machine frame. This one is sized for a robot limb. The body is 10*13.5*81mm, and every internal choice serves that constraint. The planetary roller screw replaces the plain lead screw you might find in a general-purpose unit, and it greatly improves transmission efficiency. Efficiency is the quiet hero of a small actuator: a drivetrain that wastes less energy as friction leaves more of the supplied power for useful work, and generates less heat in a tight enclosure.
The motor is the second difference. A frameless torque motor of the brushless hollow cup type brings higher torque, longer lifespan and quieter operation. Quiet matters more than people expect. A humanoid robot that works near people, in a classroom or a demonstration hall, should not sound like a workshop.
The third is safety behavior. There is no risk of power failure, and the actuator offers easy joint self-locking, which enhances safety during operation. For a joint that holds a load, such as an elbow or a finger gripping an object, a drive that holds its position is a real advantage over one that needs constant current to do so.
How is the PRM10-20-47-100-F controlled and combined with other modules?
Hardware is only half of a robot joint; the other half is how you tell it what to do. Xynova supplies in-house developed upper-level software with a rich set of API interfaces, enabling easy coordination and control of multiple modules. In practice, that means a team building a hand with several fingers, or an arm with several joints, can address the actuators from one control environment rather than writing a separate driver for each part.
The operating voltage is DC12±10%V, a supply level that is practical on a bench and on a battery-powered platform alike. If your controller or bus architecture is fixed, tell us when you request a quotation so we can match it to your project.
If your design needs a different version within the same family, the Xynova PRM10-20-18-200-F Linear Actuator is a sibling worth comparing. Each version keeps its own figures, so compare them one by one.
Who is the Xynova PRM10-20-47-100-F for?
The first group is humanoid robot developers. These teams need small, strong and quiet drives for fingers, wrists and other compact joints, and they value an actuator that is designed for that job from the start.
The second group is university and research laboratories. A planetary roller screw actuator with an open API is a practical building block for experiments in manipulation, prosthetics and biomimetic mechanisms, where students and researchers write their own control code.
The third group is prototype builders in industrial automation. Small pick-and-place mechanisms, compact clamps and precision feeders can use a micro electric cylinder where a pneumatic part is too bulky or too noisy. The screw suits various industrial and everyday applications.
The fourth group is educators and makers who run advanced mechatronics programs and want a professional component to teach with. If your work calls for rotary motion instead, look at the other Xynova drives, for example the Xynova PR20-102-130-HS Rotary Actuator, which belongs to the same maker's joint range.
What is the Xynova PRM10-20-47-100-F used for?
- Humanoid finger and hand joints. The compact body fits where a larger drive cannot, and the cylinder pushes and pulls the linkages that close a hand.
- Wrist and forearm mechanisms. Linear motion converts into rotation or tilt through a simple linkage, keeping the forearm slim.
- Robotic manipulation research. An open API and a controllable drivetrain make it a good base for experimental grippers and test rigs.
- Laboratory automation prototypes. Small, quiet linear motion suits sample handling, positioning stages and bench-top test equipment.
- Education and training platforms. Students work with a real robotics component, from wiring the supply to writing the control routine.
- Multi-module robotic systems. The upper-level software is built to coordinate several modules, so the actuator can be one of many in a larger machine.
Pricing and Availability
The Xynova PRM10-20-47-100-F Linear Actuator is sold on a quotation basis. Send us your project details and the quantity you expect, and we will come back with a quotation. Delivery, customs and support are arranged together with the quotation, so you know the full picture before you commit. The Xynova PRM10-20-47-100-F Linear Actuator is available on this page.
Frequently Asked Questions
What type of product is the PRM10-20-47-100-F?
It is a micro electric cylinder, which is a compact linear actuator, designed by Xynova for humanoid robots. It is part of the PRM10 family.
What are its dimensions and supply voltage?
The size is 10*13.5*81mm (L×W×H), and the operating voltage is DC12±10%V.
What kind of screw and motor does it use?
It uses an in-house developed 7mm micro planetary roller screw and an in-house developed frameless torque motor of the brushless hollow cup type. The screw improves transmission efficiency, and the motor provides higher torque, longer lifespan and quieter operation.
Does the actuator hold its position when power is lost?
There is no risk of power failure, and the joint self-locks easily, which enhances safety during operation.
Can I control several actuators together?
Yes. Xynova provides in-house developed upper-level software with a rich set of API interfaces, enabling easy coordination and control of multiple modules.
Who makes this actuator?
It is made by Xynova Technology Co., Ltd., a core component supplier in the field of humanoid robots, which also makes dexterous hands and integrated joint modules.
Where can I buy the Xynova PRM10-20-47-100-F and what does it cost?
You can request it through this page, and we respond with a quotation. We do not print prices here; the quotation also covers delivery, customs and support.
Summary
The Xynova PRM10-20-47-100-F Linear Actuator answers a very specific problem: how to put real linear force into a space no wider than a finger. It does so with a 7mm micro planetary roller screw, a frameless torque motor, easy joint self-locking and software designed to coordinate many modules, all developed by a company that focuses on humanoid robot components. The body is small and the supply is DC12±10%V. If you are building a hand, an arm or a laboratory mechanism and want to see whether this actuator fits, this page is the starting point.


