
Unitree R1-A5 Smart F Humanoid Robot
In stock
- BRAND:
- UNITREE ROBOTICS
- MODEL:
- R1-A5-Smart-F
- PART #:
- R1-A5-Smart-F
- ORIGIN:
- China
- Warranty:
- 12 MONTHS
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- Unitree-R1-A5-Smart-F
Unitree R1-A5 Smart F Humanoid Robot
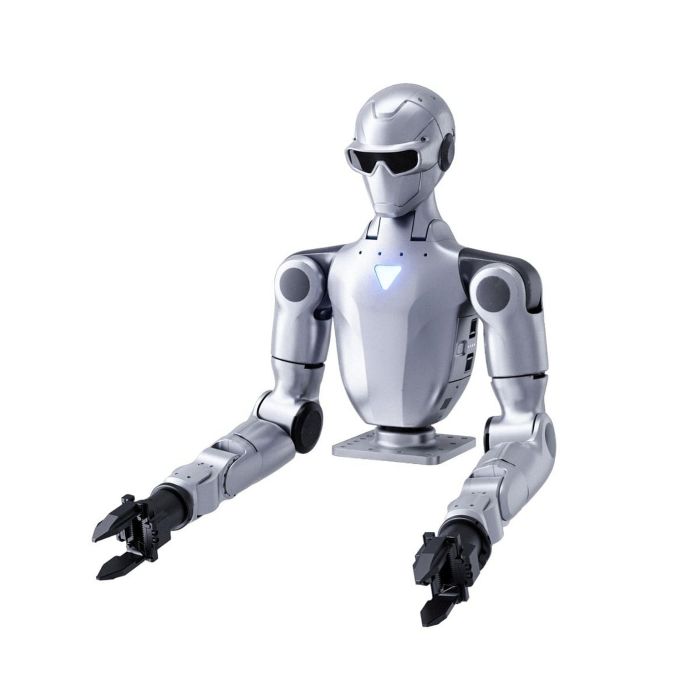
A robot does not need legs to be useful, and it does not need to cross a room to teach you something about manipulation. The Unitree R1-A5 Smart F Humanoid Robot stays where you mount it and puts its effort into reaching, grasping and sensing. It is a dual-arm torso with a rotating waist and a movable sensor head, and in the Smart F configuration it carries LinkerBot O6 Hands and an added compute module for onboard AI work.
The product is available through this page, by quotation.
Background
Unitree Robotics and the R1-A5 line
Unitree Robotics is a name many robotics teams already know from its research platforms. The R1-A5 belongs to a family with several named versions: R1-A5, R1-A7, R1-A5-D, R1-A7-D, R1-A5 Smart F and R1-A5-D Smart F. The platform is described by its maker as a dual-arm manipulation robot built for research, data collection and embodied-AI development. Its layout is two 5-DoF arms, a rotating waist and a 2-DoF sensor head on a compact torso.
The Smart F is one configuration inside the R1-A5 range. Its distinguishing feature is the end effector: LinkerBot O6 Hands. The Smart configurations also add a 40 TOPS Orin Nano to the standard compute. If you want the plain platform without that extra module, the Unitree R1-A5 Fixed Base Dual-Arm Humanoid Robot is the page to read next.
Positioning: a torso, not a walker
It helps to be direct about what this machine is. It does not walk. It is a torso, not a legged humanoid, and that is a deliberate choice. By dropping locomotion, the design concentrates on arm reach, joint quality and perception, which are the parts that matter when the goal is to collect manipulation data or train a policy at a bench.
The joints use crossed-roller and deep-groove ball bearings, with hollow internal wiring, dual encoders on the arm joints and local air cooling. Full secondary development support through an SDK is listed, so teams can write their own control and learning code rather than being limited to a fixed set of behaviors. Anyone browsing the wider range can start from the Unitree R1-A5 category or the Unitree R1 category.
Technical Specifications
The figures below are those listed for the R1-A5 platform on which the Smart F is built. The end effector and the added compute are the Smart F configuration items.
| Specification | Value |
|---|---|
| Configuration | R1-A5 Smart F |
| End effector | LinkerBot O6 Hands |
| Smart compute module | 40 TOPS Orin Nano |
| Base compute | 8-core CPU in the body; 8-core CPU with 10 TOPS in the head |
| Dimensions (desk-mount) | 700 x 357 x 190 mm (27.6 x 14.1 x 7.5 in) |
| Weight (desk-mount) | about 11 kg (24 lb) |
| Degrees of freedom | 13 (5 x 2 arms, 1 waist, 2 head), or 15 counting the grippers |
| Arm reach (forearm plus upper arm) | 420 mm (16.5 in) |
| Maximum shoulder torque | 60 Nm (44 lb-ft) |
| Maximum arm load capacity | 2~4KG |
| End-clamp accuracy | ±0.1mm |
| Waist yaw | ±150° |
| Head range | yaw ±115°, pitch ±36° |
| Audio | 4-array microphone and dual speakers |
| Wireless | Wi-Fi 6 and Bluetooth 5.2 |
| Power | External supply standard; optional upper-body battery giving about 1.5 h |
| Development | Full secondary development support (SDK) |
| Locomotion | None; torso platform that does not walk |
Specifications as published by the manufacturer; confirmed against the datasheet at quotation. The manufacturer has not published the IP rating, the operating temperature range, the top speed, the battery capacity, the packaged contents or the per-hand specifications of the Smart F; they are confirmed at quotation.
What makes the Smart F different from the base R1-A5?
The base R1-A5 already gives a lab two arms, a waist and a head, with a pair of 8-core processors as standard. The Smart F changes two things. First, it fits LinkerBot O6 Hands as the end effector, so the robot is aimed at tasks where the hand matters as much as the arm. Second, like the other Smart configurations, it adds a 40 TOPS Orin Nano, which gives extra capacity for running perception or learned models on the robot itself.
That combination suits teams who want to train and test on the same machine. The 10 TOPS processor in the head and the added Orin Nano give two separate places to run workloads, and the SDK lets you decide how to split them. Questions about finger count, grip force or sensing in the O6 Hands should go into your quotation request.
If your work does not call for this hand or the extra compute, you may be better served by a simpler configuration. The Unitree R1-A5 Smart A Humanoid Robot is one of the other Smart versions listed on the store, and the fixed-base page covers the standard platform.
How much can the arms handle and how precise are they?
The listed maximum arm load capacity is 2~4KG, and the end-clamp accuracy is ±0.1mm. Each arm has a reach of 420 mm (16.5 in), measured as forearm plus upper arm, and the shoulder delivers up to 60 Nm (44 lb-ft). The waist rotates ±150°, which widens the working area considerably without moving the base.
These are bench-scale figures, and they describe a robot meant for tabletop manipulation, not heavy lifting. Dual encoders on the arm joints and crossed-roller bearings support the precision side. What the hand itself can carry depends on the hand fitted, so raise it in your quotation request.
Who is the Unitree R1-A5 Smart F Humanoid Robot for?
University and corporate research groups are the clearest fit. A team working on imitation learning, teleoperated data collection or vision-guided grasping gets a stable two-arm platform with a head-mounted sensor system and an open SDK. The additional compute helps when a model has to run on the robot rather than on a remote workstation.
Educators and training programs can use it to show students how perception, planning and control come together in one machine, without the added difficulty of balance and walking. Integrators evaluating dexterous manipulation for a future application can use it as a development and demonstration unit before committing to a final design.
Buyers who need a different configuration should compare the fixed-base version and the Smart A page. If your project needs a robot that moves around a site, this is not the right machine, since it does not walk.
What is the Unitree R1-A5 Smart F Humanoid Robot used for?
- Manipulation research. Test grasping, handover and bimanual strategies on a fixed, repeatable platform.
- Data collection. Record demonstrations for embodied-AI training with arms, waist and head moving together.
- Embodied-AI development. Run models on the onboard compute and iterate through the SDK.
- Teaching and labs. Give students hands-on access to a dual-arm robot with a sensing head.
- Voice-based interaction. Use the 4-array microphone and dual speakers to build spoken collaboration into a task.
- Integration trials. Evaluate dexterous manipulation for a planned workcell before final design decisions.
Pricing and Availability
We do not print prices on this page. Quotation is the way to buy: tell us your configuration needs, your location and your intended use, and we will respond with a proposal. Delivery, customs and support are arranged with the quotation. The Unitree R1-A5 Smart F Humanoid Robot is available on this page.
Frequently Asked Questions
Does the Unitree R1-A5 Smart F walk?
No. It is a torso, not a legged humanoid, and it does not walk. It is mounted at a desk or bench and works from there.
What hands does the Smart F use?
It uses LinkerBot O6 Hands. Ask for the per-hand details in your quotation request.
What extra compute does a Smart configuration add?
Smart configurations add a 40 TOPS Orin Nano. This sits on top of the standard 8-core CPU in the body and the 8-core CPU with 10 TOPS in the head.
How is the robot powered?
An external supply is standard. An upper-body battery is optional and gives about 1.5 h; ask for the battery capacity with your quotation.
Can I write my own software for it?
Yes. Full secondary development support through an SDK is listed, so you can build your own control and learning code.
What wireless connections does it have?
It supports Wi-Fi 6 and Bluetooth 5.2. For voice work it has a 4-array microphone and dual speakers.
Where can I buy the Unitree R1-A5 Smart F Humanoid Robot and what does it cost?
You can request it through this page, by quotation. The cost depends on your configuration and destination, so we provide it in the quotation and not as a printed price.
Summary
The Unitree R1-A5 Smart F Humanoid Robot proves that a machine can be useful by staying put. Two 5-DoF arms, a waist that turns ±150°, a head that looks around, LinkerBot O6 Hands and a 40 TOPS Orin Nano add up to a compact manipulation workstation for research, data collection and embodied-AI development. It will not walk across your lab, and it is not meant to. If dexterous work at a bench is what you need, this page is the starting point.


