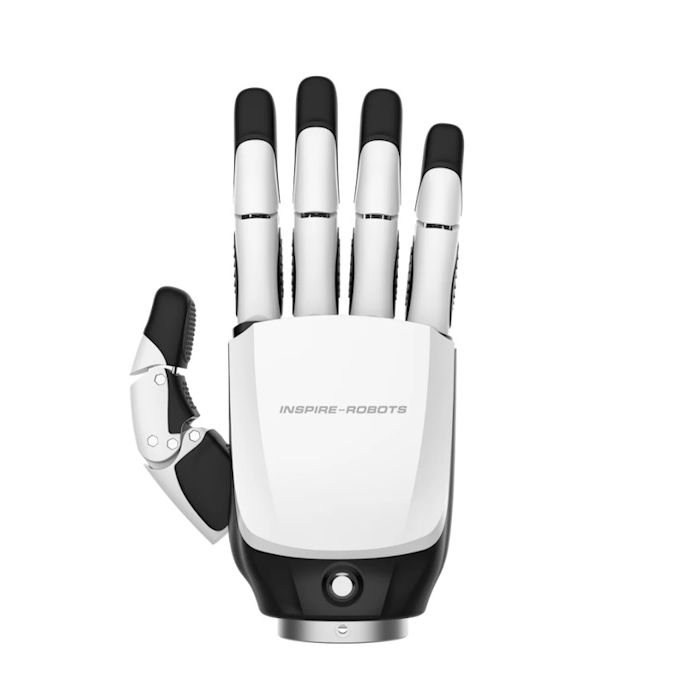
Inspire Robots Dexterous Robot Hand (RH56DFX)
In stock
- BRAND:
- INSPIRE ROBOTS
- PART #:
- RH56DFX
- ORIGIN:
- China
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- Inspire-RH56DFX
Inspire Robots Dexterous Robot Hand (RH56DFX)
Most robot arms can grip, but very few can pick up an object the way a person does. The Inspire Robots Dexterous Robot Hand (RH56DFX) is built for that gap: five fingers, twelve joints and force feedback in a hand that a humanoid, an arm or a test bench can carry. It is a strength-and-speed hand, and it is not the version with tactile skin.
The product is available through this page, by quotation.
Background
Inspire Robots and the DFX series
Inspire Robots makes humanoid-style hands for research labs, universities and robot builders. Its catalog is gathered in the Inspire Robots category, and the hands themselves sit in the Robot Hands category. The DFX series is described by its maker as a humanoid five-finger dexterous hand that combines strength and speed, with a thumb active output force of 1.5KG and a four finger fingertip output force of 1KG.
The series comes in four versions. The RH56DFX-2L is the left hand and the RH56DFX-2R is the right hand, both without a wrist. The RH56DFXW-2L and the RH56DFXW-2R are the left and right hands with a wrist. Keeping the versions apart matters, because weight, degrees of freedom and wrist motion differ between them.
What sets the RH56DFX apart in its positioning
The hand pairs absolute position sensors with force sensors, so the controller receives real-time force feedback while the fingers move. That makes it useful where a program needs to know how hard the hand is holding, not only where the fingers are. It has no tactile sensors, so it does not report touch across the finger surfaces. Teams that need that feature should look at the tactile-equipped hands in the same family, which are named further down this page.
Another practical feature is power-off self-locking. When power is removed, the fingers hold their position, and there is no need to change position when powering on again. For a grasp that must survive a supply interruption, or a demonstration that restarts often, this removes a step and a risk.
Technical Specifications
| Specification | RH56DFX-2L / 2R (no wrist) | RH56DFXW-2L / 2R (with wrist) |
|---|---|---|
| Weight | 540g | 650g |
| Degrees of freedom | 6 | 6+2 |
| Number of joints | 12 | 12 |
| Control interface | RS485 | RS485 |
| Operating voltage | DC12V-48V | DC12V-48V |
| Peak current | 2A@24V | Not listed separately |
| Repeatability | ±0.20mm | ±0.20mm |
| Thumb fingertip strength | 15N | 15N |
| Fingertip strength | 10N | 10N |
| Force resolution | 0.50N | 0.50N |
| Thumb lateral rotation range | >65° | >65° |
| Thumb lateral rotation speed | 107°/s | 107°/s |
| Thumb flexion speed | 70°/s | 70°/s |
| Four-finger flexion speed | 260°/s | 260°/s |
| Wrist yaw movement | Not applicable | ±27° |
| Wrist pitch movement | Not applicable | ±22° |
| Wrist load torque | Not applicable | 2NM (excluding hand weight) |
Specifications as published by the manufacturer; confirmed against the datasheet at quotation.
The manufacturer has not published the dimensions, the IP rating, the communication baud rate, the service life, the operating temperature or the package contents; they are confirmed at quotation.
What makes the RH56DFX different from a parallel-jaw gripper?
A parallel-jaw gripper opens and closes along one line. It is simple and dependable for boxes, bars and parts that arrive in a known pose. The RH56DFX has five fingers and twelve joints, and the thumb has its own lateral rotation of more than 65°. That lets the hand approach an object from different angles, wrap around it, or pinch it between thumb and fingertips.
The speeds support this. The four fingers flex at 260°/s, while the thumb flexes at 70°/s and rotates laterally at 107°/s. The fingers close quickly and the thumb positions itself more deliberately. Together with the stated repeatability of ±0.20mm, this suits repeated grasp trials where the same motion has to be reproduced again and again.
Force is the other half. With a thumb fingertip strength of 15N, a fingertip strength of 10N and a force resolution of 0.50N, the hand can be commanded and monitored in small steps. The sensors report force in real time, so a control program can stop a grasp at the right level rather than squeezing blindly.
What does the wrist version add?
The RH56DFXW-2L and RH56DFXW-2R add a wrist to the same hand. Degrees of freedom rise from 6 to 6+2, and the wrist moves ±27° in yaw and ±22° in pitch. The wrist load torque is 2NM, excluding the weight of the hand itself. Weight rises from 540g to 650g, so the arm or the humanoid frame that carries it should be sized with that in mind.
The wrist is worth choosing when the arm cannot easily reorient the hand, for example on a compact humanoid upper body or a simple test fixture. If your arm already provides full wrist motion, the lighter version without a wrist avoids duplicating it. The left and right models are mirror images, so a two-handed humanoid needs one of each.
Who is the RH56DFX for?
University and corporate research teams are the clearest group. Work on grasp planning, imitation learning and teleoperation needs a hand that returns joint position and force data, and the RS485 interface and DC12V-48V supply make it straightforward to wire into a test setup. Humanoid builders will value the five-finger layout and the choice between left and right, with or without a wrist.
Integrators building demonstration cells or training equipment can use the power-off self-locking to keep an object held through a power cut. Educators who teach manipulation get a hand that shows human-like grasping in a form a lab can afford to run daily.
If your task depends on feeling touch across the finger surfaces, this is not the hand to choose, because it has no tactile sensors. In that case, consider the Inspire Dexterous Left Hand With Tactile Sensors (RH56F1-E2L-T1) or the Inspire Dexterous Right Hand With Tactile Sensors (RH56F1-E2R-T1). Buyers comparing within the same maker's range may also look at the Inspire RH56BFX Dexterous Robot Hand (RH56BFX).
What is the RH56DFX used for?
- Grasp research. Test pinch grasps and wrapping grasps with a hand that reports position and force as it moves.
- Imitation learning. Record human demonstrations and replay them on a five-finger hand with twelve joints.
- Teleoperation. Let an operator control a human-shaped hand remotely, with force feedback helping to judge the grip.
- Humanoid platforms. Fit a left or right hand, with or without a wrist, to the arms of a humanoid robot.
- Demonstration cells. Show dexterous handling at exhibitions and customer visits, with fingers that stay put when power is off.
- Teaching manipulation. Give students a real multi-finger hand for coursework in control, sensing and grasping.
Pricing and Availability
Each hand is supplied by quotation. Tell us which version you need, left or right, with or without a wrist, and how many, and we will prepare the quotation. Delivery, customs and support are arranged together with the quotation. The Inspire Robots Dexterous Robot Hand (RH56DFX) is available on this page.
Frequently Asked Questions
Which versions of the RH56DFX exist?
There are four: RH56DFX-2L (left hand), RH56DFX-2R (right hand), RH56DFXW-2L (left hand with wrist) and RH56DFXW-2R (right hand with wrist).
How much does the hand weigh?
The versions without a wrist weigh 540g. The versions with a wrist weigh 650g.
How is the hand controlled and powered?
The control interface is RS485, and the operating voltage is DC12V-48V. The peak current of the version without a wrist is 2A@24V.
Does the hand have tactile sensors?
No. It has absolute position sensors and force sensors that give real-time force feedback, but no tactile sensors.
What happens to the fingers when power is cut?
The hand has power-off self-locking, so the fingers hold their position. There is no need to change position when powering on.
How much force can the hand apply?
The thumb active output force is 1.5KG and the four finger fingertip output force is 1KG. Thumb fingertip strength is 15N and fingertip strength is 10N.
Where can I buy the RH56DFX and what does it cost?
You can buy it through this page by requesting a quotation. The cost depends on the version and quantity and is given in the quotation, not on this page.
Summary
The RH56DFX is a hand for people who need more than a gripper but do not need touch skin: five fingers, twelve joints, force feedback, a firm grip and fingers that hold when the power goes. Choose the version without a wrist when your arm already moves freely, and the version with a wrist when the hand must turn on its own. To select your version and request a quotation, this page is the starting point.