
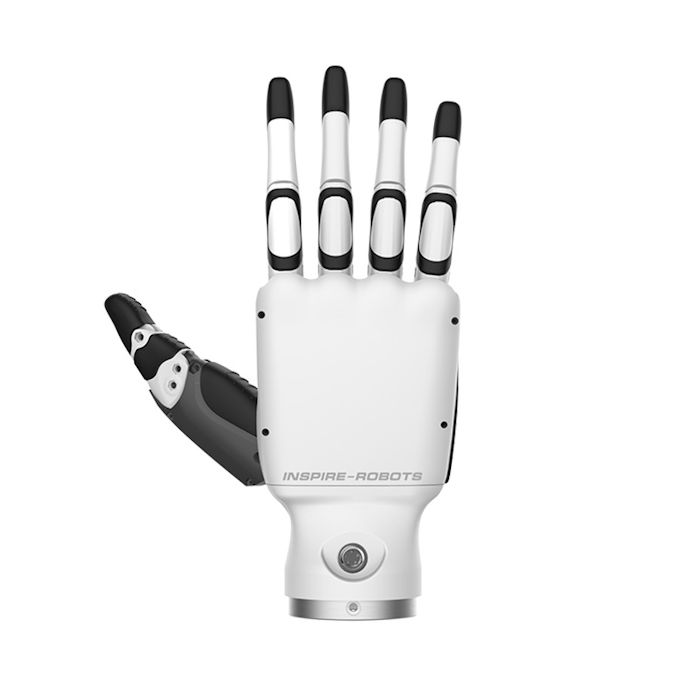
Inspire RH56BFX Dexterous Robot Hand (RH56BFX)
In stock
- BRAND:
- INSPIRE ROBOTS
- PART #:
- RH56BFX
- ORIGIN:
- China
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- Inspire-RH56BFX
Inspire RH56BFX Dexterous Robot Hand (RH56BFX)
A hand that can play a piano passage does not need to crush a bottle to be useful. The Inspire RH56BFX Dexterous Robot Hand (RH56BFX) is built on that idea: quick fingers and controlled touch come first, and raw gripping force comes second.
The product is available through this page, by quotation.
Background
Inspire Robots and the RH56 family
INSPIRE ROBOTS makes dexterous hands for humanoid platforms, research labs and demonstration work. The RH56BFX belongs to the RH56 series, which also includes the RH56DFX series. The two are tuned differently. The RH56BFX has faster speed and slightly less gripping force than the RH56DFX series.
Other hands from the same maker are listed in the Robot Hands category and on the Inspire Robots page, so buyers can compare designs before asking for a quotation.
Positioning and key technology
The hand uses a linear drive design with six micro linear servo actuators and six pressure sensors integrated inside. A single hand has 6 degrees of freedom and 12 motor joints. A hybrid force and position control algorithm lets the hand imitate a human hand in accurate grasping operations.
The RH56BFX suits playing the piano, mora, gesture dance and other functional situations. It supports ROS, and a ROS plug-in is available, which helps teams that already work in that environment.
Technical Specifications
| Specification | Value |
|---|---|
| Drive design | Linear, six micro linear servo actuators |
| Integrated sensing | Six pressure sensors |
| Degrees of freedom | 6 per hand |
| Motor joints | 12 per hand |
| Control algorithm | Hybrid force and position control |
| Control interface | RS485 or CAN |
| Software support | ROS; ROS plug-in available |
| Weight, bare hand | 540 g |
| Weight, with wrist | 650 g |
Specifications as published by the manufacturer; confirmed against the datasheet at quotation.
The manufacturer has not published the dimensions, the IP rating, the operating temperature, the payload, the cable length or the contents of the box; they are confirmed at quotation.
What makes the RH56BFX different from the RH56DFX series?
The difference is the trade-off. The RH56BFX gives up a little gripping force in return for faster speed. For work where timing and finger motion matter more than holding power, that is the better balance.
The RH56BFX comes in Left and Right versions, RH56BFX-2L (Left) and RH56BFX-2R (Right). You can also choose between RS485 and CAN control, and between With Wrist and Without Wrist packages.
Which package should I choose: with wrist or without?
If you need a mechanical wrist, choose the With Wrist package. The bare hand weighs 540 g and the hand with wrist weighs 650 g, so the wrist adds weight that a lightweight arm or humanoid forearm has to carry. If your platform already has its own wrist, the bare hand is the simpler choice.
Who is the RH56BFX for?
Research labs and universities will find a hand with built-in pressure sensing and ROS support easy to bring into existing work. Humanoid robot builders can use it where fast, expressive finger motion matters. Teams preparing public demonstrations, such as gesture or music performances, are the segment this hand is aimed at.
If your task is closer to firm gripping, ask us about the RH56DFX series, which has slightly more gripping force. For other designs, compare the Inspire RH56E2 Dexterous Robot Hand (RH56E2) and the other hands in the Robot Hands category.
What is the RH56BFX used for?
- Piano playing. Fast finger motion suits keyboard demonstrations.
- Mora. The speed helps with quick hand games and gesture recognition tests.
- Gesture dance. Expressive finger movement works well in staged performances.
- Humanoid robotics. It serves as an anthropomorphic hand for humanoid platforms.
- Grasping research. Hybrid force and position control supports accurate grasping studies.
- ROS development. The ROS plug-in lets teams integrate the hand into existing software.
Pricing and Availability
We do not print prices on this page. Quotation is the next step: tell us the version, the control interface and whether you need the wrist, and we will respond. Delivery, customs and support are arranged with the quotation. The Inspire RH56BFX Dexterous Robot Hand (RH56BFX) is available on this page.
Frequently Asked Questions
How many degrees of freedom does the hand have?
A single hand has 6 degrees of freedom and 12 motor joints.
Which control interfaces are offered?
The hand uses an RS485 or CAN control interface.
Does it support ROS?
Yes. It supports ROS, and a ROS plug-in is available.
Can I get a mechanical wrist?
Yes. Choose the With Wrist package. The hand with wrist weighs 650 g, against 540 g for the bare hand.
Is it stronger than the RH56DFX series?
No. It has slightly less gripping force than the RH56DFX series, but faster speed.
What is its payload and IP rating?
Neither figure is listed for this hand yet. Ask for them with your quotation.
Where can I buy the RH56BFX and what does it cost?
You can buy it through this page by requesting a quotation. The cost depends on the version and package you choose, and it is given in the quotation.
Summary
The RH56BFX is a hand chosen for speed and touch rather than brute strength. It has six actuators, six pressure sensors, hybrid force and position control, ROS support and a choice of RS485 or CAN. If that balance fits your project, this page is the starting point.


