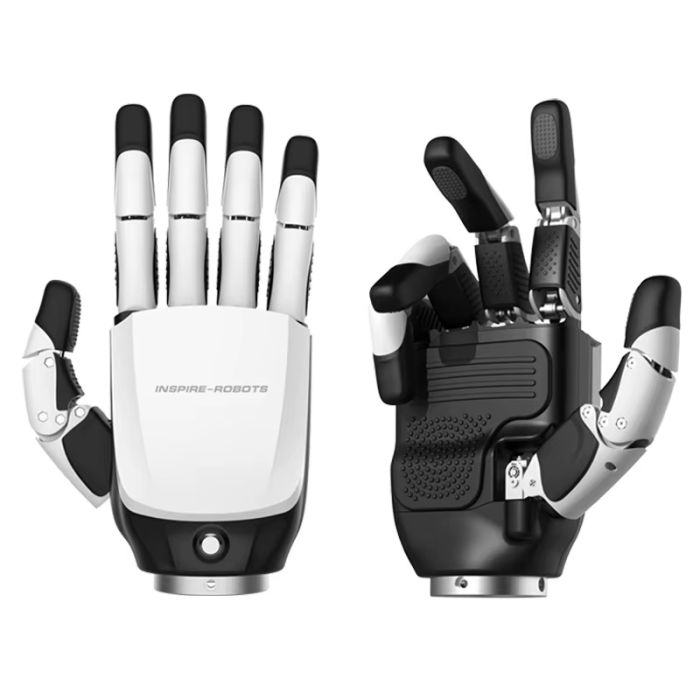
Inspire RH56E2 Dexterous Robot Hand (RH56E2)
In stock
- BRAND:
- INSPIRE ROBOTS
- PART #:
- RH56E2
- ORIGIN:
- China
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- Inspire-RH56E2
Inspire RH56E2 Dexterous Robot Hand (RH56E2)
Most robot hands force a choice between delicate and strong. The Inspire RH56E2 Dexterous Robot Hand (RH56E2) is built to refuse that choice: it is presented as the world's first industrial-grade dexterous hand with grasping force comparable to a human hand, and it carries force sensing inside the fingers so that strength can be applied with care.
The product is available through this page, by quotation.
Background
Inspire Robots and the RH56E2 line
Inspire Robots is a manufacturer of robot hands, and the RH56E2 belongs to its family of dexterous hands for robotic arms and humanoid platforms. You can browse the wider range in our Inspire Robots section, and compare other end effectors in the Robot Hands category.
The RH56E2 is sold in several versions. The sources name RH56E2-0R-T1, RH56E2-0L-T1, RH56E2-2R-T1, RH56E2-2L-T1, RH56E2-0R-T2, RH56E2-0L-T2, RH56E2-2R-T2 and RH56E2-2L-T2, along with the RH56E2-0L / 2L and RH56E2-0R / 2R models without tactile sensors. The letters R and L refer to right-hand and left-hand models, so a two-handed robot can be fitted with a matching pair.
Positioning and key technology
The manufacturer positions the RH56E2 as a heavy-load dexterous hand able to meet demanding operating conditions. Its fingertip gripping force is 30N, and its overall load capacity is equivalent to 15KG. Those are the figures that support the claim of gripping performance comparable to that of a human hand.
Strength alone is not what makes a hand useful, so the design pairs it with sensing. Built-in force sensors give real-time feedback on finger force distribution. For work that needs more, the hand supports integration of tactile sensor modules, which capture real-time tactile data from all palm areas. Versions with tactile sensors are the T1 and T2 models.
Mechanically, the hand has 6 degrees of freedom and 12 joints. It is controlled through RS485, CAN or ModbusTCP and runs on 24V±10%, which are common choices in industrial and research robot cells.
Technical Specifications
| Specification | With tactile sensors (T1 / T2) | Without tactile sensors |
|---|---|---|
| Degrees of freedom | 6 | 6 |
| Number of joints | 12 | 12 |
| Weight | 790g±10g | 770g±10g |
| Control interface | RS485, CAN, ModbusTCP | RS485, CAN, ModbusTCP |
| Operating voltage | 24V±10% | 24V±10% |
| Quiescent current | 0.25A @24V | 0.2A @24V |
| Peak current | 4A @24V | 4A @24V |
| Repeatability | ±0.20mm | ±0.20mm |
| Thumb fingertip strength | 30N | 30N |
| Fingertip strength | 28N | 28N |
| Force resolution | 0.05N | 0.05N |
| Lateral rotation range of thumb | 75°-170° | 75°-170° |
| Flexion speed of four fingers | >200°/s | >200°/s |
| Hand closing time | 0.8S | 0.8S |
| Tactile sensor accuracy (T1 / T2) | ≤5%FS | Not applicable |
Specifications as published by the manufacturer; confirmed against the datasheet at quotation.
The manufacturer has not published the dimensions, the IP rating, the operating temperature, the contents of the box, the communication baud rates, the service life, the payload per finger or the housing material; they are confirmed at quotation.
What makes the RH56E2 different from a simple gripper?
A parallel gripper opens and closes. It does that job very well, but it cannot pinch a small part, wrap around a bottle and adjust its hold, all with the same hardware. The RH56E2 has a thumb with a lateral rotation range of 75°-170° and four fingers that flex at more than 200°/s, so a hand like this can move between grasp types instead of being limited to one.
Speed and repeatability matter here as well. The hand closes in 0.8S and positions with a repeatability of ±0.20mm, which suits cycles that must be both quick and consistent. The force resolution of 0.05N means the hand can distinguish very small changes in grip force, which is useful when holding a fragile object where too much force would damage it.
Then there is the contrast between strength and weight. The hand weighs 790g±10g with tactile sensors and 770g±10g without, and yet it carries a load capacity equivalent to 15KG. For an arm or a humanoid platform where every gram at the wrist counts, that ratio is the main attraction.
Which RH56E2 version should I choose?
The first choice is between a hand with tactile sensors and one without. The T1 and T2 versions add tactile sensing, with a tactile sensor accuracy of ≤5%FS, and they weigh 790g±10g with a quiescent current of 0.25A @24V. The models without tactile sensors weigh 770g±10g and draw 0.2A @24V at rest. All versions share the same 6 degrees of freedom, 12 joints and peak current of 4A @24V.
If your task depends on knowing where and how hard an object touches the palm, such as teleoperation, grasp research or learning from demonstration, the tactile versions give you the data. If the built-in force sensing on the fingers is enough and you want the lighter hand, the models without tactile sensors are the plainer option. The second choice is simply left or right. The fact sheet does not state how the T1 and T2 versions differ from each other, so we confirm that when we prepare your quotation.
Who is the RH56E2 for?
Research laboratories and universities will find a hand that offers tactile data and open control interfaces, well suited to studies of manipulation and human-like grasping. Integrators who build service robots or humanoid platforms will value the weight of under 800g and the choice of RS485, CAN or ModbusTCP, which fit common controller setups.
Industrial teams who want to automate work that is awkward for a two-jaw gripper, such as handling mixed objects, can use the force feedback to keep a grip steady. Teams that only need a simpler gripper may prefer another model; you can look at the Inspire EG2-4B Dexterous Robot Hand (EG2-4B) or the Inspire RH56BFX Dexterous Robot Hand (RH56BFX), and we can help you compare them.
What is the RH56E2 used for?
- Manipulation research. A five-finger hand with force and tactile feedback gives laboratories real data on how grasps succeed or fail.
- Humanoid robots. Its low weight and left and right versions make it a practical hand for two-armed platforms.
- Teleoperation. Operators can control a hand that responds with human-like movement while the sensors report contact.
- Service robotics. Robots that pick up everyday objects benefit from adjustable grip force and several grasp types.
- Careful handling of fragile items. With a force resolution of 0.05N, the grip can be tuned for objects that need a light touch.
- Heavy-load grasping in industry. A load capacity equivalent to 15KG lets the hand take on demanding handling tasks.
Pricing and Availability
We do not publish prices for the RH56E2. Please request a quotation, stating the version you need (left or right, with or without tactile sensors) and the number of hands. Delivery, customs and support are arranged together with the quotation. The Inspire RH56E2 Dexterous Robot Hand (RH56E2) is available on this page.
Frequently Asked Questions
How much force can the RH56E2 apply?
The fingertip gripping force is 30N, with 30N at the thumb fingertip and 28N at the other fingertips. The overall load capacity is equivalent to 15KG.
Does the RH56E2 have tactile sensors?
The T1 and T2 versions do, with a tactile sensor accuracy of ≤5%FS. The other models are sold without tactile sensors, although all versions have built-in force sensors.
How is the hand controlled?
It is controlled through RS485, CAN or ModbusTCP. The operating voltage is 24V±10%.
How heavy is the hand?
It weighs 790g±10g with tactile sensors and 770g±10g without.
How fast and how precise is it?
The four fingers flex at more than 200°/s and the hand closes in 0.8S. Repeatability is ±0.20mm.
Is it available as a left and a right hand?
Yes. The versions are offered as left (L) and right (R) models, so a pair can be fitted to a two-armed robot.
Where can I buy the RH56E2 and what does it cost?
You can request a quotation on this page for the version you need. The cost is given in the quotation, together with delivery, customs and support arrangements.
Summary
The RH56E2 answers the old question of strength versus finesse with a single compact hand: 30N at the fingertip, a load capacity equivalent to 15KG, and force sensors that report how that strength is being used. The tactile versions add palm-wide touch data, while the lighter models keep things simple. With 6 degrees of freedom, 12 joints and three control interfaces, it fits research benches, humanoid platforms and demanding handling cells alike. When you are ready to choose a version, this page is the starting point.