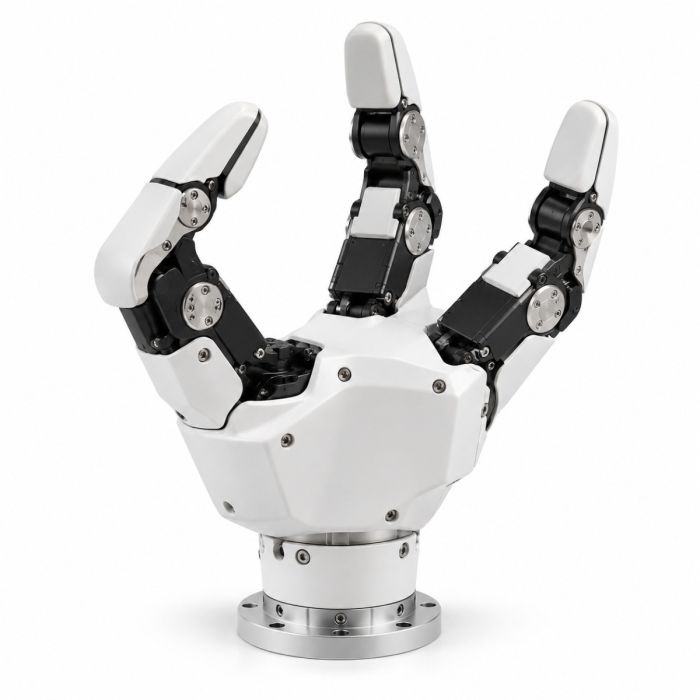
Elephant Robotics myGripper H100 Left Hand (4010700101)
In stock
- BRAND:
- ELEPHANT ROBOTICS
- MODEL:
- myGripper H100
- PART #:
- 4010700101
- ORIGIN:
- China
- Warranty:
- 12 MONTHS
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- Elephant Robotics Technology-4010700101
Elephant Robotics myGripper H100 Left Hand (4010700101)
Most grippers open and close; a hand has to decide how to hold. The Elephant Robotics myGripper H100 Left Hand (4010700101) sits between those two ideas: a compact three-finger unit whose fingers follow the human thumb, index finger and ring finger, built for laboratories and classrooms where the question is how an object is grasped, not only whether it is.
The myGripper H100 Left Hand is available through this page, by quotation.
Background
Elephant Robotics and the H100 line
Elephant Robotics develops compact robot arms and end-effectors for research, education and light-duty demonstration work. Its catalog is browsable under the Elephant brand page and the Cobots category. Within that range, the myGripper H100 is the company's three-finger dexterous robotic hand, developed for robotics research, education and related scenarios.
The H100 is sold in three versions: the Left Hand covered on this page, the myGripper H100 Right Hand, and the myGripper H100 Left + Right Hand combination. Choosing a version is mainly a matter of which side of your setup the hand will serve.
Servo-driven, software-friendly design
The hand is equipped with six high performance digital servo motors. They give you control of output torque, motion speed and absolute position, so a program can ask for a gentle hold or a firm one and can place each joint where it needs to be. The motors support current, position and speed control, which is the vocabulary researchers use when they want to study grasping rather than simply perform it.
On the software side, the hand is compatible with both ROS1 and ROS2, and it supports the RVIZ simulation environment, which lets users display the state of the robot arm and collect real-time data. A standardized robot driver library can be downloaded and installed through PyPI, so a first test does not have to begin with writing a driver from scratch.
Technical Specifications
| Specification | Value |
|---|---|
| Product type | Three-finger dexterous robotic hand |
| Payload | 500g |
| Self-weight | 780g |
| Stroke (diameter) | 0 – 130mm |
| Motion speed | 60 degrees per second per joint |
| Number of fingers | 3 (corresponding to the human thumb, index finger and ring finger) |
| Movable joints | 6 |
| Motor type | Servo motor supporting current, position and speed control |
| Lifespan | 1,000,000 cycles or more |
| Electrical interface | M8 Pin aviation connector |
| Power parameters | 24V, 2A |
| Communication interface | RS485 |
| Protocol type | MODBUS |
| Main control chip | ESP32 |
| Main control parameters | 240MHz dual-core, 600 DMIPS, 520KB SRAM, Wi-Fi, dual-mode Bluetooth |
| Software | ROS1 and ROS2, RVIZ simulation environment |
| Driver library | Standardized robot driver library, installable via PyPI |
Specifications as published by the manufacturer; confirmed against the datasheet at quotation.
The manufacturer has not published the dimensions, the IP rating, the gripping force, the operating temperature, the left-hand package weight or the operating voltage range; they are confirmed at quotation.
What makes a three-finger hand different from a two-jaw gripper?
A parallel two-jaw gripper has one motion: wider or narrower. That is perfectly good for boxes and bars, and it is easy to program. A three-finger hand with six movable joints offers more ways to approach an object, because each finger can be positioned on its own terms. The fingers correspond to the human thumb, index finger and ring finger, which is a useful reference when you are teaching students how people actually pick things up.
The H100 also gives you more to measure. Its servo motors support current, position and speed control, and the hand can control output torque, motion speed and absolute position. In a research setting, that means grasp experiments can be written as parameters and repeated, rather than tuned by feel.
The numbers describe a hand sized for light work. The stroke diameter runs from 0 to 130mm, the payload is 500g, and the hand weighs 780g itself. Each joint moves at 60 degrees per second. These figures suit demonstration, teaching and research-scale manipulation, not heavy handling.
How does the H100 connect and get controlled?
Electrically, the hand uses an M8 Pin aviation connector and is specified at 24V, 2A. Communication runs over RS485 using the MODBUS protocol, a combination that engineers in automation already know well and that most control stacks can speak.
Inside, the main control chip is an ESP32 with a 240MHz dual-core processor, 600 DMIPS, 520KB SRAM, Wi-Fi and dual-mode Bluetooth. For software, ROS1 and ROS2 are both supported, together with the RVIZ simulation environment, and the PyPI driver library gives Python users a short path from unboxing to a first movement. Because the lifespan is listed at 1,000,000 cycles or more, the hand can also be used for repeated trials without treating every session as wear on a scarce part.
Who is the myGripper H100 Left Hand for?
University and institute labs are the obvious audience: groups studying grasping, dexterous manipulation or human-robot interaction will value a hand that exposes torque, speed and position control and speaks ROS. Educators will find it a tangible teaching tool, since students can see how a thumb, index finger and ring finger work together and then reproduce the behavior in code.
Developers and integrators building demonstrations or prototypes also fit here, particularly those who already work with MODBUS over RS485. Hobbyist builders with a research mindset can use the same Python driver library.
If your project needs a hand on the right side of the setup, look at the myGripper H100 Right Hand. If you plan to work with two hands, the myGripper H100 Left + Right Hand version covers both in one order. This Left Hand version is the better choice when you need only the one side.
What is the myGripper H100 Left Hand used for?
- Grasping research: run repeatable experiments with controlled torque, speed and absolute position.
- Classroom teaching: show how a thumb, index finger and ring finger cooperate to hold an object.
- ROS development: build and test behaviors under ROS1 or ROS2, with RVIZ simulation to display state.
- Data collection: gather real-time data on the hand and arm state during manipulation trials.
- Python prototyping: install the standardized driver library from PyPI and script movements quickly.
- Demonstrations: show dexterous, hand-like movement at labs, exhibitions and training sessions.
Pricing and Availability
Pricing is provided by quotation. Send us your request, including how many hands you need and which version, and we will respond with a quotation. Delivery, customs and support are arranged with the quotation. The Elephant Robotics myGripper H100 Left Hand (4010700101) is available on this page.
Frequently Asked Questions
How many fingers and joints does the myGripper H100 Left Hand have?
It has three fingers, corresponding to the human thumb, index finger and ring finger. There are six movable joints, each driven by one of six digital servo motors.
What payload can it handle?
The payload is 500g, and the hand weighs 780g itself. The stroke diameter is 0 – 130mm.
How is the hand connected and powered?
It uses an M8 Pin aviation connector and is specified at 24V, 2A. Communication is over RS485 with the MODBUS protocol.
Does it work with ROS and Python?
Yes. It is compatible with ROS1 and ROS2 and supports the RVIZ simulation environment. A standardized robot driver library can be downloaded and installed through PyPI.
How long is the hand designed to last?
The lifespan is listed as 1,000,000 cycles or more.
What is the difference between the Left Hand, Right Hand and Left + Right Hand versions?
The Left Hand and Right Hand are single hands for their respective sides, while the Left + Right Hand version covers both. The specifications in this article are those published for the myGripper H100.
Where can I buy the myGripper H100 Left Hand and what does it cost?
You can request it through this page. The price is given by quotation, and delivery, customs and support are arranged with it.
Summary
A gripper closes on things; a hand can be taught how to hold them. The myGripper H100 Left Hand brings three fingers, six movable joints and servo control of torque, speed and position into a unit that speaks RS485, MODBUS, ROS1, ROS2 and Python. It suits labs, classrooms and prototype builders who want to study and demonstrate dexterous grasping with a 500g payload and a 0 – 130mm stroke. For a quotation on this version, this page is the starting point.