Elephant Robotics myGripper H100 Left + Right Hand (4010700098)
In stock
- BRAND:
- ELEPHANT ROBOTICS
- MODEL:
- myGripper H100
- PART #:
- 4010700098
- ORIGIN:
- China
- Warranty:
- 12 MONTHS
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- Elephant Robotics Technology-4010700098
Elephant Robotics myGripper H100 Left + Right Hand (4010700098)
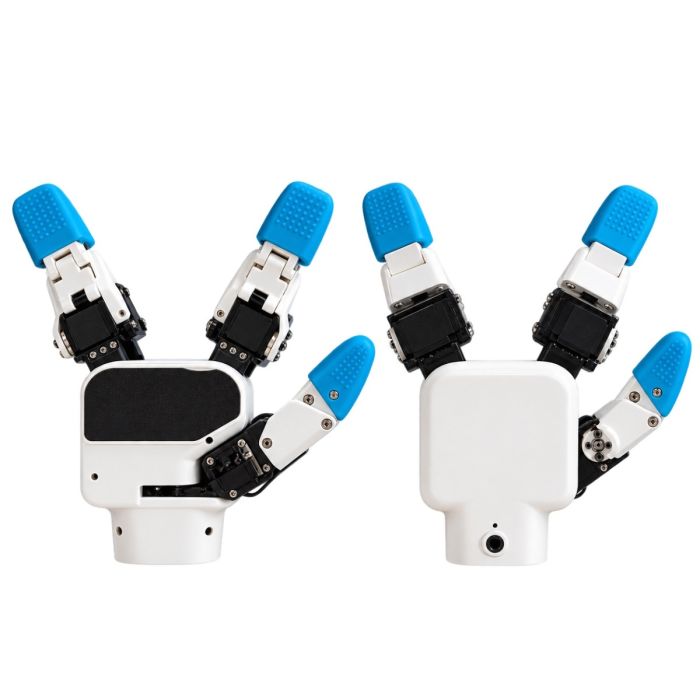
Most robot arms can move; far fewer can hold something the way a hand does. The Elephant Robotics myGripper H100 Left + Right Hand (4010700098) is built for that gap, giving a research bench or a classroom a pair of three-finger dexterous hands instead of a simple pinch gripper. With a left and a right hand together, bimanual experiments and mirrored demonstrations become practical.
The product is available through this page, by quotation.
Background
The company behind the hand
The myGripper H100 was developed by Shenzhen Elephant Robot Technology Co., Ltd., the company known as Elephant Robotics. Its catalog is built around compact collaborative arms and educational platforms, and the H100 follows the same thinking: a tool meant for people who learn, test and prototype with robots, not only for those who run them on a production line.
The hand was designed specifically for robotics research, education and related scenarios. That purpose explains many of its design choices, from the open communication standards to the driver library that installs from PyPI. It also explains its pairing with the maker's arm platforms: the myCobot Pro 630 and the Mercury series are the compatible models named for it. If you are still choosing an arm, the Elephant Robotics myCobot Pro 630 Robot Arm is one of the platforms listed, and more of the maker's range sits in the Cobots category.
Positioning and key technology
The H100 is a three-finger hand. The three fingers correspond to the human thumb, index finger and ring finger, and the hand has 6 movable joints. Six high performance digital servo motors drive them, and the control is not limited to open and close: output torque, motion speed and absolute position can all be controlled. The motor type is a servo motor that supports current, position and speed control.
Research use depends on data as much as on motion. The H100 supports high-frequency 100Hz communication, which allows real-time status monitoring during grasping operations and meets the data collection needs of research environments. A main control chip of type ESP32 handles the hand's onboard logic, and the communication runs over an RS485 interface with the MODBUS protocol, a combination that engineers in most labs already know well.
Technical Specifications
| Specification | Value |
|---|---|
| Product type | Three-finger dexterous robotic hand |
| Number of fingers | 3 fingers (corresponding to the human thumb, index finger and ring finger) |
| Movable joints | 6 |
| Servo motors | 6 high performance digital servo motors |
| Motor type | Servo motor supporting current, position and speed control |
| Payload | 500g |
| Self-weight | 780g |
| Stroke (diameter) | 0 – 130mm |
| Motion speed | 60 degrees per second per joint |
| Lifespan | 1,000,000 cycles or more |
| Power parameters | 24V, 2A |
| Communication interface | RS485 |
| Communication frequency | 100Hz |
| Protocol type | MODBUS |
| Electrical interface | M8 Pin aviation connector |
| Main control chip | ESP32 |
| Fixing method | Screw fixing |
| Software support | ROS1 and ROS2, with RVIZ simulation environment |
| Compatible models | myCobot Pro 630, Mercury series |
Specifications as published by the manufacturer; confirmed against the datasheet at quotation.
The manufacturer has not published the dimensions, the IP rating, the operating temperature range, the certifications, the fingertip force in newtons or any weight difference between the left and right hand; they are confirmed at quotation.
What makes the H100 different from a standard two-finger gripper?
A parallel gripper opens and closes along one axis. It is dependable, but it treats every object the same way. The H100 gives the controller three fingers and six joints to work with, so the shape of the grasp can change from one object to the next. For a student studying how a hand wraps around an object, or a researcher comparing grasp strategies, that range is the whole point.
The control model matters as well. Because torque, speed and absolute position are each controllable, a program can ask for a gentle closing or a firm one, a slow approach or a quick one. Add the 100Hz status stream and you can watch what the hand is doing while it does it, rather than reconstructing events afterward from a video.
The software side lowers the effort of getting started. The hand is compatible with both ROS1 and ROS2 and includes support for the RVIZ simulation environment, so users can display the robot arm's state and collect real-time data. A standardized robot driver library can be downloaded and installed via PyPI, which keeps setup within the tools a Python-based lab already uses.
Which version should you choose: Left, Right or Left + Right?
Three versions exist: Left Hand, Right Hand and Left+Right Hand. This page covers the pair. Choosing it makes sense when your work involves two arms, when you want mirrored hands for demonstrations, or when you would rather have both ready than reorder later. If your setup uses a single arm, a single hand is the leaner choice, and the individual versions are on their own pages: the myGripper H100 Left Hand and the myGripper H100 Right Hand.
Who is the myGripper H100 Left + Right Hand for?
University and institute labs are the clearest fit. A hand with an RS485 and MODBUS interface, ROS support and a driver library suits groups that collect grasp data and write their own control code. The 100Hz status monitoring speaks directly to that need.
Teachers and training centers form the second group. A three-finger hand with six joints is easy to explain, easy to show, and close enough to a human hand that students grasp the concepts quickly. Working in simulation first with RVIZ, then moving to hardware, is a sensible teaching sequence.
Developers of prototypes and demonstration rigs are the third group. If you need to show a manipulation concept to a client or a funding body, a pair of hands on a compatible arm makes a more convincing exhibit than a bare gripper. Buyers who already own a myCobot Pro 630 or a Mercury series arm will find the compatibility line reassuring.
Production lines needing a heavy-duty, certified, environmentally rated end effector should ask about those points before committing, since this page gives no figures for them.
What is the myGripper H100 used for?
- Grasp research: compare grasp strategies and record torque, speed and position data at 100Hz.
- Classroom teaching: show students how a three-finger hand with six joints picks up and holds objects.
- Bimanual experiments: use the left and right hands together on a two-arm setup.
- Simulation-to-hardware work: develop in RVIZ under ROS1 or ROS2, then move to the real hand.
- Python development: install the driver library from PyPI and script the hand over RS485 and MODBUS.
- Demonstrations: present dexterous manipulation to visitors, clients or reviewers on a compatible arm.
Pricing and Availability
We do not print prices on this page. Please request a quotation for the Elephant Robotics myGripper H100 Left + Right Hand (4010700098) and we will respond with the details for your order. Delivery, customs and support are arranged with the quotation, so you will see the whole picture before you decide. The myGripper H100 Left + Right Hand is available on this page.
Frequently Asked Questions
How many fingers and joints does the hand have?
It has 3 fingers, corresponding to the human thumb, index finger and ring finger, and 6 movable joints. Six high performance digital servo motors drive them.
What can it lift?
The payload is 500g, and the self-weight is 780g. The stroke (diameter) is 0 – 130mm.
How do I connect and power it?
The power parameters are 24V, 2A. Communication uses an RS485 interface with the MODBUS protocol, and the electrical interface is an M8 Pin aviation connector.
Which software does it work with?
It is compatible with both ROS1 and ROS2 and supports the RVIZ simulation environment. A standardized robot driver library can be downloaded and installed via PyPI.
Which robot arms is it compatible with?
The compatible models listed are the myCobot Pro 630 and the Mercury series. Tell us which arm you use when you request a quotation.
How long is the hand designed to last?
The lifespan is 1,000,000 cycles or more. The hand moves at 60 degrees per second per joint.
Where can I buy the myGripper H100 Left + Right Hand and what does it cost?
You can buy it through this page by requesting a quotation. We do not list a price here; the quotation sets out the cost together with delivery, customs and support.
Summary
Where a simple gripper can only pinch, the myGripper H100 offers three fingers, six joints and controllable torque, speed and position, with 100Hz feedback to show what the hand is doing. As a left and right pair it gives labs, classrooms and demonstration teams the means to work with both hands. If that fits your project, this page is the starting point.