
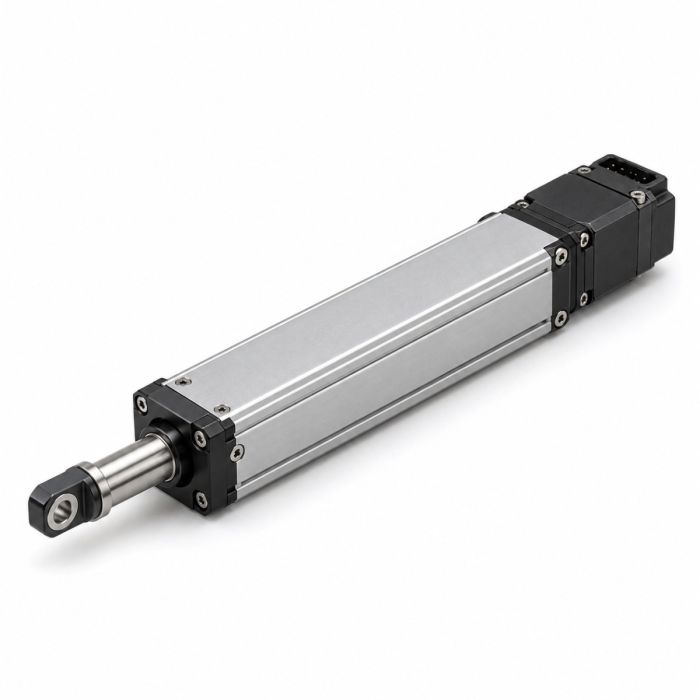
Xynova PRM10-25-47-100-F Linear Actuator
In stock
- BRAND:
- XYNOVA
- MODEL:
- PRM10-25-47-100-F
- ORIGIN:
- China
- Warranty:
- 12 MONTHS
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- Xynova-PRM10-25-47-100-F
Xynova PRM10-25-47-100-F Linear Actuator
A humanoid hand has to pack muscle into the space of a finger, and most actuators were never drawn at that scale. The Xynova PRM10-25-47-100-F Linear Actuator was. It is a micro electric cylinder that measures 10*13.5*86mm and weighs ≤38g, yet it is rated for ≥100N of max thrust. For a builder who has run out of room in a forearm, a wrist or a finger, that mix of size and force is the point of the part.
The product is available through this page, by quotation.
Background
Xynova and its place in humanoid robotics
Xynova Technology Co., Ltd. is a core component supplier in the field of humanoid robots. Its range covers dexterous hands, integrated joint modules and micro electric cylinders. That mix is telling. A company that builds complete hands and joints also knows what the parts inside them must do: move precisely, fit into tight housings, and stay light enough that the limb does not tire the rest of the machine.
The PRM10 micro cylinders come out of that background. They were designed for humanoid robots, not adapted from industrial automation parts. The motor, the screw and the upper-level software are all developed in-house, so one manufacturer is responsible for how the pieces work together. For an integrator, that means fewer unknowns at the boundary between the actuator and its controlling software.
How the PRM10-25-47-100-F is built
Two pieces of technology set this actuator apart. The first is an in-house developed 7mm micro planetary roller screw. It greatly improves transmission efficiency and suits both industrial and everyday applications. The second is an in-house developed frameless torque motor, a brushless hollow cup motor. It provides higher torque, longer lifespan and quieter operation.
Safety is also part of the design. The actuator offers easy joint self-locking, so there is no risk from a power failure, and the joint is safer during operation. On the control side, Xynova supplies in-house developed upper-level software with a rich set of API interfaces, which makes it easier to coordinate and control several modules together. That matters in a humanoid, where dozens of actuators must work as one system.
Technical Specifications
| Specification | Value |
|---|---|
| Effective stroke | 24+1%mm |
| Size (L×W×H) | 10*13.5*86mm |
| Weight | ≤38g |
| No-load max speed | ≥47mm/s |
| Full-load speed | ≥20mm/s |
| Max thrust | ≥100N |
| Operating voltage | DC12±10%V |
| Repeatability | ±0.05mm |
| Operating temperature | -15~60℃ |
| Static current | 0.05A |
| No-load current | 0.4A |
| Screw type | In-house developed 7mm micro planetary roller screw |
| Motor | In-house developed frameless torque motor / brushless hollow cup motor |
Specifications as published by the manufacturer; confirmed against the datasheet at quotation.
The manufacturer has not published the weight of the cable and connector, the communication interface, the IP rating, the package contents, the encoder type, the service life, the rated power or the mounting method; they are confirmed at quotation.
What makes the PRM10-25-47-100-F different from a conventional linear actuator?
The first difference is scale. A conventional electric cylinder is sized for a machine frame or a workbench. This one measures 10*13.5*86mm and weighs ≤38g, which makes it a candidate for places where a standard actuator would never fit, such as the inside of a hand or a forearm. Every gram placed at the end of a limb costs the robot energy and control effort, so a light actuator pays back across the whole machine.
The second difference is how the force is produced. The planetary roller screw spreads load across several rolling contacts, which greatly improves transmission efficiency. Paired with a frameless torque motor of the hollow cup type, the result is higher torque, longer lifespan and quieter operation. At ≥100N of max thrust and ≥20mm/s at full load, the actuator delivers meaningful force at a useful pace, and it reaches ≥47mm/s with no load.
The third difference is precision and control. Repeatability of ±0.05mm is the kind of figure a designer needs when a finger must return to the same position again and again. The in-house software and its API interfaces then let a team coordinate several modules without building a control layer from nothing. Add easy joint self-locking, and the joint holds safely even when power is lost.
How does it compare with the other PRM10 versions?
The PRM10 family is offered in several versions, and each version carries its own figures. Every number on this page belongs to the PRM10-25-47-100-F alone; none of it should be carried over to another version. If your design calls for a different stroke, speed or thrust balance, the sibling Xynova PRM10-20-18-200-F Linear Actuator is the version to look at, and we can set the two side by side for you. Other PRM10 versions can be requested through the same route.
Tell us the stroke you need, the load the joint must carry and the speed you expect. We will then suggest the version that fits, rather than leaving you to guess from a model code. The wider Robot Actuators category also shows the rotary options that sit alongside these linear parts.
Who is the Xynova PRM10-25-47-100-F for?
The first group is humanoid robot developers. The actuator was designed for humanoid robots, so it is the natural choice for teams building hands, wrists, forearms and other compact joints where space and weight are limited.
The second group is research laboratories and universities. A team working on dexterous manipulation or biomimetic limbs needs small actuators with repeatable motion and a software interface it can script. The API interfaces and the ±0.05mm repeatability serve that need directly.
The third group is integrators and prototype builders working in industrial automation or advanced mechatronics. Where a mechanism must be compact and quiet, a micro cylinder of this size opens options that a bulky cylinder cannot. Buyers who need a longer or shorter stroke, or a different speed and thrust balance, should ask about the PRM10-20-18-200-F as a comparison. Buyers who need rotary motion rather than linear should browse the rotary actuators in the Robot Actuators category.
What is the Xynova PRM10-25-47-100-F used for?
- Finger and hand actuation. Its small body can drive the linear motion of a dexterous hand digit.
- Wrist and forearm joints. The light weight keeps the mass at the end of the limb low.
- Research on manipulation. Repeatable motion and an open API suit repeated experiments.
- Multi-module coordination. The upper-level software lets several actuators work together in one system.
- Compact automation prototypes. A quiet micro cylinder fits mechanisms where a standard cylinder is too large.
- Education and demonstration platforms. Students can work with a real humanoid-grade actuator in a safe, low-voltage DC12±10%V system.
Pricing and Availability
This actuator is sold by quotation only. Send us your quantity, your application and the version you need, and we will prepare an offer for the Xynova PRM10-25-47-100-F Linear Actuator. Delivery, customs and support are arranged with the quotation. The Xynova PRM10-25-47-100-F Linear Actuator is available on this page.
Frequently Asked Questions
What stroke does the actuator offer?
The effective stroke is 24+1%mm. This figure belongs to the PRM10-25-47-100-F version.
How fast and how strong is it?
No-load max speed is ≥47mm/s and full-load speed is ≥20mm/s. Max thrust is ≥100N.
What supply voltage does it need?
The operating voltage is DC12±10%V. Static current is 0.05A and no-load current is 0.4A.
What temperature range can it work in?
The operating temperature is -15~60℃.
Can the joint hold its position when power is lost?
Yes. The actuator offers easy joint self-locking, so there is no risk from a power failure, and the joint is safer during operation.
How is the actuator controlled?
Xynova supplies in-house developed upper-level software with a rich set of API interfaces, which makes it easy to coordinate and control multiple modules. Ask us about the communication interface when you request your quotation.
Where can I buy the Xynova PRM10-25-47-100-F and what does it cost?
You can request it through this page. The cost is given in a quotation prepared for your quantity and project, and no price is listed here.
Summary
Strength in a small space is a hard thing to engineer, and the Xynova PRM10-25-47-100-F Linear Actuator addresses it directly. A body of 10*13.5*86mm and ≤38g carries ≥100N of max thrust, driven by a 7mm micro planetary roller screw and a frameless torque motor. Repeatability of ±0.05mm, easy joint self-locking and a software package with open API interfaces complete a part built for humanoid robots. For teams that need that kind of actuator, this page is the starting point.


