Xynova Flex 2 Dexterous Robot Hand
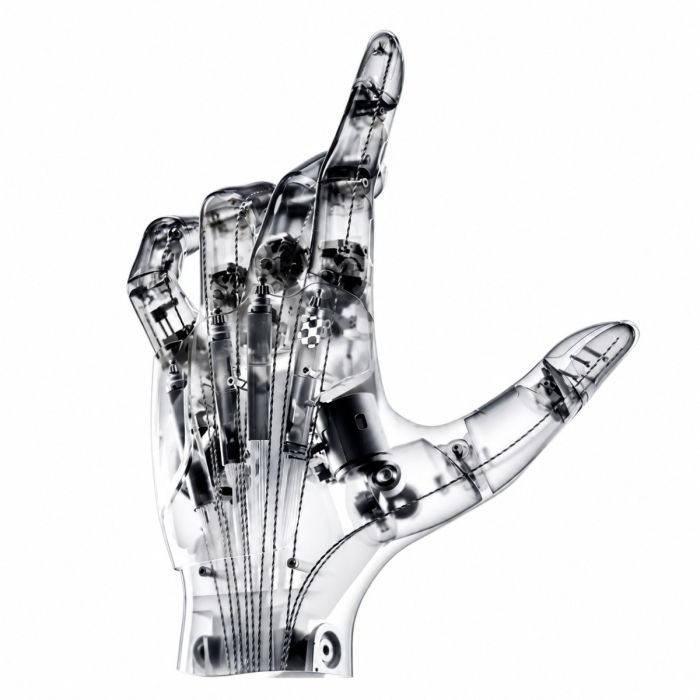
The Xynova Flex 2 is a 23 degree of freedom bionic robot hand that combines tendon and direct drive actuation in a package of about 400 g. Micro linear actuators provide a 12 kg single hand grasp load, while back drivable joints, slip detection and a replaceable soft skin support durable, compliant manipulation in factories, service robots and humanoid platforms.
In stock
- BRAND:
- XYNOVA
- MODEL:
- FLEX 2
- ORIGIN:
- China
- Warranty:
- 12 MONTHS
- AVAILABILITY:
- ALLOW 6-8 WEEKS FOR DELIVERY
- SKU:
- Xynova-Flex-2
Xynova Flex 2 Dexterous Robot Hand
Most robot hands can close around an object; far fewer can feel it begin to slip and adjust before it falls. The Xynova Flex 2 Dexterous Robot Hand is built around that second skill, pairing a human-scale bionic structure with sensing and a reflex layer that reacts while the hand is still holding on.
The product is available through this page, by quotation.
Background
Xynova and its place in humanoid robotics
Xynova Technology Co., Ltd. is a core component supplier in the field of humanoid robots. That detail matters for how the Flex 2 should be read. It is not a finished robot and not a general-purpose gripper, but a component meant to be fitted to a larger machine, whether that is a humanoid platform, a research arm or a custom manipulation cell.
Suppliers of this kind work close to the joints, the drives and the tendons, which is where the hardest problems of hand design sit. Xynova also lists rotary actuators such as the Xynova PR20-102-130-HS Rotary Actuator, so teams that already work with the brand can look at the hand and the joint hardware side by side.
What defines the Flex 2
The Flex 2 follows a bionic brief: full dimensional bionics in size, joints and kinematic structure. It has 23 degrees of freedom, of which 19 are active and 4 are passive. Its hybrid drive combines tendon rope with direct motor drive, and power comes from micro linear actuators.
The hand scored perfectly in the Kapandji Thumb Opposition Test, a clinical measure of how well the thumb reaches the other fingers. For a robot hand this means the thumb can work against each finger, which is the basis of pinching, holding and shaping a grip around different objects.
Above the mechanics sits the intelligence layer: multi-modal perception fusion and a human-like "cerebellum" that support adaptive grasping, slip detection and compliant reflexes. The hand is also back-drivable under load, which allows hybrid force and position control. You can browse related hardware in the Robot Hands category.
Technical Specifications
| Specification | Value |
|---|---|
| Model | Flex 2 |
| Degrees of freedom | 23 (19 active, 4 passive) |
| Weight | 400g |
| Fist extension speed | 2 fist extensions per second |
| Repeatability | ±0.1mm |
| Force control accuracy | Down to 0.05N |
| Single-hand grasp load | 12kg |
| Rated continuous operation load | 4kg |
| Drive | Hybrid of tendon rope and direct motor drive |
| Actuators | Micro linear actuators |
| Kapandji Thumb Opposition Test | Perfect score |
| Skin | Soft, replaceable, with anti-pinch seams |
| Palm surface | Wear- and puncture-resistant |
| Durability | Dustproof, dropproof, impact-resistant; millions of open/close cycles |
Specifications as published by the manufacturer; confirmed against the datasheet at quotation.
The manufacturer has not published the dimensions, the power supply voltage, the communication protocol, the fingertip force per finger, the operating temperature range, the IP rating, the contents of the box, or the sensor count and sampling rate; they are confirmed at quotation.
What makes the Flex 2 different from a simple gripper?
A gripper is usually judged by how hard it holds. The Flex 2 is better judged by how well it adapts. With 23 degrees of freedom and a thumb that opposes the fingers fully, it can wrap around an irregular object instead of clamping it between two flat surfaces. The soft replaceable skin adds to that shape adaptation and protects the mechanism beneath.
The numbers show a hand that is both gentle and strong. Force control accuracy reaches down to 0.05N, so a delicate object can be held without being crushed. The single-hand grasp load is 12kg, while the rated continuous operation load is 4kg. Those two figures answer different questions: the first describes what the hand can grasp, the second what it is rated to carry in sustained operation. Planning around the continuous figure is the sensible approach for long runs.
Repeatability of ±0.1mm matters when the same motion has to be performed over and over, as in a test fixture or a data-collection session. At 400g the palm is light enough that a humanoid arm or a research manipulator does not have to carry a heavy end effector, and it can still perform 2 fist extensions per second.
How does the hand stay reliable in daily use?
Dexterous hands often fail at the edges: a stretched tendon, a worn palm, a pinched finger. Xynova addresses these points directly. Anti-creep tendon ropes and full-range temperature control support stable operation, the palm surface resists wear and punctures, and the seams are designed to prevent pinching. The hand is dustproof, dropproof and impact-resistant, and it endures millions of open/close cycles.
Because the skin is replaceable, a worn outer surface does not mean replacing the whole hand. The open development ecosystem supports customization, expansion and integration, so engineering teams can adapt the hand to their own control software and test setups rather than working around a closed design.
Who is the Xynova Flex 2 for?
The Flex 2 suits humanoid robot developers who need a hand with human-like proportions and a thumb that can truly oppose. It also suits university and corporate research groups working on grasping, in-hand manipulation and tactile reflexes, where the open development ecosystem and force control down to 0.05N are valuable.
System integrators building custom manipulation cells can use it where objects vary in shape and a fixed gripper would need constant tooling changes. Training and education labs may also find it useful as a teaching platform for advanced mechatronics, provided the budget and the integration effort fit the program. Teams that are still comparing designs can look through the Robot Hands category, and those that need supporting parts can check Accessories.
What is the Xynova Flex 2 used for?
- Humanoid robot development. Gives a humanoid platform a hand with human-like size, joints and kinematic structure.
- Manipulation research. Supports studies of adaptive grasping, slip detection and compliant reflexes.
- Precision handling. Repeatability of ±0.1mm and force control down to 0.05N suit consistent, careful handling.
- Carrying and lifting tasks. A single-hand grasp load of 12kg and a rated continuous operation load of 4kg cover objects of varied weight.
- Custom integration projects. The open development ecosystem allows customization, expansion and integration with existing systems.
- Education and demonstration. A bionic hand with a perfect Kapandji thumb score shows clearly how human grasping can be reproduced in a machine.
Pricing and Availability
The Flex 2 is supplied by quotation only, so a request lets us match the offer to your project. Delivery, customs and support are arranged with the quotation. Tell us the platform you are building and how many hands you need, and we will respond with the details. The Xynova Flex 2 Dexterous Robot Hand is available on this page.
Frequently Asked Questions
How many degrees of freedom does the Flex 2 have?
It has 23 degrees of freedom, made up of 19 active and 4 passive. The hand follows a bionic configuration.
How much does the hand weigh?
The palm weighs 400g. It can perform 2 fist extensions per second.
What load can it carry?
The single-hand grasp load is 12kg, and the rated continuous operation load is 4kg. Use the rated figure when planning sustained work.
How precise is it?
Repeatability is ±0.1mm, and force control accuracy goes down to 0.05N. The hand is back-drivable under load for hybrid force and position control.
Is the hand protected against dust and impact?
Yes, it is dustproof, dropproof and impact-resistant, with a wear- and puncture-resistant palm surface.
Can it be integrated with our own systems?
Yes, the open development ecosystem supports customization, expansion and integration with your own platforms.
Where can I buy the Xynova Flex 2 and what does it cost?
The hand is available through this page, by quotation. Send us your request and we will reply with a quotation tailored to your project.
Summary
The Xynova Flex 2 answers the question of what happens after the grasp: it senses slip, adapts to the shape of the object and reacts with compliant reflexes. Its 23 degrees of freedom, hybrid tendon and direct-drive mechanism, ±0.1mm repeatability and 12kg grasp load make it a serious option for humanoid and manipulation work. For a quotation on the Xynova Flex 2 Dexterous Robot Hand, this page is the starting point.