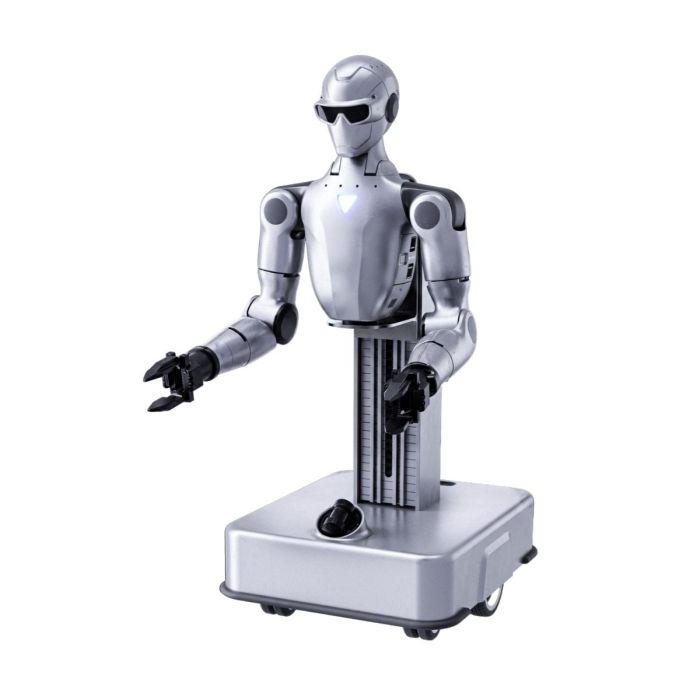
Unitree R1-A7-D Smart H Humanoid Robot
In stock
- BRAND:
- UNITREE ROBOTICS
- MODEL:
- R1-A7-D-Smart-H
- PART #:
- R1-A7-D-Smart-H
- ORIGIN:
- China
- Warranty:
- 12 MONTHS
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- Unitree-R1-A7-D-Smart-H
Unitree R1-A7-D Smart H Humanoid Robot
A humanoid robot is only as useful as the freedom you have to change it. The Unitree R1-A7-D Smart H Humanoid Robot is built around that idea: a platform with a choice of hands, a choice of compute module and open interfaces, so a team can shape it to the task instead of shaping the task to the robot.
This product is available through this page, by quotation.
Background
Unitree Robotics and the R1 lineage
UNITREE ROBOTICS is a robotics manufacturer best known for legged machines, and its humanoid work has made it a regular name in university laboratories and integration workshops. The R1 family is organized in versions: R1-A5, R1-A7, R1-A5-D and R1-A7-D. The product line is summed up as "Ultra-fast deployment, multi-scenario application".
The R1-A7-D version sits inside the Unitree R1-A7-D range, and the Smart configurations are grouped in the R1-A7-D Smart category. Smart H is one lettered configuration in that group. Every figure in this article belongs to the R1-A7-D version, and none is borrowed from R1-A5, R1-A7 or R1-A5-D.
Positioning and key technology
The R1-A7-D is positioned as a platform for development rather than a closed appliance. Its joints are driven by a low-inertia, high-speed inner rotor PMSM, a permanent magnet synchronous motor with superior responsiveness and heat dissipation. Cooling is handled by a local air cooling system.
On the perception side, the robot combines a chassis LiDAR with a binocular camera, and a wrist camera can be added as an option. Wireless connectivity covers WiFi 6 and Bluetooth 5.2. Above all, the platform offers open interfaces for the underlying system, the robotic arm, audio, lighting and visual control, which is what lets a laboratory or integrator build its own software on top.
Technical Specifications
| Specification | Value (R1-A7-D) |
|---|---|
| Shrunk size | 683x520x440mm |
| Raised size | 1600x520x440mm |
| Weight | Approx. 32kg |
| Waist joint motion range | Yaw±35° |
| Head joint motion range | Yaw±115°, Pitch±36° |
| Joint motor | Low-Inertia High-Speed Inner Rotor PMSM |
| Cooling system | Local Air Cooling |
| Sensing | Chassis LiDAR + Binocular Camera + Optional Wrist Camera |
| Connectivity | WiFi 6 and Bluetooth 5.2 |
| End effector options | Two-finger gripper, three-finger dexterous hand or five-finger dexterous hand (optional) |
| High-computing module options | Multiple brands and models, such as Orin (40-100TOPS) |
| Open interfaces | Underlying system, robotic arm, audio, lighting, visual control and more |
Specifications as published by the manufacturer; confirmed against the datasheet at quotation.
The manufacturer has not published the maximum travel speed, the charging time, the IP rating, the battery capacity, the chassis LiDAR model or the tendon-driven hand specifications for Smart H; they are confirmed at quotation.
What makes the R1-A7-D Smart H different from a fixed-configuration humanoid?
The difference is choice. A fixed-configuration robot arrives with one hand, one computer and one set of software limits. The R1-A7-D lists three end effector options, from a two-finger gripper to a five-finger dexterous hand, and a high-computing module that can come from several brands and models, with Orin options in the 40-100TOPS range given as an example. A team doing simple pick-and-place work and a team studying fine manipulation can start from the same body and arrive at different machines.
The second difference is access. Open interfaces for the underlying system, the arm, audio, lighting and visual control mean that developers are not limited to the behaviors a vendor decided to expose. That matters for research groups that need to test their own controllers, and for integrators who must connect a robot to existing equipment.
Finally, the body itself is practical. The shrunk size of 683x520x440mm and the raised size of 1600x520x440mm describe a robot that changes posture between transport and work, and the approximate weight of 32kg keeps it within what a small team can handle.
How do the head and waist movements help in practice?
A robot that looks at a task needs to turn toward it. The head joint offers Yaw±115° and Pitch±36°, which gives a wide sweep from side to side and a moderate tilt up and down. The waist adds Yaw±35°, so the upper body can rotate toward a work surface without the whole platform repositioning. Together with the binocular camera and the optional wrist camera, this gives a developer several viewpoints to work with when training vision-guided behaviors.
Who is the R1-A7-D Smart H for?
University laboratories and teaching departments are the clearest fit. They need a humanoid that students can program, with open interfaces and a choice of compute, and they often need the hands to match the course, from a simple gripper for introductory work to a dexterous hand for advanced manipulation studies.
System integrators and corporate research teams form the second group. They evaluate whether a humanoid can serve a reception, demonstration or light handling scenario, and they value the ability to attach their own software through the open interfaces. Operators preparing a pilot can use the platform to test sensing and interaction before committing to a larger program.
Buyers who want a different lettered configuration of the same version can compare Unitree R1-A7-D Smart A Humanoid Robot or Unitree R1-A7-D Smart B Humanoid Robot. We can explain with the quotation how each configuration differs from Smart H.
What is the R1-A7-D Smart H used for?
- Robotics research. Open interfaces and a selectable compute module let teams test their own control and perception software.
- Teaching and training. Students work with a real humanoid body, head and waist motion and a camera set instead of a simulation alone.
- Manipulation studies. The optional two-finger, three-finger and five-finger end effectors cover tasks from simple grasping to dexterous handling.
- Vision and navigation development. The chassis LiDAR, binocular camera and optional wrist camera supply data for mapping and visual control work.
- Integration pilots. Integrators connect the robot to audio, lighting and other systems through its open interfaces.
- Demonstration and interaction. The raised posture, head movement and wireless connectivity suit showcases and guided interaction experiments.
Pricing and Availability
We do not print prices on this page. A quotation is the way to buy: tell us the hand, the compute module and the wrist camera you need, and we will prepare it for the Smart H configuration. Delivery, customs and support are arranged together with the quotation. The Unitree R1-A7-D Smart H Humanoid Robot is available on this page.
Frequently Asked Questions
What are the dimensions of the R1-A7-D?
The shrunk size is 683x520x440mm and the raised size is 1600x520x440mm. The approximate weight is 32kg.
Which hands can be fitted?
The options are a two-finger gripper, a three-finger dexterous hand and a five-finger dexterous hand.
What sensors does it carry?
It carries a chassis LiDAR and a binocular camera, with a wrist camera as an option.
Can I choose the computing module?
Yes. Several brands and models are available, for example Orin in the 40-100TOPS range.
Does it connect wirelessly?
Yes, it supports WiFi 6 and Bluetooth 5.2.
How far can the head and waist turn?
The head turns Yaw±115° and tilts Pitch±36°, and the waist turns Yaw±35°.
Where can I buy the Unitree R1-A7-D Smart H Humanoid Robot and what does it cost?
You can buy it through this page by requesting a quotation. The cost depends on the configuration you choose, and it is given in the quotation rather than printed here.
Summary
The strength of the Unitree R1-A7-D Smart H Humanoid Robot is how much of it you can change: the hand, the compute module, the wrist camera and the software that runs through its open interfaces. A body that folds to 683x520x440mm and rises to 1600x520x440mm, with a head and waist that turn toward the work, gives that flexibility a practical frame. For a quotation tailored to your project, this page is the starting point.